


EYOU PHU20H-90-F Harmonic Robot Actuator, 80/100/120 Ratios for Robotics
EYOU PHU20H-90-F Harmonic Robot Actuator, 80/100/120 Ratios for Robotics
EYOU
Regular price
$863.00 USD
Regular price
Sale price
$863.00 USD
Unit price
per
Taxes included.
Shipping calculated at checkout.
Couldn't load pickup availability


Overview
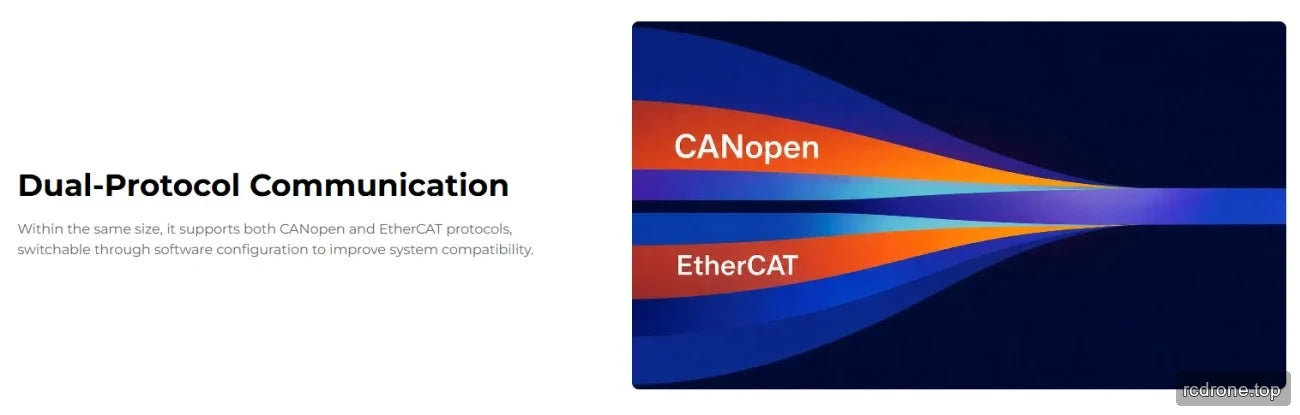
The EYOU PHU20H-90-F is a harmonic-reducer robot actuator module with selectable 80, 100, or 120 reduction ratios and with-brake or without-brake options. Its built-in driver supports EtherCAT and CANopen communication, while a 48 VDC rated supply and dual 19-bit absolute encoders support integration into robotic joint systems. Supported application scenarios include humanoid robots, robotic arms, exoskeletons, quadruped robots, AGV vehicles, and ARU robots.
Features
- Harmonic reducer with a split-body arrangement separating the motor and reducer.
- Selectable reduction ratios of 80, 100, and 120; the selected ratio changes the listed output torque, speed, and equivalent output inertia values.
- Available with brake or without brake.
- Built-in driver with dual absolute encoders: motor side 19-bit and reducer side 19-bit.
- Communication protocols: EtherCAT and CANopen.
- Driver interfaces: power (DC in/DC out), CAN FD (In/Out), EtherCAT (In/Out), and STO (1, 2).
- Control modes: Profile Position (PP), Profile Velocity (PV), Profile Torque (PT), Cyclic Synchronous Position (CSP), Force Control (CSF), etc.
Specifications
Shared Specifications
| Parameter | Value |
|---|---|
| Module Model | PHU-20H-90-F |
| Reducer Type | Harmonic |
| Motor Rated Power | 267 W |
| Motor Rated Torque | 0.85 N·m |
| Motor Peak Torque | 2.55 N·m |
| Brake (B/N) | B/N |
| Dimensions (Outer Diameter × Axial) | Φ90 × 94 mm |
| Weight (B/N) | 1.9 / 1.74 kg |
| Hollow Diameter | 13 mm |
| Housing Appearance (Process Color) | Black anodized (non-sandblasted) |
| Reducer Appearance (Process Color) | Outer ring blackened |
| Radial (dynamic/static) Allowable Load at Output | 650 N |
| Axial (dynamic/static) Allowable Load at Output | 650 N |
| Output Bending Moment | 140 N·m |
| Torque Sensor Range | 110 N·m |
| Torque Sensor Accuracy | ≤±0.5 %F.S |
| Torque Sensor Resolution | 0.1 %F.S |
| Torque Sensor Overload Limit | 300 %F.S |
| Torque Sensor Sampling Frequency (Digital) | 8 kHz |
| Torque Closed-loop Bandwidth | 30 Hz |
| Impedance Control Frequency | 1 kHz |
| Rated Operating Voltage | 48 VDC |
| Operating Voltage Range | 24–48 VDC |
| Driver | Built-in |
| Encoder/Bit | Dual absolute / motor side 19-bit & reducer side 19-bit |
| Driver Interface (see terminal model description) | Power (DC in/DC out), CAN FD (In/Out), EtherCAT (In/Out), STO (1, 2) |
| Communication Protocol (see communication description) | EtherCAT / CANopen |
| Control Modes | Profile Position (PP), Profile Velocity (PV), Profile Torque (PT), Cyclic Synchronous Position (CSP), Force Control (CSF), etc. |
| Operating Ambient Temperature | -10–60 °C |
| Housing Operating Temperature | ≤60 °C |
| Noise | ≤60 dB |
| Life | >10,000 h |
Ratio-Specific Specifications
| Parameter | Ratio 80 | Ratio 100 | Ratio 120 |
|---|---|---|---|
| Reduction Ratio | 80 | 100 | 120 |
| Joint Rated Power — Life Constraint | 110 W | 105 W | 87 W |
| Rated Torque at 2000 rpm Input | 42 N·m | 50 N·m | 50 N·m |
| Average Load Torque at Output | 58 N·m | 61 N·m | 61 N·m |
| Peak Torque at Output | 91 N·m | 102 N·m | 108 N·m |
| Max Allowable External Torque at Output (Instantaneous) | 158 N·m | 182 N·m | 182 N·m |
| Backlash | ≤20 arcsec | ≤20 arcsec | ≤20 arcsec |
| Rated Speed at Output — Life Constraint | 25 rpm | 20 rpm | 17 rpm |
| Peak Speed at Output | 38 rpm | 31 rpm | 25 rpm |
| Reducer Torsional Stiffness | 23,000 N·m/rad | 23,000 N·m/rad | 23,000 N·m/rad |
| Reducer Input Inertia (B) | 137.378 kg·mm² | 137.378 kg·mm² | 137.378 kg·mm² |
| Equivalent Joint Output Inertia (B) | 879,219 kg·mm² | 1,373,780 kg·mm² | 1,978,243 kg·mm² |
Applications
- Humanoid robots
- Robotic arms
- Exoskeletons
- Quadruped robots
- AGV vehicles
- ARU robots
Documentation
- EYOU CANable — User Manual (PDF)
- PHU20 EYOU — 3D Model (STP)
- EYOU PHU20H 90 F Drawing — Drawing (PDF)
- EYOU PHU RHU Series Joint CANopen EtherCAT Communication — Manual (PDF)
- EYOU Robot Joint Catalog — Robot Joint Product Catalog (PDF)
- EYOU RP Series EN V1.0 20260608 — User Manual (PDF)
- EYOU UART Debug Module — User Manual (PDF)
Visual Details
Product Views

Features and Design


Application Examples


Options and Model Comparison

Interfaces and Connections
Additional Product Details



