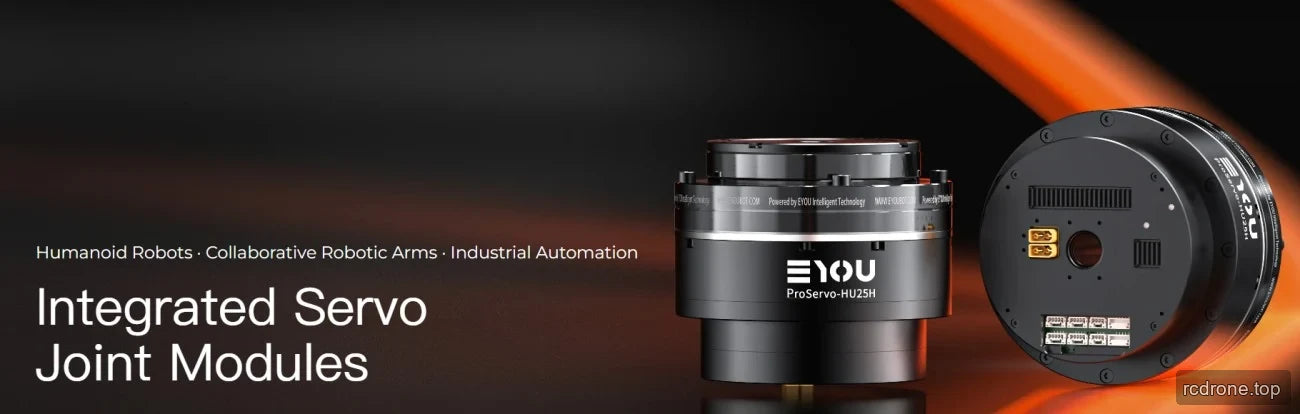
EYOU PHU32H-142 Harmonic Robot Joint Actuator, 81/101/121/161 Ratios, Brake Options for Robotics
EYOU PHU32H-142 Harmonic Robot Joint Actuator, 81/101/121/161 Ratios, Brake Options for Robotics
EYOU
Regular price
$1,165.00 USD
Regular price
Sale price
$1,165.00 USD
Unit price
per
Taxes included.
Shipping calculated at checkout.
Couldn't load pickup availability


Overview
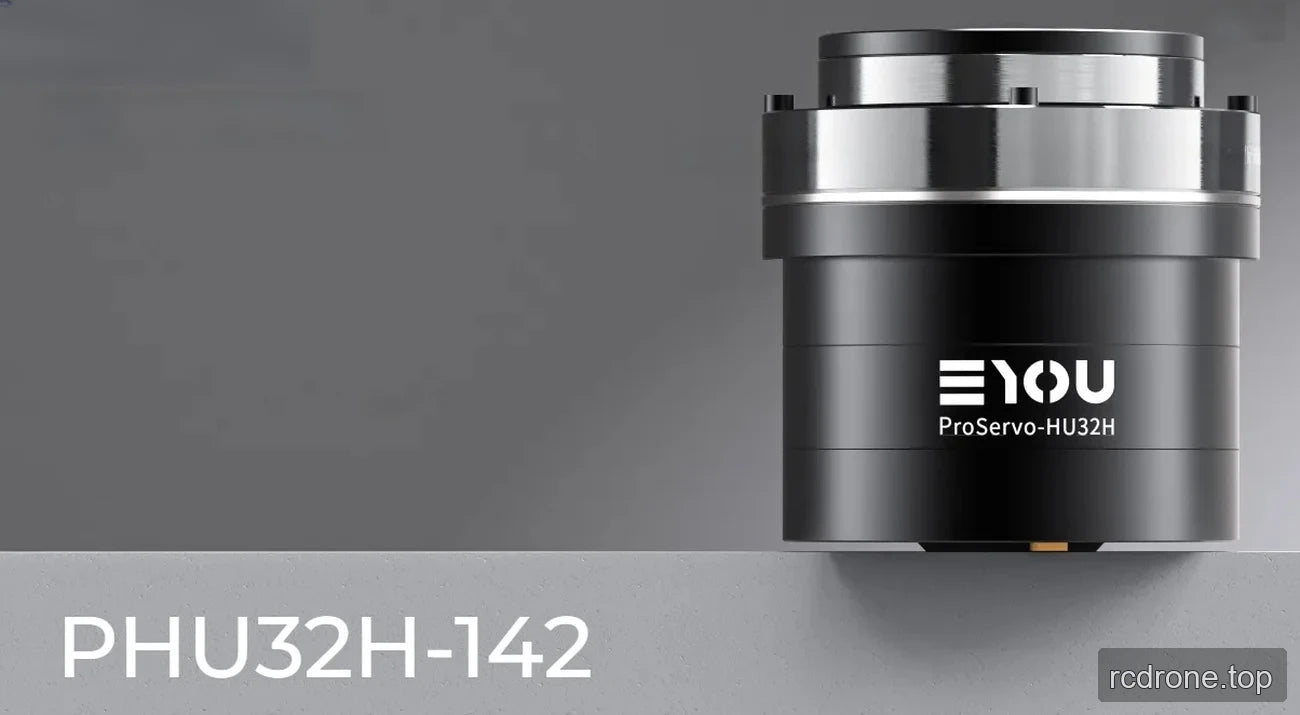
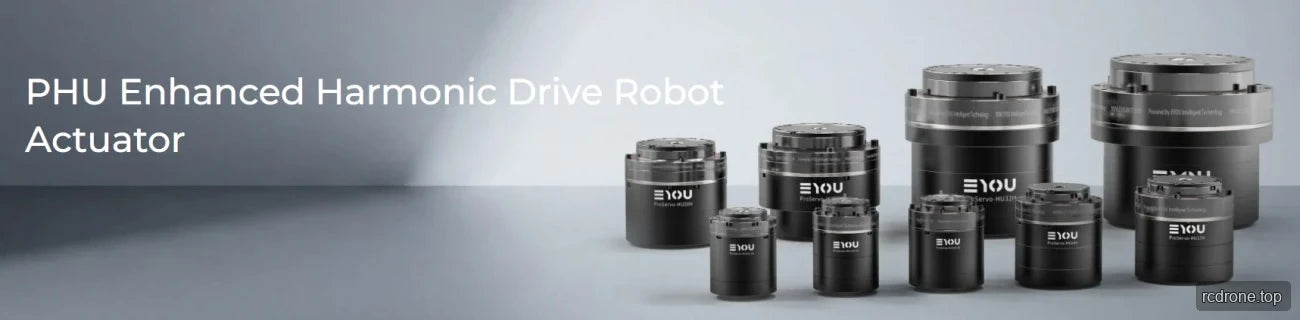
The EYOU PHU32H-142 is a harmonic robot joint actuator with a built-in driver, 48 VDC rated operating voltage, and EtherCAT or CANopen communication. Select reduction ratios of 81, 101, 121, or 161 to match the required output speed and torque profile, and choose with-brake or without-brake configurations. It is specified for robotics and industrial automation applications including humanoid robots, robotic arms, exoskeletons, quadruped robots, AGV vehicles, and ARU robots.
Features
- Harmonic reducer with a built-in driver.
- Selectable reduction ratios: 81, 101, 121, or 161.
- Brake selections: With Brake or Without Brake.
- Dual absolute encoder: motor side 17 bit and reducer side 19 bit.
- Communication protocols: EtherCAT and CANopen.
- Driver interfaces: power (DC in/DC out), CAN FD (In, Out), EtherCAT (In, Out), and STO (1, 2).
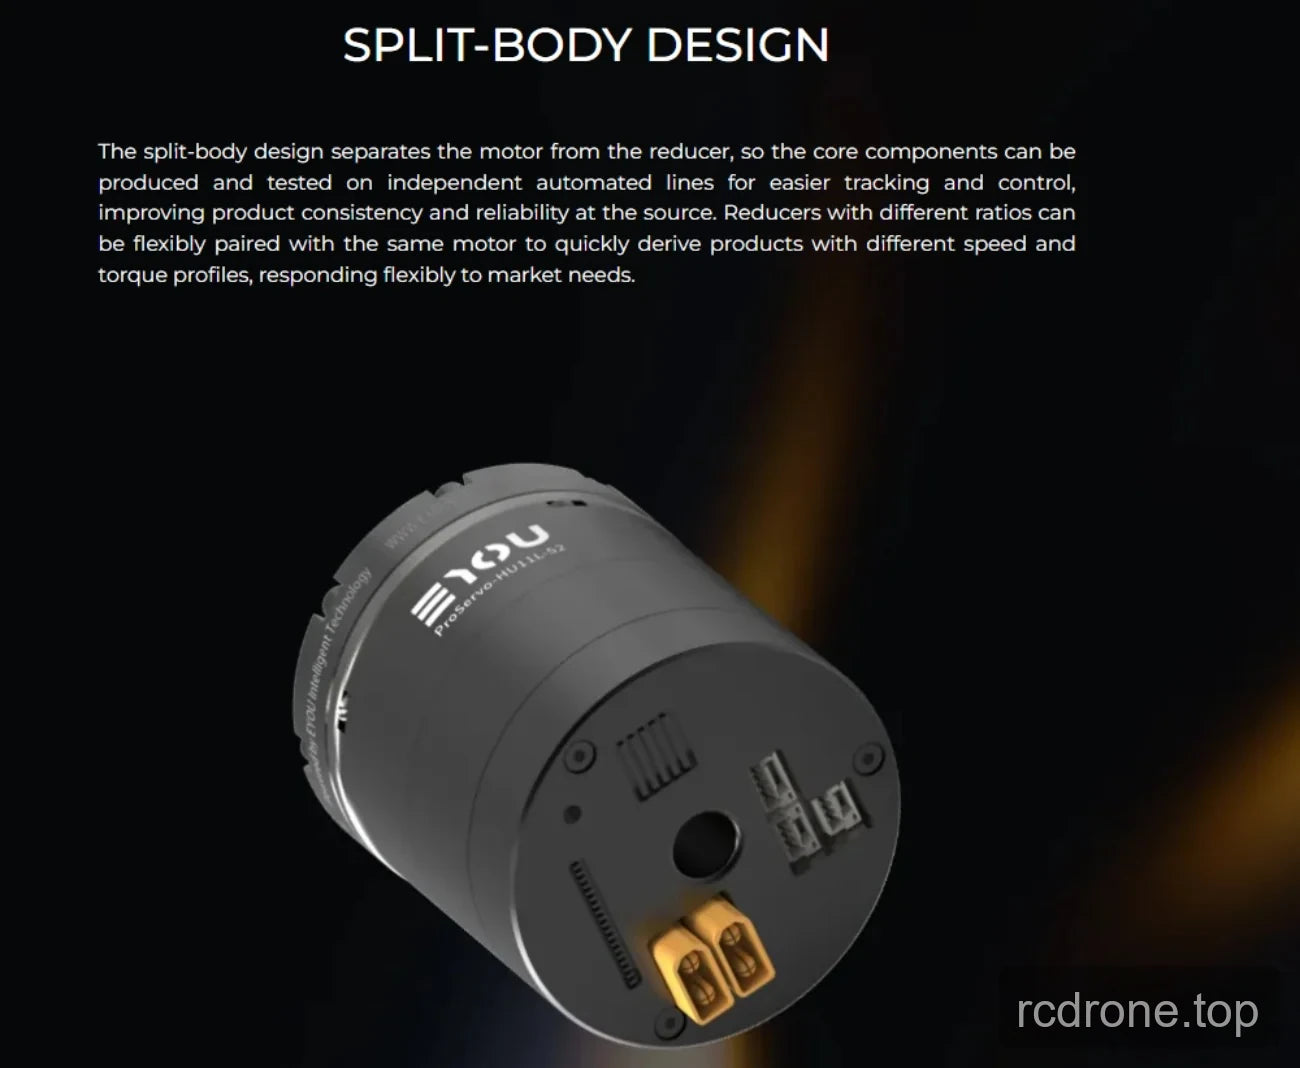
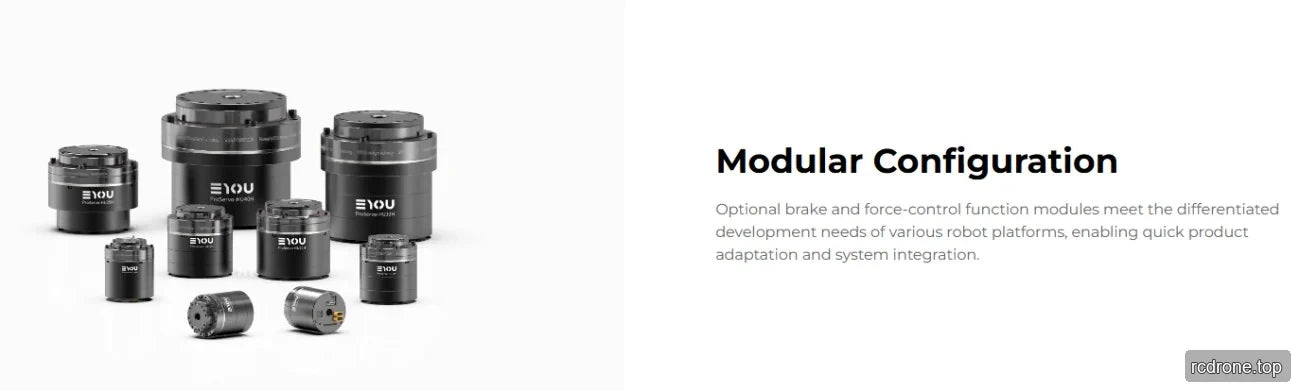
- PHU series information describes a split-body design that separates the motor and reducer, allowing different reducer ratios to be paired with the same motor for different speed and torque profiles.
- PHU series information also describes optional force-control function modules; availability of those modules is not established by the PHU32H-142 selections.
Specifications
Shared Specifications
| Parameter | Value |
|---|---|
| Module model | PHU-32H-142 |
| Reducer type | Harmonic |
| Motor rated power | 603 W |
| Motor rated torque | 2.4 N·m |
| Motor peak torque | 9.6 N·m |
| Backlash | ≤20 arcsec for ratios 81 / 101 / 121 / 161 |
| Brake (B/N) | B/N |
| Dimensions (outer diameter × axial) | Φ142 × 144 mm |
| Weight (B/N) | 6.31 / 5.83 kg |
| Hollow diameter | 22 mm |
| Housing appearance (process color) | Black anodized |
| Reducer appearance (process color) | Outer ring blackened |
| Radial (dynamic/static) allowable load at output | 1350 N |
| Axial (dynamic/static) allowable load at output | 1350 N |
| Output bending moment | 460 N·m |
| Reducer torsional stiffness | 99000 / 99000 / 99000 / 99000 N·m/rad for ratios 81 / 101 / 121 / 161 |
| Rated operating voltage | 48 VDC |
| Operating voltage range | 24–48 VDC |
| Driver | Built-in |
| Encoder/bit | Dual absolute / motor side 17 bit & reducer side 19 bit |
| Driver interface (see terminal model description) | Power (DC in/DC out), CAN FD (In, Out), EtherCAT (In, Out), STO (1, 2) |
| Communication protocol (see communication description) | EtherCAT / CANopen |
| Control modes | Profile Position (PP), Profile Velocity (PV), Profile Torque (PT), Cyclic Synchronous Position (CSP), Cyclic Synchronous Velocity (CSV), etc. |
| Operating ambient temperature | -20–60 °C |
| Housing temperature rise | ≤60 °C |
| Noise | ≤60 dB |
| Life | >10000 h |
Ratio-Specific Performance
| Parameter | Ratio 81 | Ratio 101 | Ratio 121 | Ratio 161 |
|---|---|---|---|---|
| Joint rated power — life constraint | 377 W | 350 W | 293 W | 220 W |
| Rated torque at 2000 rpm input | 146 N·m | 169 N·m | 169 N·m | 169 N·m |
| Average load torque at output | 206 N·m | 267 N·m | 267 N·m | 267 N·m |
| Peak torque at output | 376 N·m | 411 N·m | 436 N·m | 459 N·m |
| Max. allowable external torque at output (instantaneous) | 702 N·m | 800 N·m | 848 N·m | 848 N·m |
| Rated speed at output — life constraint | 25 rpm | 20 rpm | 17 rpm | 12 rpm |
| Peak speed at output | 30 rpm | 24 rpm | 20 rpm | 15 rpm |
| Reducer input inertia (B) | 1171.326 kg·mm² | 1171.326 kg·mm² | 1171.326 kg·mm² | 1171.526 kg·mm² |
| Equivalent joint output inertia (B) | 7685070 kg·mm² | 11948697 kg·mm² | 17149384 kg·mm² | 30361941 kg·mm² |
Applications
- Humanoid robots
- Robotic arms and collaborative robotic arms
- Exoskeletons
- Quadruped robots
- AGV vehicles
- ARU robots
- Industrial automation
Downloads
- EYOU CANable — User Manual (PDF)
- PHU32 EYOU — 3D Model (STEP)
- EYOU PHU32H 142 Drawing — Drawing (PDF)
- EYOU PHU RHU Series Joint CANopen EtherCAT Communication — Manual (PDF)
- EYOU Robot Joint Catalog — Robot Joint Product Catalog (PDF)
- EYOU RP Series EN V1.0 20260608 — User Manual (PDF)
- EYOU UART Debug Module — User Manual (PDF)
Visual Details
Product Views
Features and Design
Application Examples
Options and Model Comparison
Interfaces and Connections
Additional Product Details