


Kpower EM10 Overload-Clutch Robot Servo Motor, 300° Travel, 10 kg·cm Stall at 12 V for Robot Joints
Kpower EM10 Overload-Clutch Robot Servo Motor, 300° Travel, 10 kg·cm Stall at 12 V for Robot Joints
Kpower
Couldn't load pickup availability


Overview
The Kpower EM10 is an overload-clutch robot servo motor for desktop robot arms, educational robots and multi-legged bionic mechanisms. Its 300° travel and dual servo-horn design support robot-joint movement, while a 2000 Hz current loop enables precision force control. Rated for 9–13 V operation, it delivers 10 kg·cm stall torque at 12 V. The EM10 model specifications list PWM, TTL and RS-485 control protocols.
Features
- EC225 custom chip with a 2000 Hz current loop for precision force control.
- Gear-clutch anti-impact protection and overload-clutch disengagement protection for robot-joint operation.
- Dual servo-horn design with circular horns on opposite faces of a rectangular housing.
- 300° operating range, with customizable travel.
- Multiple feedback support.
- Low-noise design.
- Plastic housing marked EM-10, POM gears, a DC brushed motor and potentiometer position sensing.
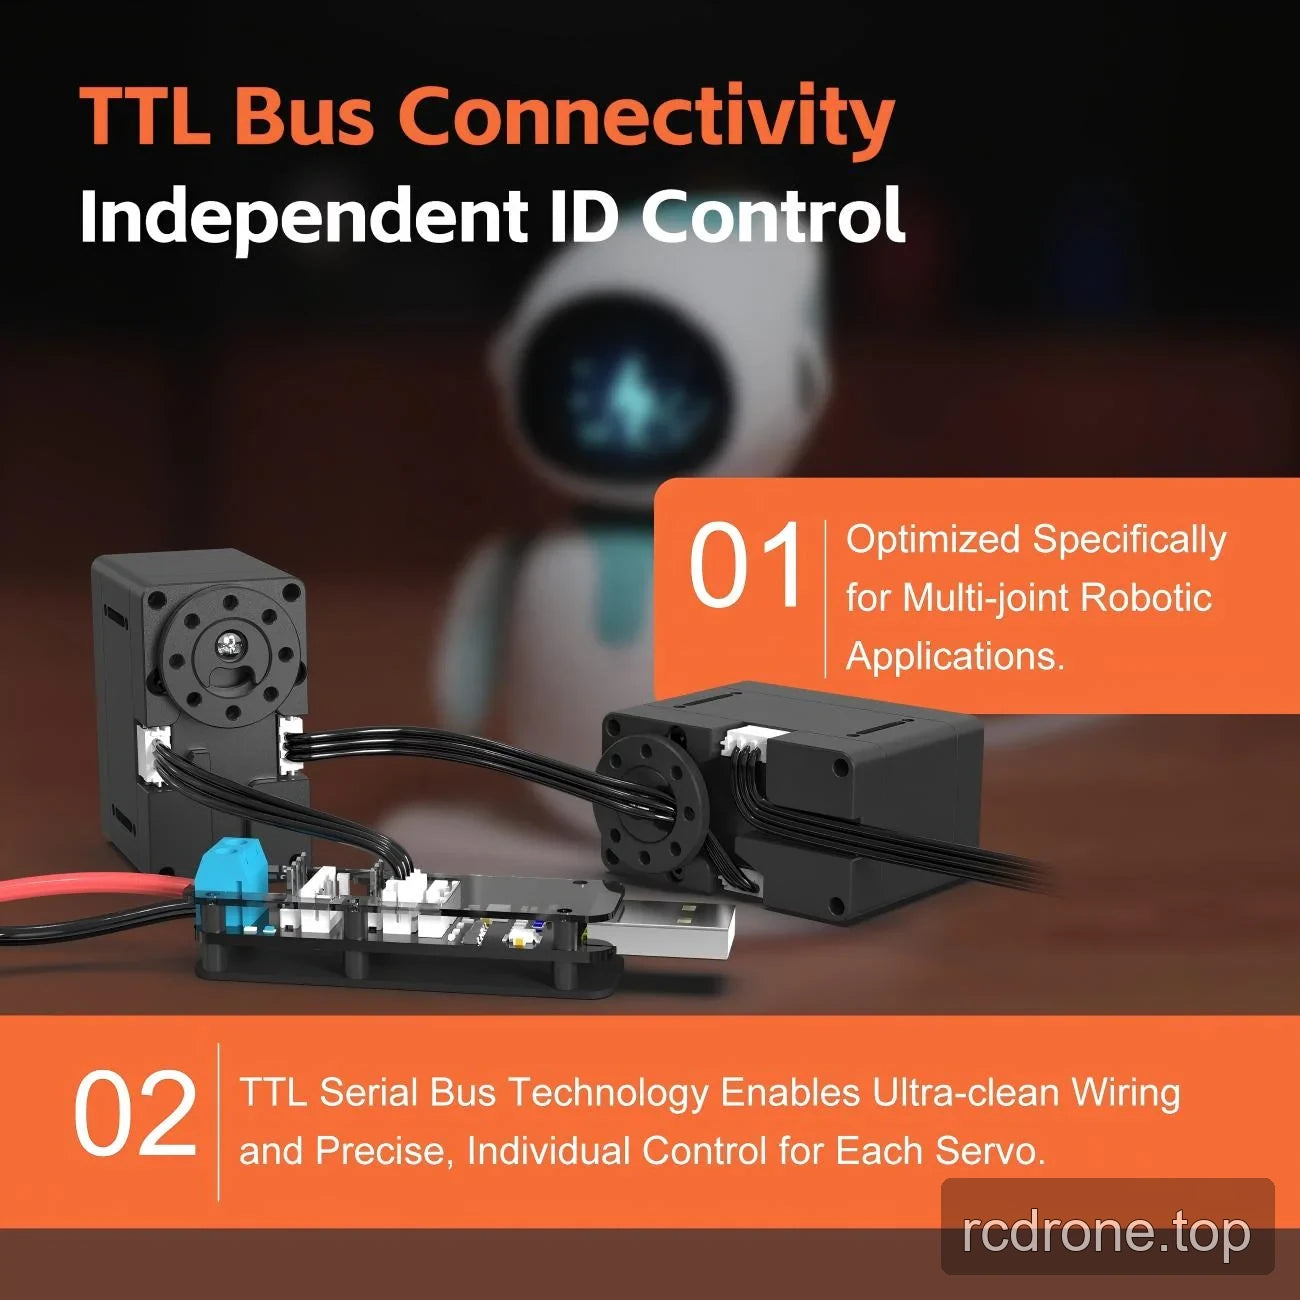
TTL Serial-Bus Control
The TTL implementation supports interconnected servos with independent ID control. Serial-bus wiring simplifies connections and allows individual servo control in multi-joint robotic mechanisms.
Specifications
| Parameter | EM10 specification |
|---|---|
| Model | EM10; housing marking EM-10 |
| Servo type | Overload-clutch robotic servo |
| Stall torque | 10 kg·cm at 12 V |
| No-load speed | 0.2 s/60° at 12 V |
| Operating voltage | 9–13 V |
| Travel angle / operating range | 300°; customizable |
| Weight | 56 g |
| Dimensions | 48 × 26 × 44 mm |
| Wire length | 150 mm |
| Model-level protocol listing | PWM, TTL, RS-485 |
| TTL control | Serial bus with independent servo ID control |
| Stall current | 3000 mA |
| No-load current | 1000 mA |
| Working frequency | 50–333 Hz |
| Current-loop frequency | 2000 Hz |
| Control chip | EC225 custom chip |
| Gear material | POM |
| Case material | Plastic |
| Motor | DC brushed |
| Position sensor | Potentiometer |
| Horn gear spline | N/A |
| Ball bearings | 2BB |
| Operating temperature | −10 to 50 °C |
| IP rating | IP42 |
Applications
- Desktop robot arms: Actuate articulated joints using 300° travel and dual servo-horn support; the stall torque specification is 10 kg·cm at 12 V.
- Multi-legged, quadruped, bionic and bio-inspired robots: Drive leg-joint movement with gear-clutch anti-impact and overload-disengagement protection.
- Educational robots and STEAM projects: Build mechanisms for studying joint movement and force control using the 300° operating range and 2000 Hz current loop.
- Service robots: Control articulated mechanisms; the TTL implementation allows individual servo addressing in multi-joint assemblies.
- Smart-home mechanisms: Actuate custom moving mechanisms using position sensing and controlled angular travel.
Configuration and Integration
Discuss wire-length, control-type and position-sensor requirements with the supplier before integration. Use the 9–13 V operating range; the quoted stall torque and no-load speed apply at 12 V.
Documents
- Kpower EM10 Drawing — Drawing (PDF)
- Kpower Servo 3 — Manual (PDF)
- OCServo OCS 351CAN Drawing — Ocservo Ocs 351 Can Drawing (PDF)
Product Videos
Visual Details
Product Video
Features and Design


Specifications and Performance


Application Examples


Product Views

Interfaces and Connections
Options and Model Comparison


