


ZeroErr eRob 80 I Robot Joint Actuator, CANopen/EtherCAT, 50–120 Reduction Ratios
ZeroErr eRob 80 I Robot Joint Actuator, CANopen/EtherCAT, 50–120 Reduction Ratios
ZeroErr
Regular price
$1,771.00 USD
Regular price
Sale price
$1,771.00 USD
Unit price
per
Taxes included.
Shipping calculated at checkout.
Couldn't load pickup availability


Overview
The ZeroErr eRob 80 I is a robot joint actuator motor available in CANopen and EtherCAT versions, with selectable brake, reduction-ratio, and multi-turn/torque configurations.
Features
- CANopen and EtherCAT version selections.
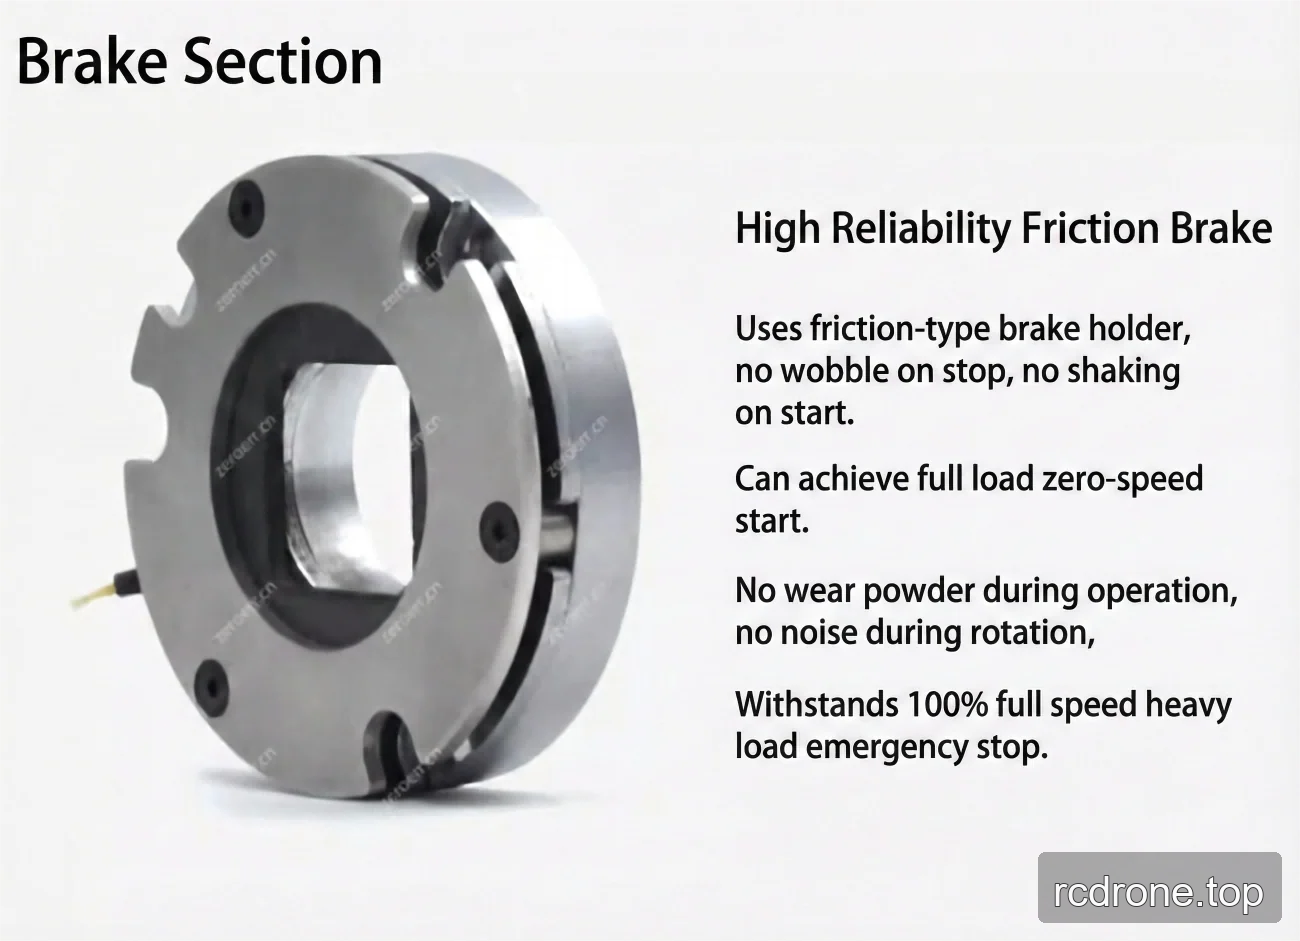
- Brake-equipped and without-brake version selections; the listed brake model is a friction brake.
- Selectable reduction ratios of 50, 80, 100, and 120.
- Selectable multi-turn and torque configurations.
- Optional-device communication types listed as EtherCAT, CANopen, and Modbus.
- Output encoder resolution: 19 Bit.
- For both EtherCAT and CANopen rotary-actuator versions, optional interfaces are RS485, Pulse/DIR, I/O, ±10 V analog, and STO.
Specifications
Configuration Options
| Selection | Available values |
|---|---|
| Version | eRob 80 I (CANopen With Brake); eRob 80 I (CANopen Without Brake); eRob 80 I (EtherCAT With Brake); eRob 80 I (EtherCAT Without Brake) |
| Reduction Ratio | 50; 80; 100; 120 |
| Multi-turn and Torque | Without Multi-turn and Without Torque; Without Multi-turn and With Torque; With Multi-turn and Without Torque; With Multi-turn and With Torque |
Strain Wave Gear-Ratio Performance
| Parameter | 17-50 | 17-80 | 17-100 | 17-120 |
|---|---|---|---|---|
| Peak torque for start and stop (Nm) | 44 | 56 | 70 | 70 |
| Permissible max. value at average load torque (Nm) | 34 | 35 | 51 | 51 |
| Rated torque (Nm) | 21 | 29 | 31 | 31 |
| Permissible maximum momentary torque (Nm) | 91 | 113 | 143 | 112 |
| Max. output rotational speed (RPM) | 60 | 37.5 | 30 | 25 |
| Motor power (W) | 126 | |||
| Power input voltage (V) | 48 V (±10%) | |||
| Strain wave gear output inertia (g·mm²) | 143080 | |||
| Strain wave gear output mass (kg) | 0.227 | |||
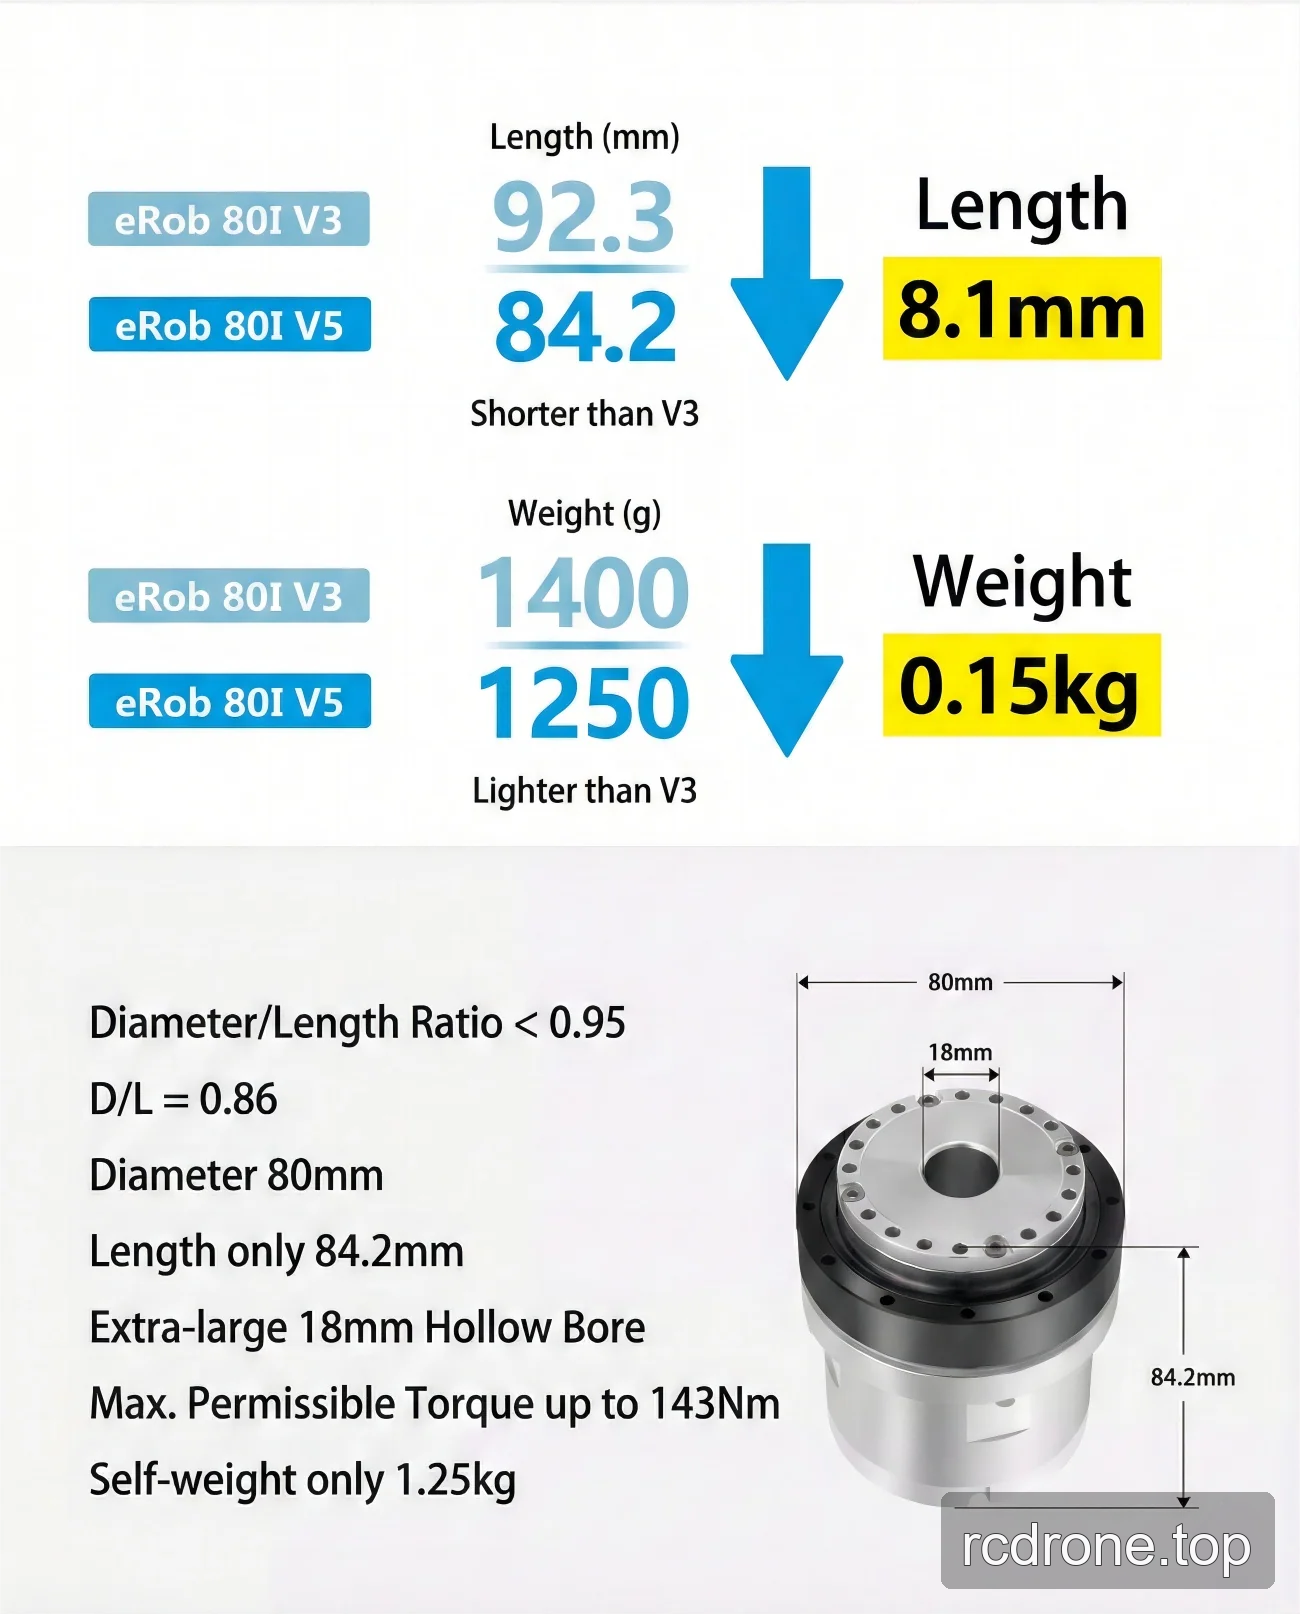
| Outer diameter × length | 80 × 64.2 mm | |||
| Strain wave gear input inertia (g·mm²) | 41815 | |||
| Strain wave gear input mass (kg) | 0.148 | |||
| Weight (kg) | 1.03 | |||
| Common parameters | ID: 18 mm; IP grating: IP54*; Brake model: friction brake | |||
| Optional device | Communication type: EtherCAT / CANopen / Modbus; Output encoder resolution: 19 Bit; Repeatability/Accuracy: ±7/±15 arc seconds or ±10/±25 arc seconds. | |||
| EtherCAT version rotary actuator | Optional interface: RS485, Pulse/DIR, I/O, ±10 V Analog and STO. | |||
| CANopen version rotary actuator | Optional interface: RS485, Pulse/DIR, I/O, ±10 V Analog and STO. | |||
Downloads
- EROB70F I Series CANopen EROB80I — Installation Drawing (PDF)
- EROB80I I Series EtherCAT — 3D Model (ZIP)
- EROB70F I Series CANopen — 3D Model (PDF)
- EROB80I I Series CANopen — 3D Model — STEP File (ZIP)
- EROB80I I Series EtherCAT instalation drawing — Installation Drawing (PDF)
- EROB80I I Series CANopen instalation drawing — Installation Drawing (PDF)
Applications
- Humanoid robots
- Robotic arms
- Exoskeletons
- Quadruped robots
- AGV vehicles
- ARU robots
Visual Details
Product Video
Product Views

Dimensions and Construction
Options and Model Comparison

Features and Design

Interfaces and Connections

Specifications and Performance

Application Examples



