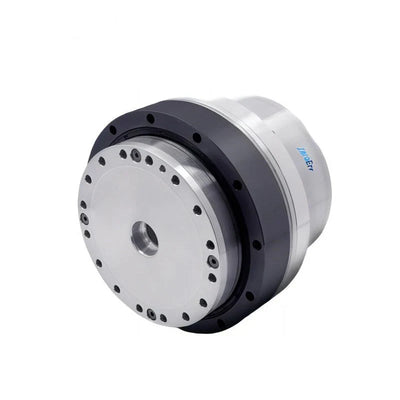
ZeroErr eRob 90 I Robot Joint Motor, EtherCAT/CANopen, 50–120 Reduction Ratio
ZeroErr eRob 90 I Robot Joint Motor, EtherCAT/CANopen, 50–120 Reduction Ratio
ZeroErr
Regular price
$2,025.00 USD
Regular price
Sale price
$2,025.00 USD
Unit price
per
Taxes included.
Shipping calculated at checkout.
Couldn't load pickup availability


Overview
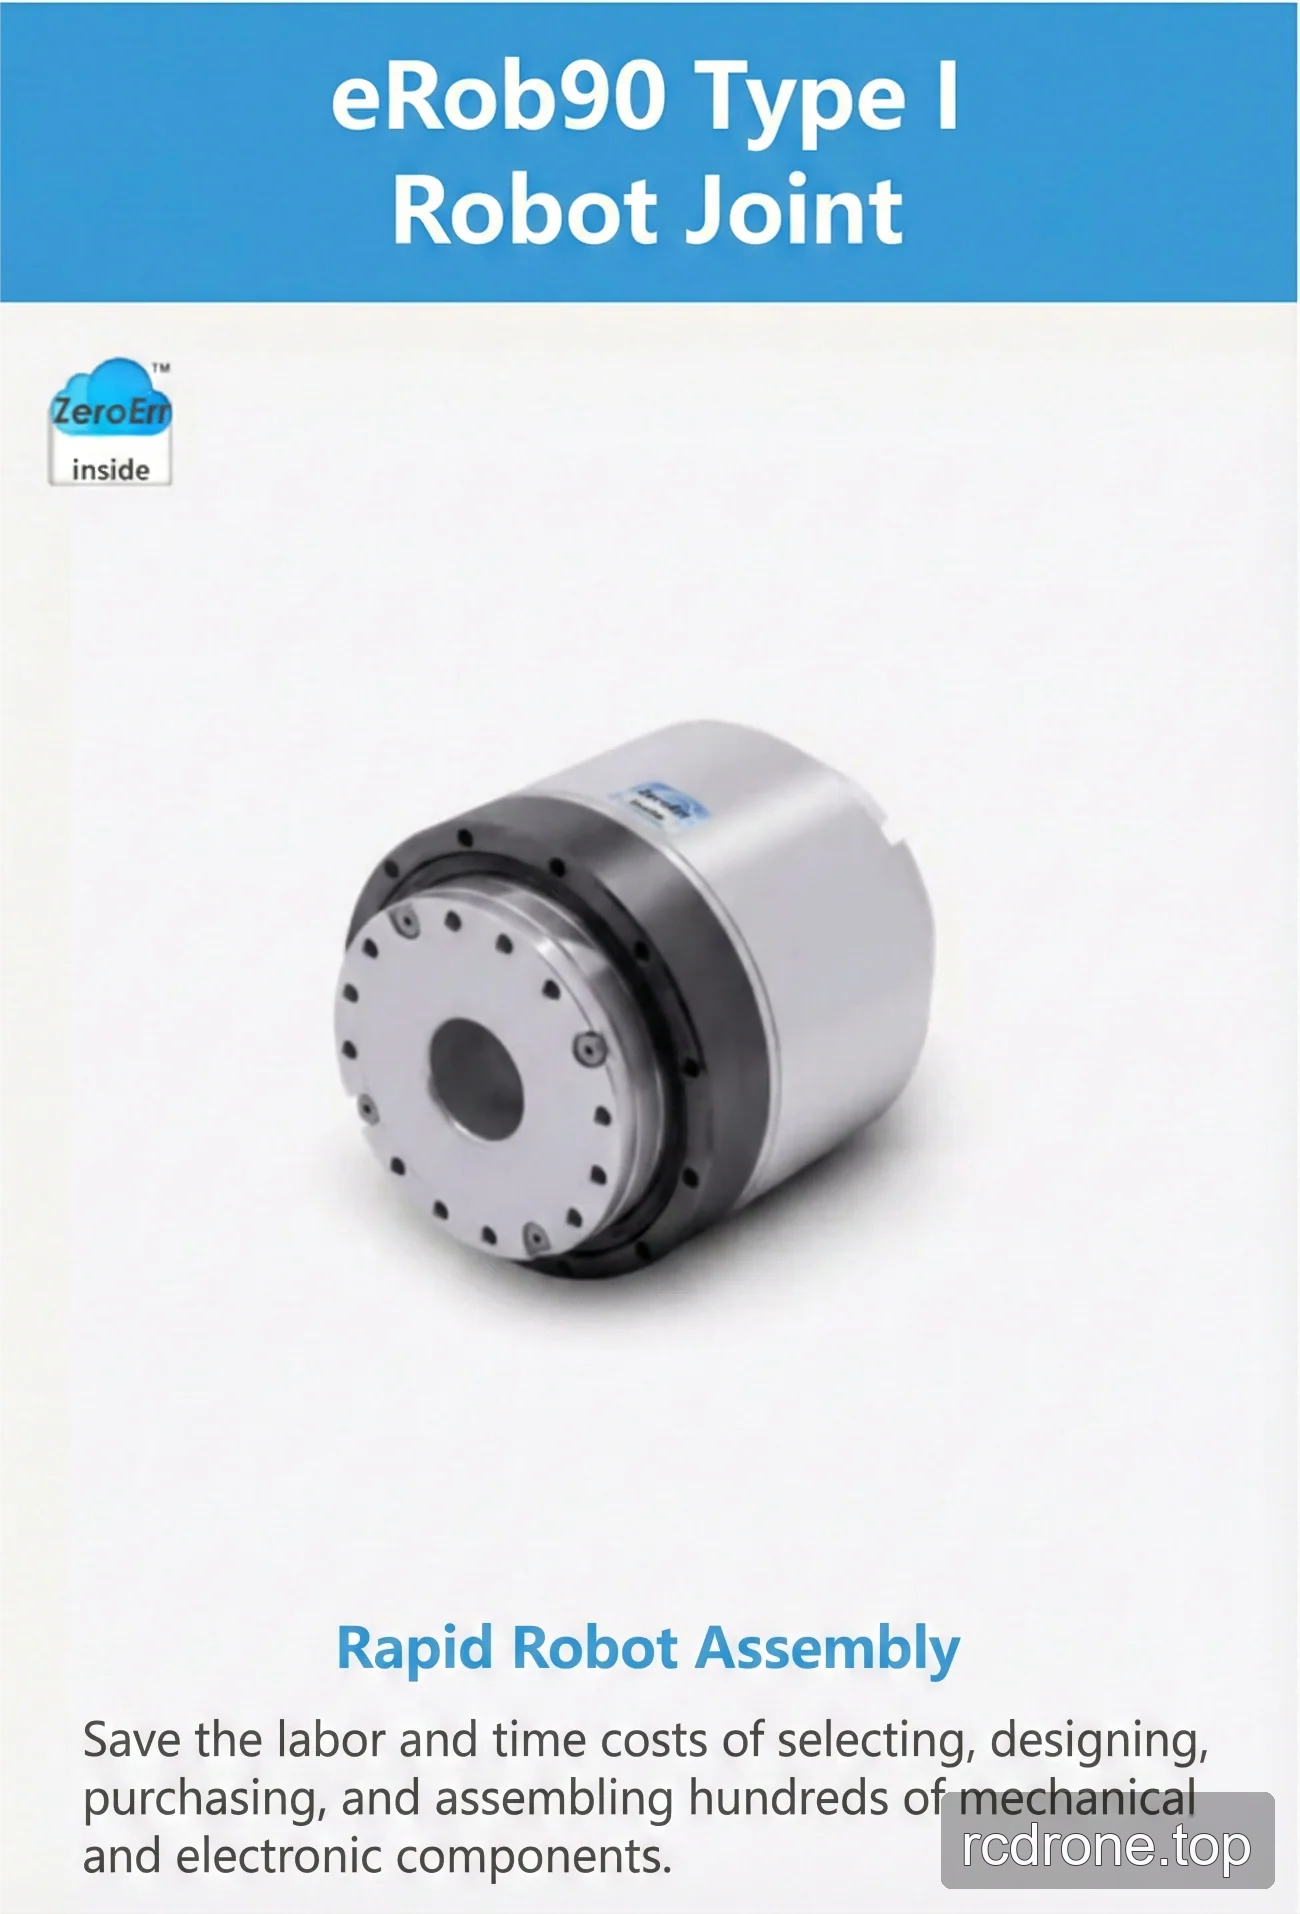
The ZeroErr eRob 90 I robot joint motor is offered in CANopen and EtherCAT versions, with or without a brake, for robot-joint configurations and rapid robot assembly.
Features and Configuration
- Communication versions: CANopen or EtherCAT.
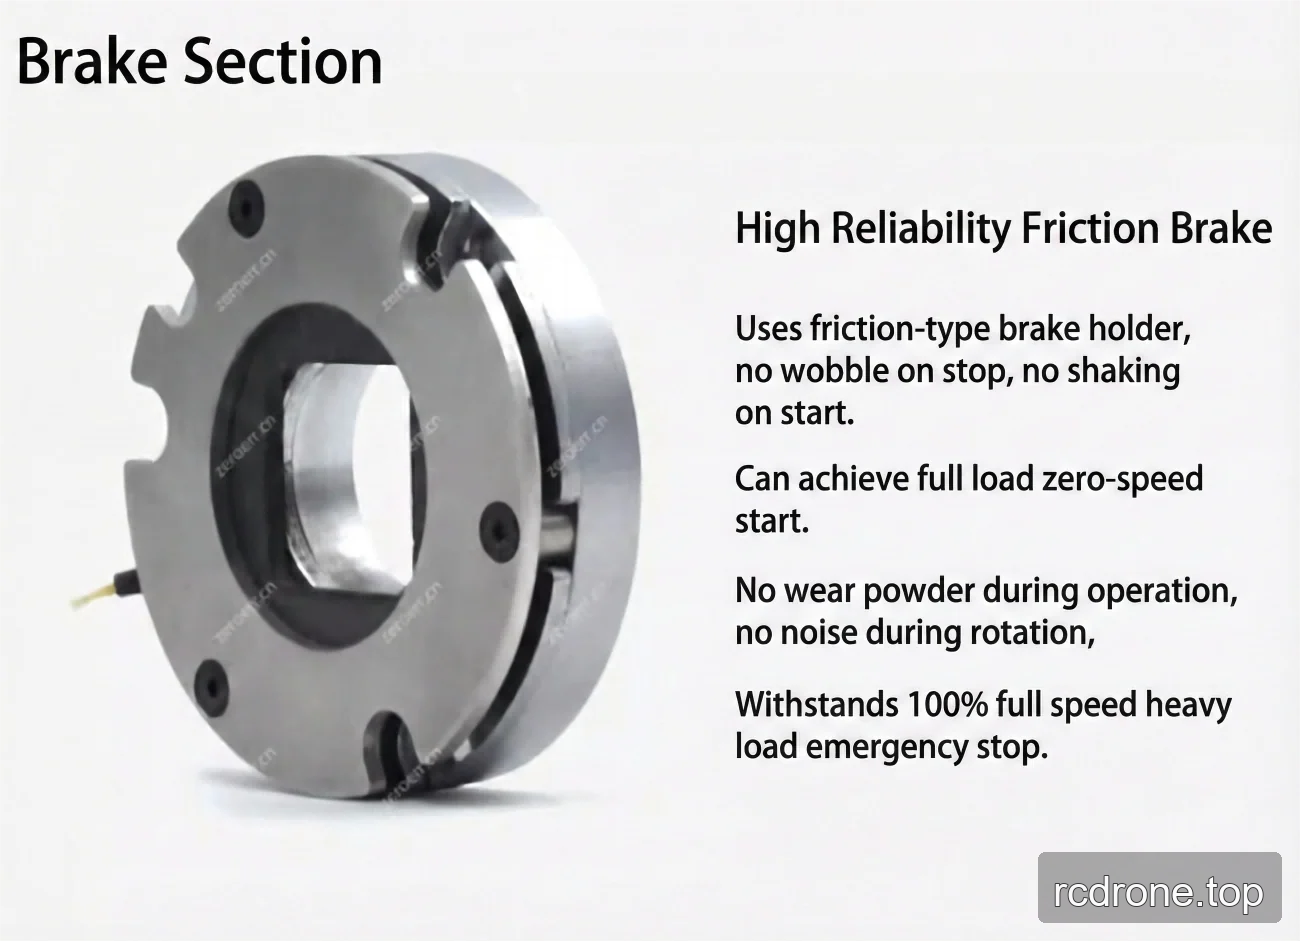
- Brake configurations: with brake or without brake. The listed brake model is a friction brake.
- Reduction-ratio selections: 50, 80, 100, and 120.
- Multi-turn and torque selections: Without Multi-turn and Without Torque; Without Multi-turn and With Torque; With Multi-turn and Without Torque; With Multi-turn and With Torque.
- Specified power input voltage: 48 V (±10%).
- Specified hollow bore diameter: 18 mm.
- Specified installation methods: Same, Compatible.
Specifications
Strain Wave Gear Ratio
| Strain wave gear-ratio | 20-50 | 20-80 | 20-100 | 20-120 |
|---|---|---|---|---|
| Peak torque for start and stop (Nm) | 73 | 96 | 107 | 113 |
| Permissible max. value at average load torque (Nm) | 44 | 61 | 64 | 64 |
| Rated torque (Nm) | 33 | 44 | 52 | 52 |
| Permissible maximum momentary torque (Nm) | 127 | 165 | 191 | 191 |
| Max. output rotational speed (RPM) | 60 | 37.5 | 30 | 25 |
| Power input voltage (V) | 48 V (±10%) | |||
| Hollow bore diameter | 18 mm | |||
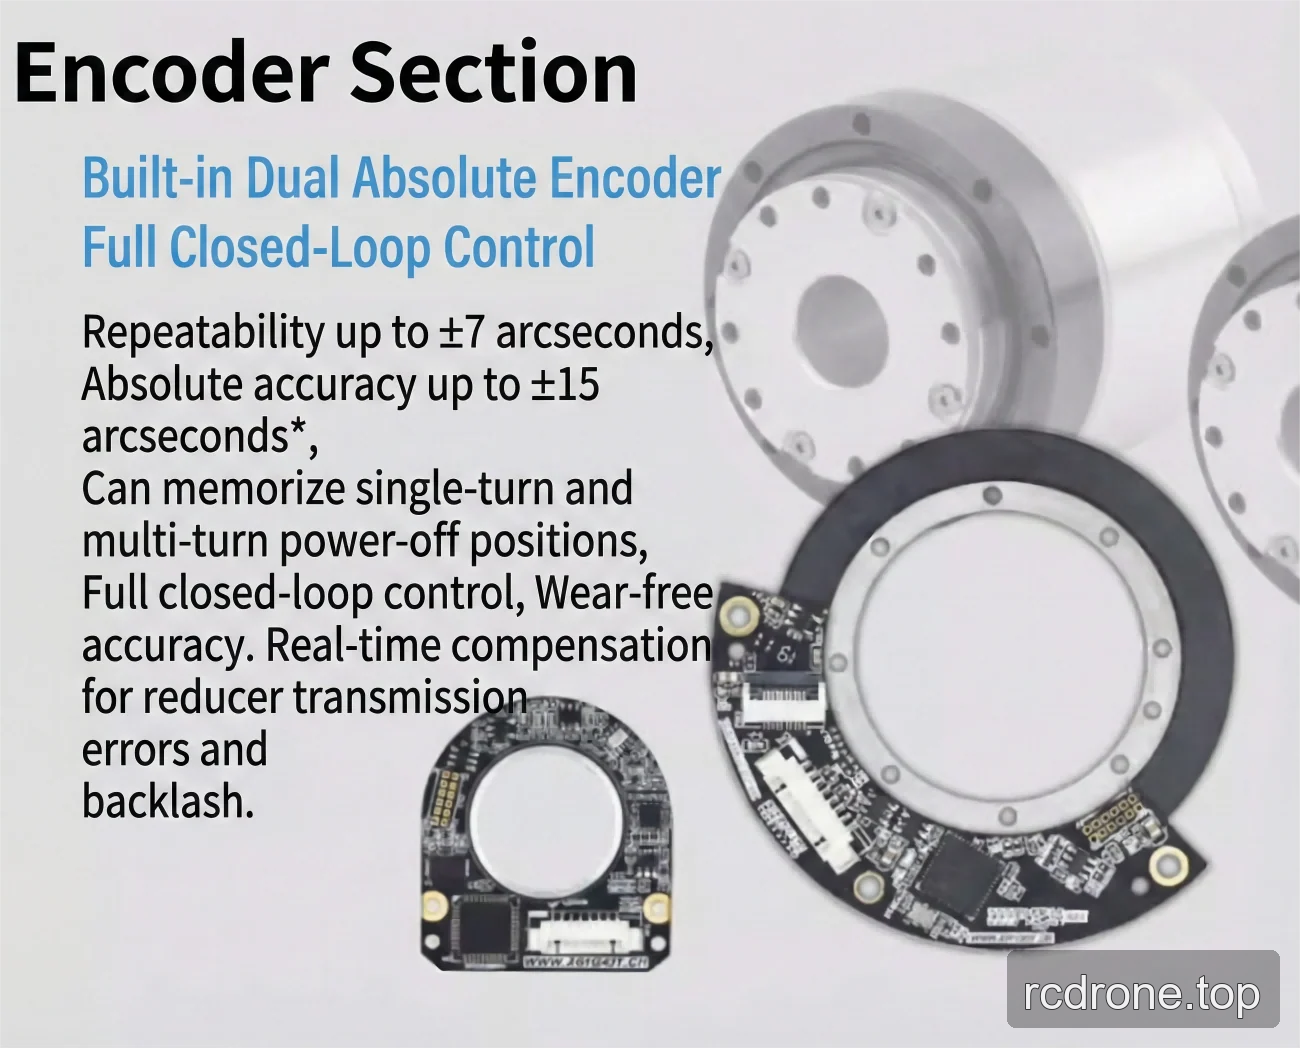
| Precision | Repeatability/Absolute Accuracy: ±7/±15 arc sec or ±10/±25 arc sec* | |||
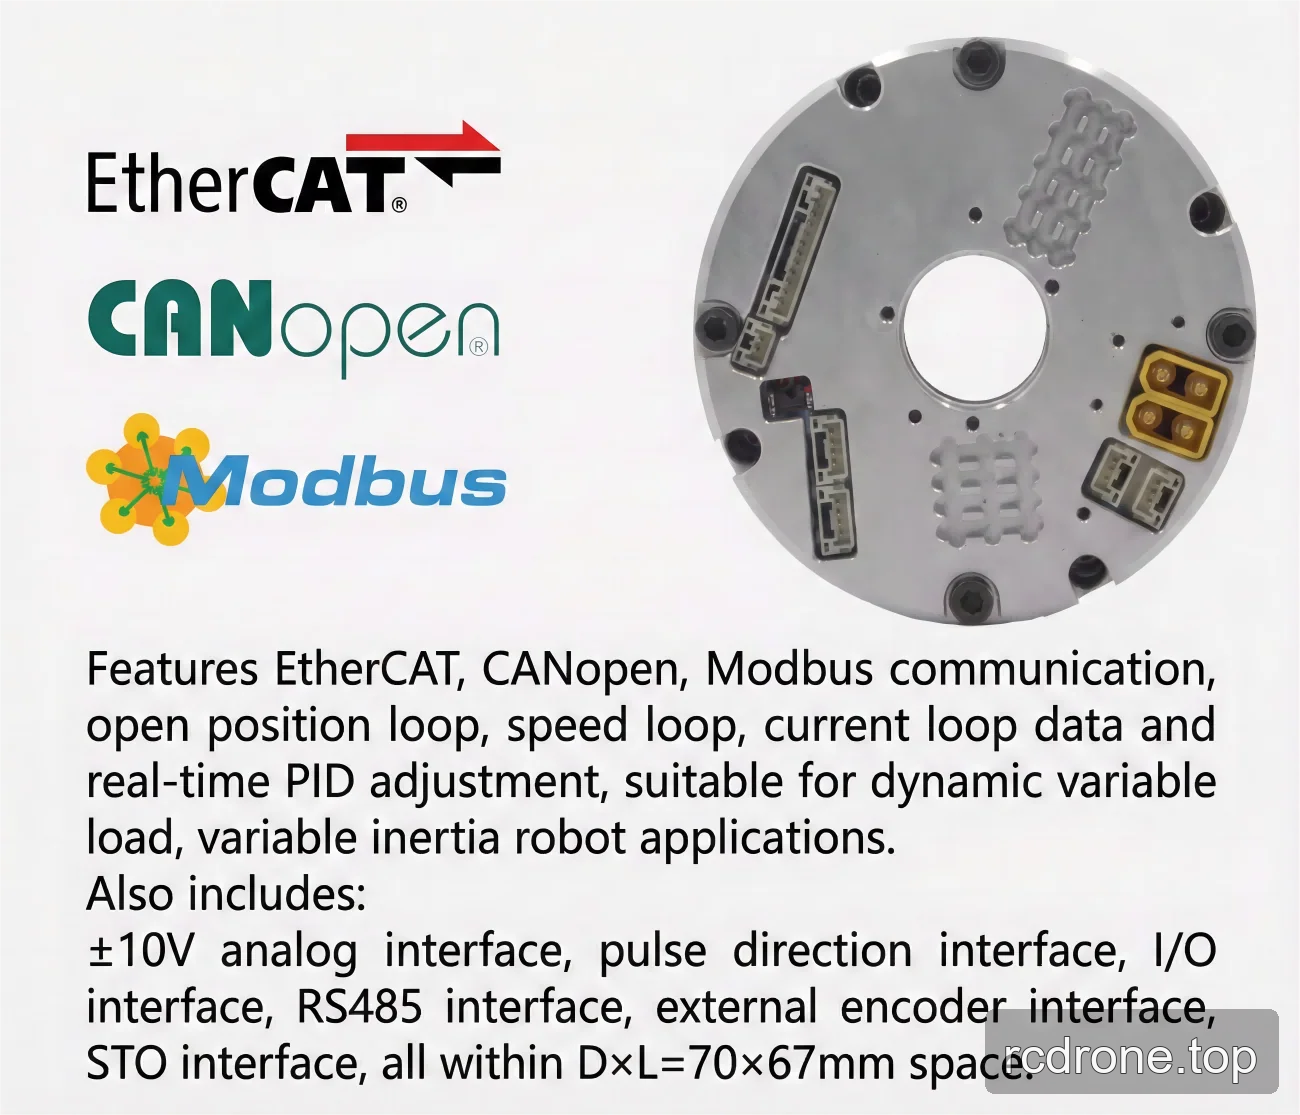
| Electrical interface | Communication Protocol: EtherCAT/CANopen/Modbus; Output-side Encoder Resolution: 19/20 Bit | |||
| Installation methods | Same, Compatible | |||
V3/V6 Comparison
| Version | V3 | V6 |
|---|---|---|
| Motor power (W) | 300 | 314 |
| SWG output-side inertia (g-mm2) | 297466 | 273391 |
| SWG output-side mass (kg) | 0.36 | 0.321 |
| SWG input-side inertia (g·mm²), without brake | 139067 | 95791 |
| SWG input-side mass (kg), without brake | 0.41 | 0.257 |
| OD × length (mm), without brake | Φ90 × 98.9 | Φ90 × 75.9 |
| Total mass (kg), without brake | 1.75 | 1.506 |
| SWG input-side inertia (g·mm²), with brake | 147025 | 110213 |
| SWG input-side mass (kg), with brake | 0.43 | 0.292 |
| OD × length (mm), with brake | Φ90 × 98.9 | Φ90 × 75.9 |
| Total mass (kg), with brake | 1.87 | 1.639 |
| Diameter-to-length ratio | D/L = 0.91 (less than 1) | — |
| Common parameters | ID: 18 mm; IP grating: IP54*; Brake model: friction brake | |
| Optional device | Communication type: EtherCAT/CANopen/Modbus; Output encoder resolution: 19 Bit; Repeatability/Accuracy: ±7/±15 arc seconds or ±10/±25 arc seconds. | |
Applications
- Humanoid robots
- Robotic arms
- Exoskeletons
- Quadruped robots
- AGV vehicles
- ARU robots
- Collaborative robots
- Medical robots
- Automation equipment
Downloads
Downloads & Resources
- EROB70F I Series CANopen EROB90I — Installation Drawing (PDF)
- EROB90I I Series EtherCAT — 3D Model (STEP)
- EROB90I I Series CANopen — 3D Model (STEP)
- EROB90I I Series EtherCAT instalation drawing — Installation Drawing (PDF)
- EROB90I I Series CANopen instalation drawing — Installation Drawing (PDF)
Visual Details
Product Video
Product Views
Dimensions and Construction

Features and Design

Interfaces and Connections
Application Examples