LinkDynamics HT52 XDrive Motor, 48 V CAN Robotic Joint Actuator
LinkDynamics HT52 XDrive Motor, 48 V CAN Robotic Joint Actuator
LinkDynamics
नियमित रूप से मूल्य
$156.00 USD
नियमित रूप से मूल्य
विक्रय कीमत
$156.00 USD
यूनिट मूल्य
प्रति
Taxes included.
शिपिंग की गणना चेकआउट के समय की जाती है।
पिकअप उपलब्धता लोड नहीं की जा सकी
Overview
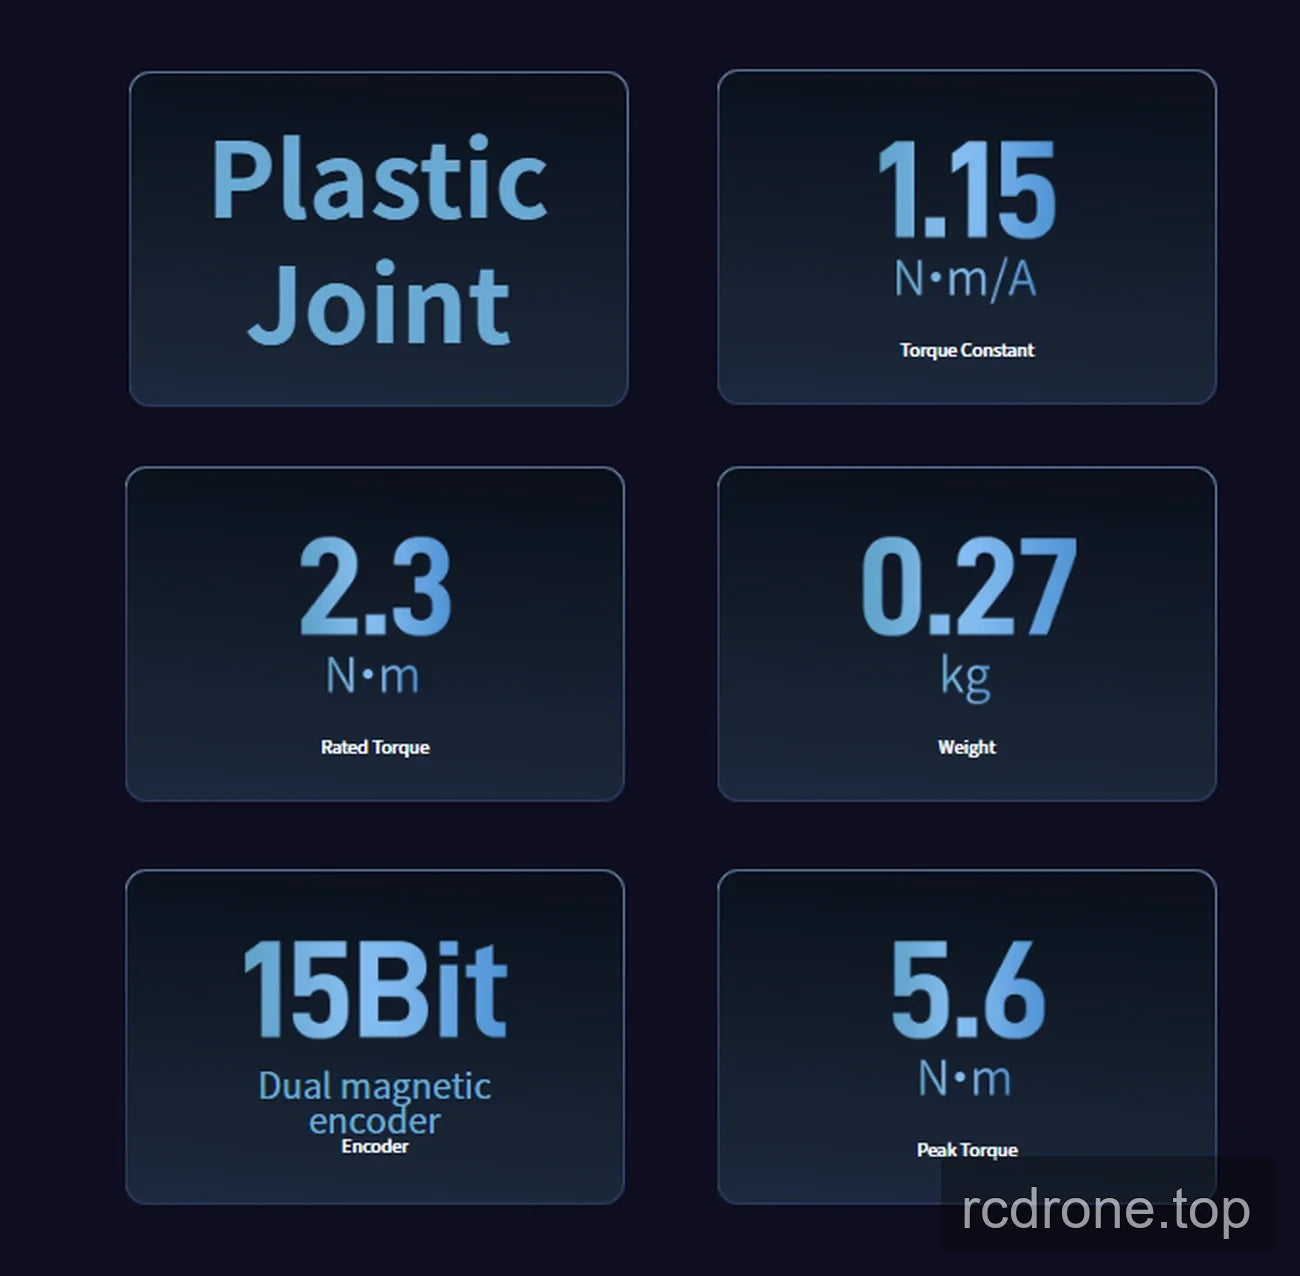
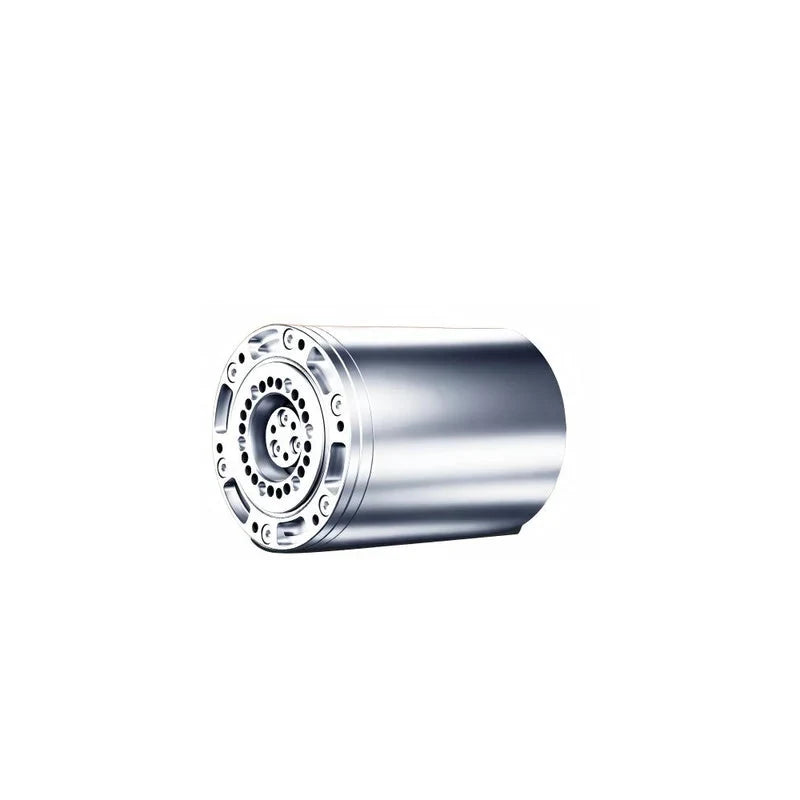
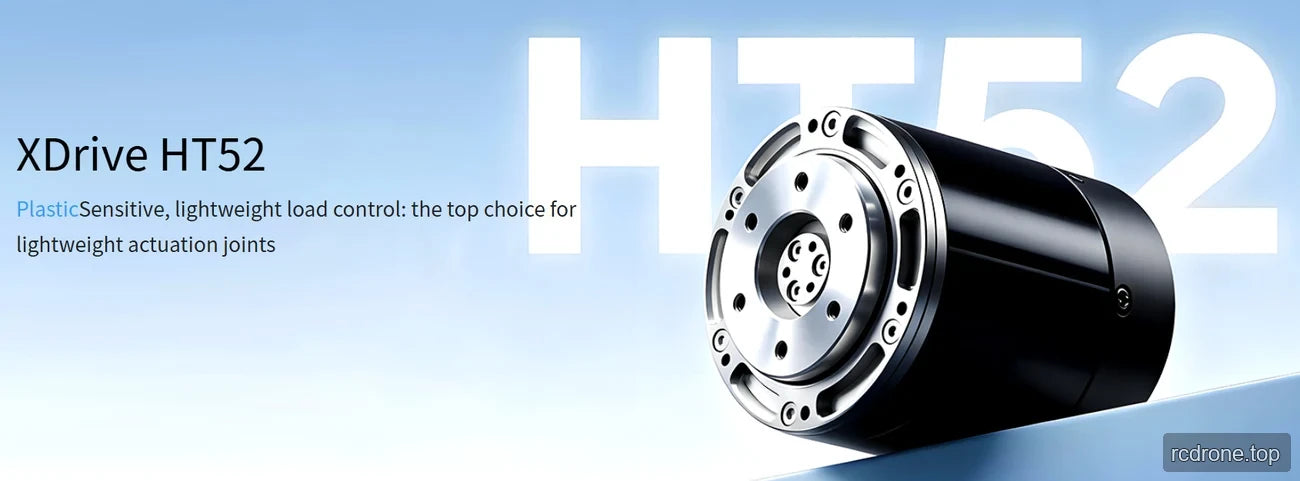
The LinkDynamics HT52 is an XDrive motor for lightweight actuation joints. It operates at 48 V, communicates via CAN, and uses a dual 15-bit magnetic encoder.
Features
- Designed for lightweight actuation joints and lightweight load control.
- Integrated joint drive system positioning.
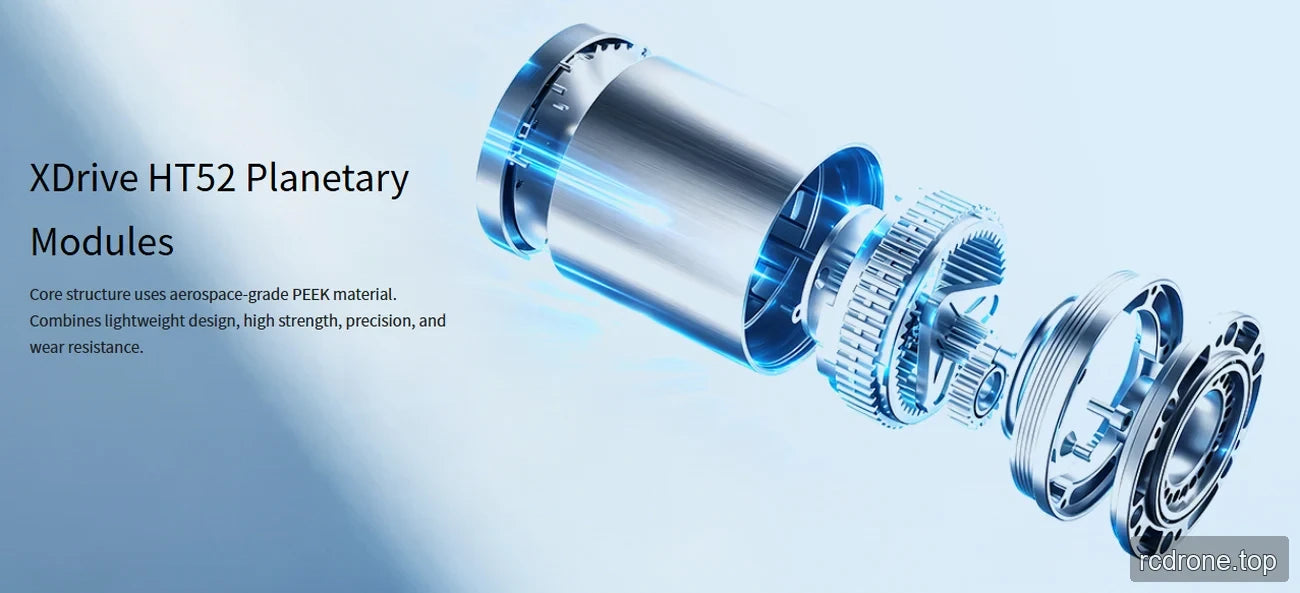
- Planetary modules with an aerospace-grade PEEK core structure.
- Planetary-module design is described as lightweight, high-strength, precise, and wear-resistant.
Specifications
| Parameter | HT52 |
|---|---|
| Gear Ratio | 36 |
| Rated Voltage | 48 V |
| Rated Phase Current | 2 A |
| Rated Power | 75 W |
| Rated Speed | 111 rpm |
| Rated Torque | 2.3 Nm |
| Peak Speed | 167 rpm |
| Peak Phase Current | 5.6 A |
| Peak Torque | 5.6 Nm |
| Motor Efficiency | 80% |
| Torque Constant | 1.15 Nm/A |
| Reducer Backlash | 15 arcmin |
| Communication | CAN |
| Encoder | Dual magnetic encoder, 15-bit |
| Weight | 0.27 kg |
| Torque Density | / |
| Joint Designation | Plastic joint |
Applications
The HT52 is presented for joint actuation in home robots and for the following applications:
- Humanoid robots
- Robotic arms
- Exoskeletons
- Quadruped robots
- AGV vehicles
- ARU robots
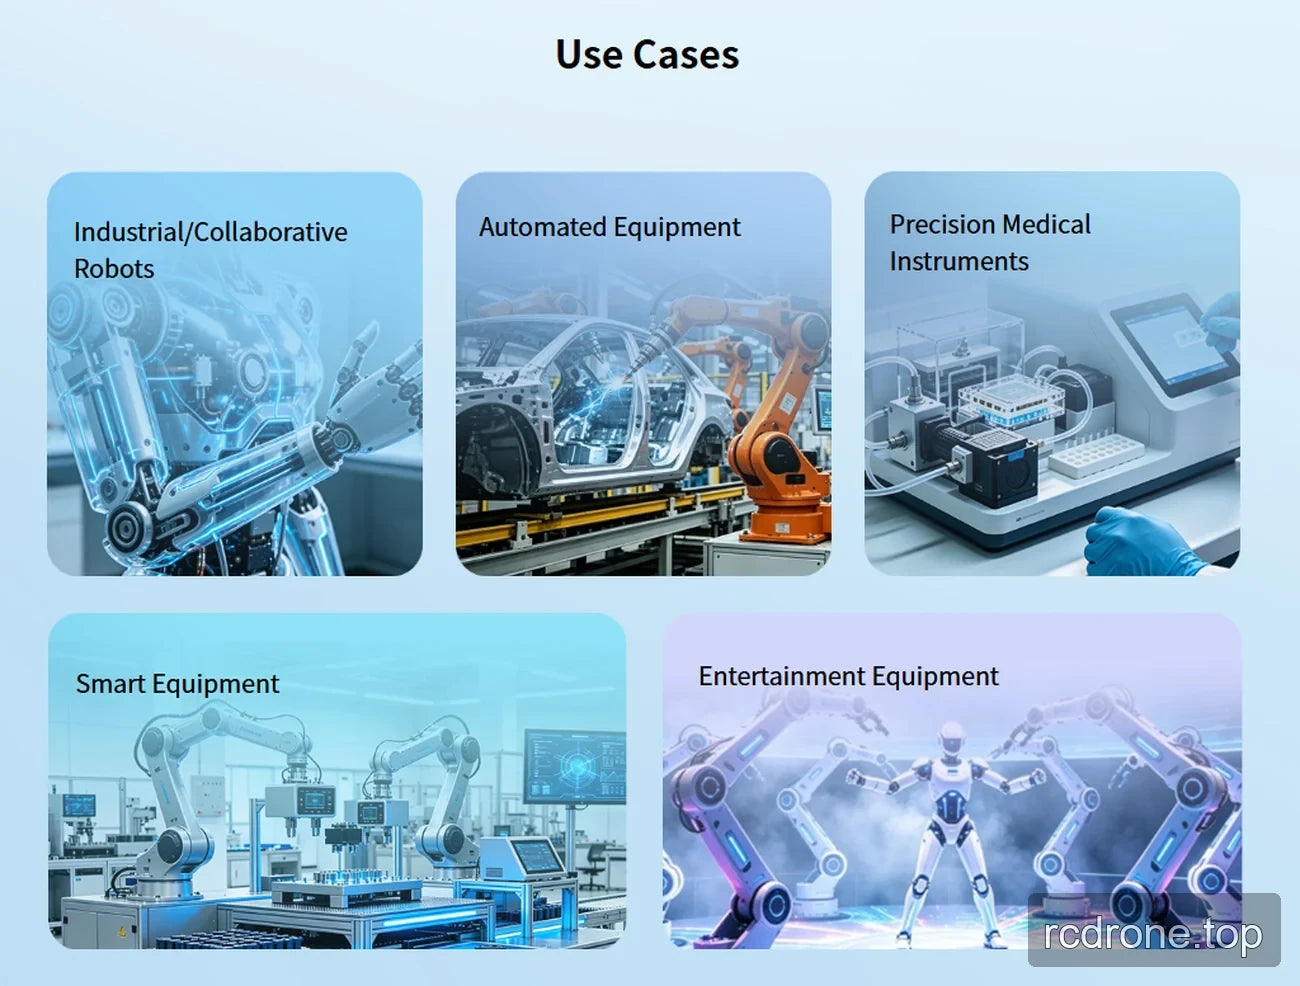
- Industrial and collaborative robots
- Automated equipment
- Precision medical instruments
- Smart equipment
- Entertainment equipment
Documentation
- EYOU CANable — User Manual (PDF)
- LinkDynamics HT52 Drawing — Drawing (PDF)
- EYOU UART Debug Module — User Manual (PDF)
Visual Details
Application Examples
Features and Design
Product Views
Specifications and Performance