


DAMIAO DM-2325 24 V, 380 rpm, 5 N·m Robot Motor with 1:25 Gear, CAN/FD CAN and Incremental Encoder
DAMIAO DM-2325 24 V, 380 rpm, 5 N·m Robot Motor with 1:25 Gear, CAN/FD CAN and Incremental Encoder
DAMIAO
Regular price
$45.00 USD
Regular price
Sale price
$45.00 USD
Unit price
per
Taxes included.
Shipping calculated at checkout.
Couldn't load pickup availability


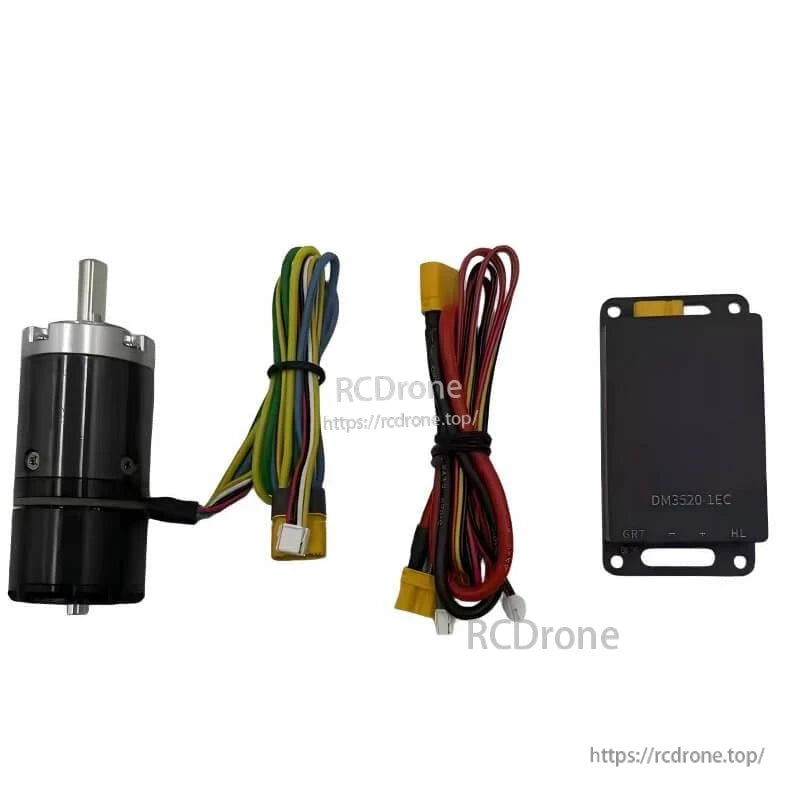
Overview
The DAMIAO DM-2325 is a compact Robot Motor designed for precise motion control in robotics. It features incremental encoder feedback, CAN/FD CAN control interfaces, and UART configuration. With a 1:25 reduction ratio, 24 V supply, and defined control modes, it suits applications requiring dependable speed and position regulation.
Key Features
- Model: DM-2325
- Nominal voltage: 24 V
- Nominal current: 5 A / 3.2 A; Peak current: 13 A / 7.5 A
- Nominal torque: 5 N·m; Peak torque: 2 N·m
- Nominal speed: 380 rpm; Max. no-load speed: 560 rpm
- Reduction ratio: 1:25; Pole pairs: 7
- Phase inductance: 75 μH; Phase resistance: 0.2915 Ω
- Maximum radial load: 395 N
- Dimensions: 28 mm outer diameter; 77.6 mm height
- Motor weight: 172.2 g
- Encoder type: Incremental encoder
- Control interface: CAN@1 Mbps (Max), FD CAN@5 Mbps (Max)
- Configuration interface: UART@921600 bps
- Control modes: MIT mode, Speed Mode, Position Mode
Specifications
| Model | DM-2325 |
| Nominal Voltage | 24 V |
| Nominal Current | 5 A / 3.2 A |
| Peak Current | 13 A / 7.5 A |
| Nominal Torque | 5 N·m |
| Peak Torque | 2 N·m |
| Nominal Speed | 380 rpm |
| Max. No-load Speed | 560 rpm |
| Reduction Ratio | 1:25 |
| Pole Pairs | 7 |
| Phase Inductance | 75 μH |
| Phase Resistance | 0.2915 Ω |
| Maximum Radial Load | 395 N |
| Outer Diameter | 28 mm |
| Height | 77.6 mm |
| Motor Weight | 172.2 g |
| Encoder Type | Incremental encoder |
| Control Interface | CAN@1 Mbps (Max), FD CAN@5 Mbps (Max) |
| Configuration Interface | UART@921600 bps |
| Control Modes | MIT mode; Speed Mode; Position Mode |
Protection
- Drive over-temperature protection; protection temperature: 120 °C. Over temperature exits the "enable mode".
- Motor over-temperature protection; set per use requirements (recommended not to exceed 100 °C). Over temperature exits the "enable mode".
- Motor over-voltage protection; set per use requirements (recommended not to exceed 60 V). Over voltage exits the "enable mode".
- Communication loss protection; if no CAN command is received within the set period, the system exits the "enable mode".
- Motor over-current protection; set per use requirements (recommended not to exceed 13 A). Over current exits the "enable mode".
- Motor under-voltage protection; if supply voltage is lower than the set value, exit the "enable mode" (power supply voltage not less than 15 V).
Applications
- Humanoid Robots
- Robotic Arms
- Exoskeletons
- Quadruped Robots
- AGV Vehicles
- ARU Robots
Manuals and Downloads
- DM_2325_Motor.stp
- DM_2325_Motor_armature.stp
- DM-2325_instalation_drawing.pdf
- DM-2325_armature_instalation_drawing.pdf
Installation Drawing
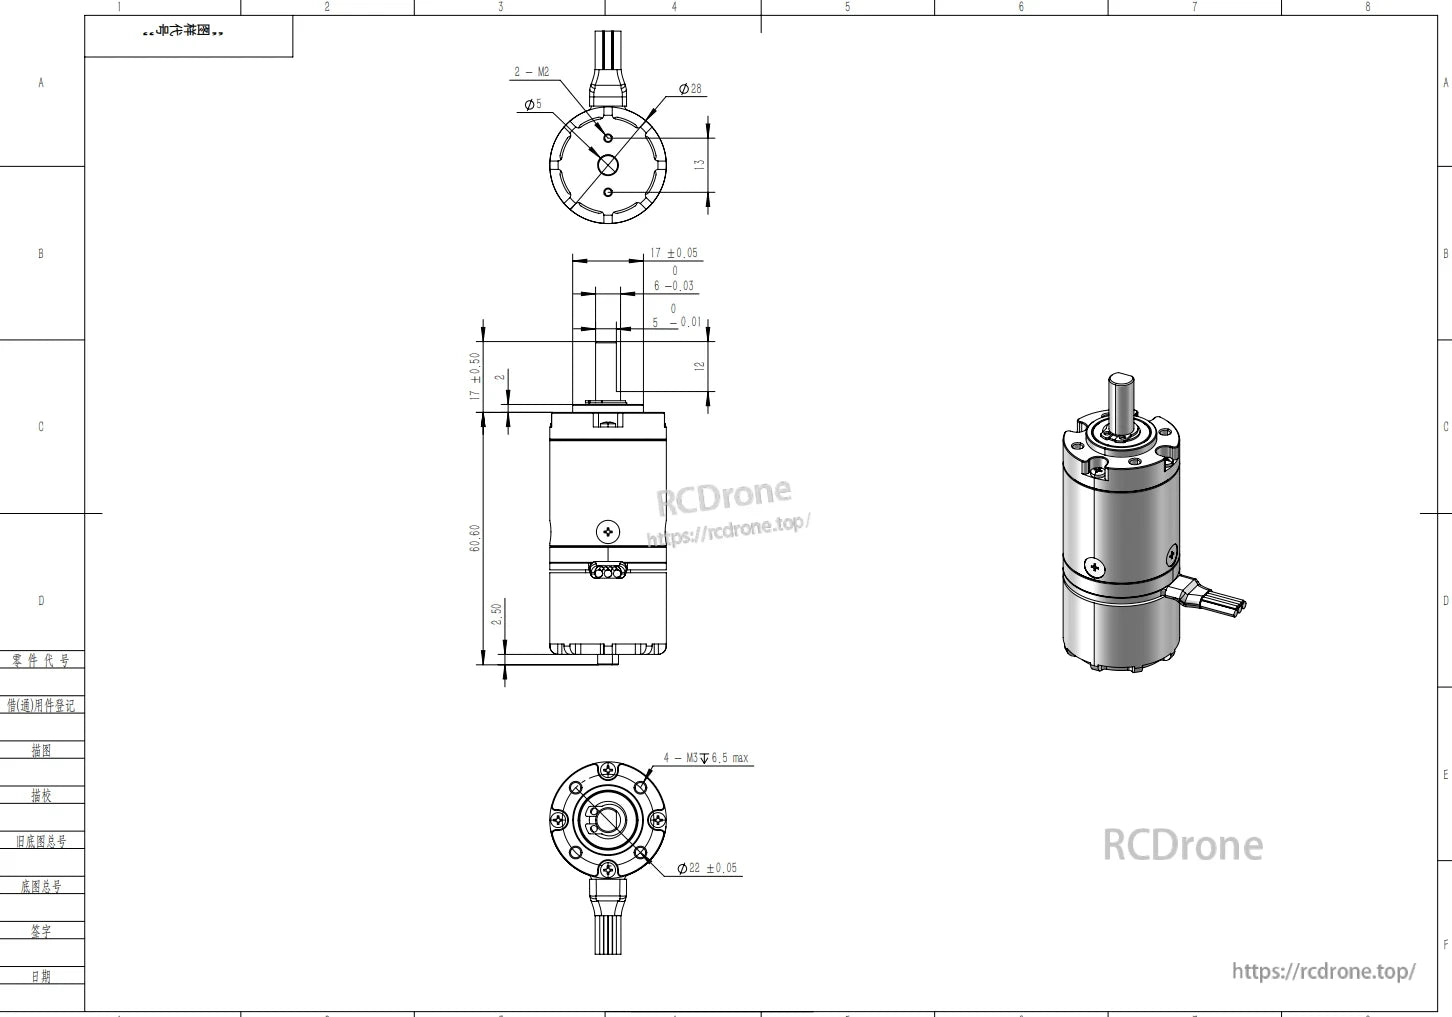
Robot motor technical drawing with dimensions and specifications

Details
Robot motor technical drawing with dimensions and specifications

Robot motor technical drawing with dimensions and 3D view