CHIHAI GM16-030ABHL DC Gear Motor with 7 PPR Hall Encoder, 6V/12V
CHIHAI GM16-030ABHL DC Gear Motor with 7 PPR Hall Encoder, 6V/12V
CHIHAI MOTOR
पिकअप उपलब्धता लोड नहीं की जा सकी


Overview
The CHIHAI MOTOR GM 16-030ABHL is a compact DC gear motor with a metal reduction gearbox and AB Hall feedback. Select the voltage, actual reduction ratio and motor-only or bracket package. Both packages include the encoder-equipped motor and pictured matching six-wire lead.
Features
- Metal reduction gears and copper-wound brushed motor.
- 3 mm D-shaped output shaft for a matching hub.
- Two-channel 7 PPR magnetic Hall feedback at the motor shaft.
- Separate motor-power and Hall-supply connections; optional L-shaped bracket.
Specifications
| Brand / model | CHIHAI MOTOR / GM 16-030ABHL; detail tables also identify CHR-GM 16-030PA ABHL |
| Motor construction | Brushed DC motor with metal gear reduction and two-channel magnetic Hall encoder |
| Selectable supply | 6 V or 12 V winding; 9 V table is a separate family reference, not a stocked option |
| Ratios | 10: 1, 20: 1, 35: 1, 63: 1, 86: 1, 115: 1, 150: 1, 250: 1, 360: 1 |
| Output shaft | 3 mm D-shaft, 2.5 mm across flat, 10±0.3 mm projection |
| Drawing reference | 36.0 mm motor/gearbox body; 18.6 mm can; 11±0.2 mm gearbox; 15.5±0.2 mm end reference |
| Mounting | Two M 2×0.4 threaded holes; 12 mm reference spacing; 9 mm reference offset |
| Rear encoder envelope | 21.0 mm reference; ZH 1.5 six-pin connector |
| Net mass reference | Approximately 28 g, ratio-dependent; shipping mass is separate |
| Mechanical load ceiling | 3.0 kgf·cm /0.3 N·m maximum gearbox load reference; not universal rated torque |
| Hall encoder | 7 PPR at motor shaft; 14 poles/7 pole pairs; AB square-wave outputs |
| Hall circuit | 3.3 V or 5 V separate supply; onboard pull-up/signal-shaping resistors |
| Connector / frequency | ZH 1.5-6PIN with matching lead; 100 kHz response reference |
| Output pulse reference | 7×reduction ratio before the receiver edge-counting multiplier |
Winding and Performance Reference
Use the table matching the winding. Rated torque uses g·cm; stall torque uses kg·cm. The 3.0 kgf·cm gearbox limit is a mechanical ceiling, not the rated torque of every ratio. Power figures retain their maximum/reference scope rather than implying mechanical output power for every load point.
12 V
1.5 W maximum-power reference; 18000 rpm motor winding. No-load current≤65 mA; rated current≤0.16 A; stall current≤0.75 A.
| Ratio | No-load rpm | Rated g·cm | Rated rpm | Stall kg·cm / ceiling | Output pulse reference |
|---|---|---|---|---|---|
| 10: 1 | 1750 | 50 | 1450 | ≥0.3 | 70 |
| 20: 1 | 880 | 100 | 730 | ≥0.6 | 140 |
| 35: 1 | 500 | 170 | 420 | ≥1.0 | 245 |
| 63: 1 | 280 | 300 | 230 | ≥2.0 | 441 |
| 86: 1 | 205 | 400 | 170 | ≥2.5 | 602 |
| 115: 1 | 155 | 550 | 125 | 3.0 gearbox ceiling; stall not individually specified | 805 |
| 150: 1 | 115 | 750 | 100 | 3.0 gearbox ceiling; stall not individually specified | 1050 |
| 250: 1 | 70 | 1250 | 58 | 3.0 gearbox ceiling; stall not individually specified | 1750 |
| 360: 1 | 50 | 1800 | 40 | 3.0 gearbox ceiling; stall not individually specified | 2520 |
6 V
0.7 W maximum-power reference; 9000 rpm motor winding. No-load current≤50 mA; rated current≤0.10 A; stall current≤0.38 A.
| Ratio | No-load rpm | Rated g·cm | Rated rpm | Stall kg·cm / ceiling | Output pulse reference |
|---|---|---|---|---|---|
| 10: 1 | 900 | 50 | 780 | ≥0.20 | 70 |
| 20: 1 | 450 | 100 | 385 | ≥0.45 | 140 |
| 35: 1 | 250 | 170 | 220 | ≥0.7 | 245 |
| 63: 1 | 140 | 300 | 120 | ≥1.5 | 441 |
| 86: 1 | 105 | 400 | 90 | ≥2.0 | 602 |
| 115: 1 | 80 | 550 | 68 | ≥2.3 | 805 |
| 150: 1 | 60 | 750 | 50 | 3.0 gearbox ceiling; stall not individually specified | 1050 |
| 250: 1 | 35 | 1250 | 30 | 3.0 gearbox ceiling; stall not individually specified | 1750 |
| 360: 1 | 25 | 1800 | 22 | 3.0 gearbox ceiling; stall not individually specified | 2520 |
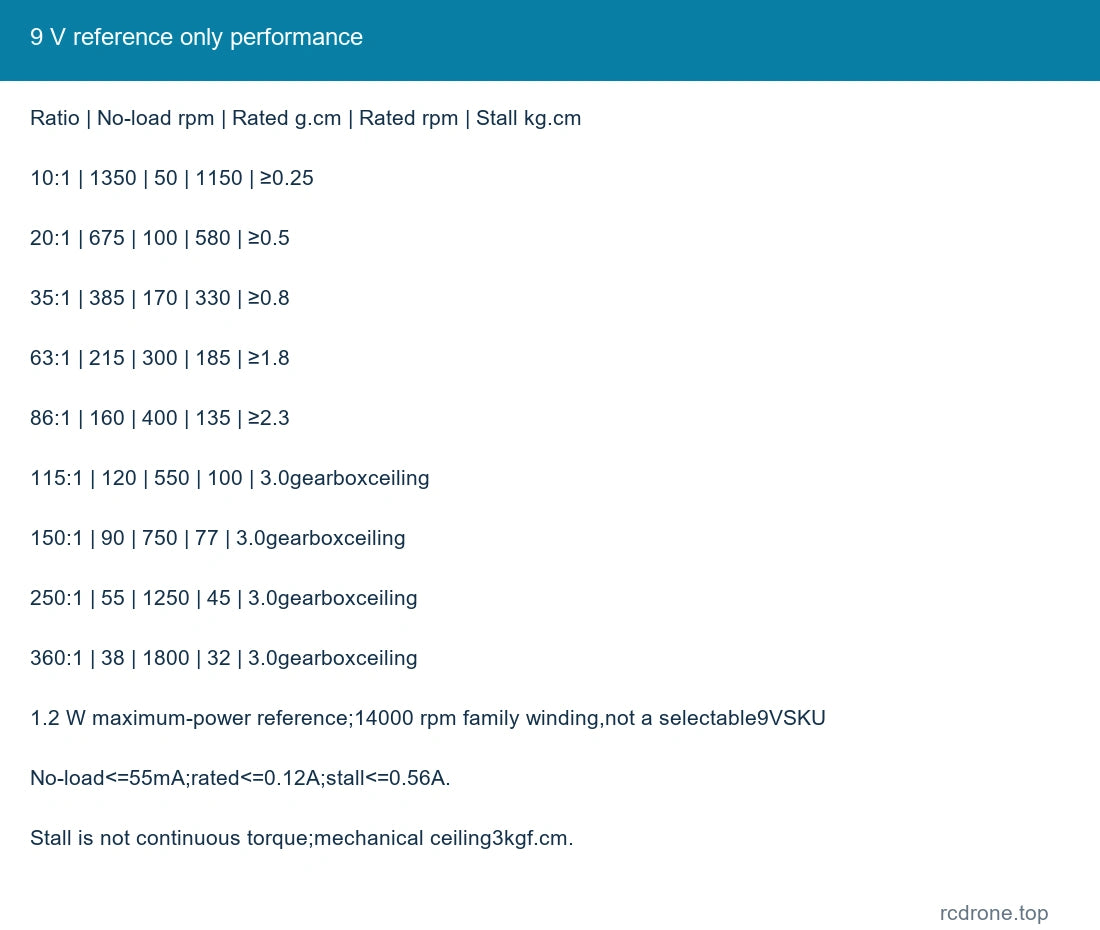
9 V reference only
1.2 W maximum-power reference; 14000 rpm family winding, not a selectable 9VSKU. No-load current≤55 mA; rated current≤0.12 A; stall current≤0.56 A.
| Ratio | No-load rpm | Rated g·cm | Rated rpm | Stall kg·cm / ceiling | Output pulse reference |
|---|---|---|---|---|---|
| 10: 1 | 1350 | 50 | 1150 | ≥0.25 | 70 |
| 20: 1 | 675 | 100 | 580 | ≥0.5 | 140 |
| 35: 1 | 385 | 170 | 330 | ≥0.8 | 245 |
| 63: 1 | 215 | 300 | 185 | ≥1.8 | 441 |
| 86: 1 | 160 | 400 | 135 | ≥2.3 | 602 |
| 115: 1 | 120 | 550 | 100 | 3.0 gearbox ceiling; stall not individually specified | 805 |
| 150: 1 | 90 | 750 | 77 | 3.0 gearbox ceiling; stall not individually specified | 1050 |
| 250: 1 | 55 | 1250 | 45 | 3.0 gearbox ceiling; stall not individually specified | 1750 |
| 360: 1 | 38 | 1800 | 32 | 3.0 gearbox ceiling; stall not individually specified | 2520 |
Encoder Connection
| Pin | Signal | Function |
|---|---|---|
| 1 | M 2 | Motor negative |
| 2 | VCC | Hall supply positive 3.3/5V |
| 3 | B / C 2 | Hall phaseB output |
| 4 | A / C 1 | Hall phaseA output |
| 5 | GND | Hall ground |
| 6 | M 1 | Motor positive |
The pin numbers follow the preserved connector orientation in the mechanical drawing. Verify the actual connector markings before connection. Never connect 6 V or 12 V motor power to the Hall VCC or A/B signals. Supply the Hall circuit at 3.3 V or 5 V and use compatible input logic. Incremental feedback measures relative movement and does not give absolute position at startup.
The base motor-shaft reference is 7 PPR; output-shaft reference is 7×ratio. Receiver x 1/x 2/x 4 edge counting can change the reported count. Reverse motor leads for direction while keeping Hall supply polarity correct.
Installation and Operation
Check shaft/hub fit, mounting screw depth, bracket clearance and encoder-board space before assembly. The L-bracket is included only in its named package. Select a driver and supply with adequate startup-current capacity and provide overcurrent protection. Avoid prolonged stall, shaft impacts, overload and abrupt reversing under load.
Applications
Compact robot drives, small automation mechanisms and speed or relative-rotation measurement projects. Match the chosen ratio, speed, torque, mounting and feedback interface to the mechanism.
What's Included
One selected Hall-encoder gear motor and matching six-wire lead. The bracket package additionally includes the pictured bracket and matching hardware. Controller, power supply, wheel, complete robot and additional loose internal gears are not included.
FAQ
Does every option include Hall feedback?
Yes. Both packages use the ABHL encoder-equipped motor.
Can I power Hall VCC from the motor supply?
No. Hall VCC requires a separate 3.3 V or 5 V supply.
Is 9 V selectable?
No. The 9 V performance table is family reference only; actual retail windings are 6 V and 12 V.
Does every ratio provide 3 kgf·cm rated torque?
No. Use its rated g·cm value; 3 kgf·cm is the gearbox mechanical ceiling.
Visual Details