


EYOU PHA17H-101-C Harmonic Drive Robot Joint Motor, 101 Reduction Ratio, CANopen Robotics
EYOU PHA17H-101-C Harmonic Drive Robot Joint Motor, 101 Reduction Ratio, CANopen Robotics
EYOU
नियमित रूप से मूल्य
$1,199.00 USD
नियमित रूप से मूल्य
विक्रय कीमत
$1,199.00 USD
यूनिट मूल्य
प्रति
Taxes included.
शिपिंग की गणना चेकआउट के समय की जाती है।
पिकअप उपलब्धता लोड नहीं की जा सकी


Overview
The EYOU PHA17H-101-C is a harmonic-reducer robot joint motor with an integrated driver, 101 reduction ratio, CANopen communication, and CANFD in/out interface. It operates from 24–48 VDC and is specified for robotics applications including humanoid robots, robotic arms, exoskeletons, quadruped robots, AGV vehicles, and ARU robots. Its output ratings, Φ80 × 68 mm form factor, and 10.8 mm hollow diameter support joint-level selection.
Features
- Built-in driver with power (DC in/DC out) and CANFD (in/out) interfaces.
- Dual absolute encoder: motor side 16Bit and reducer side 16Bit.
- CANopen communication protocol.
- Control modes: Profile Position (PP), Profile Velocity (PV), Profile Torque (PT), Cyclic Synchronous Position (CSP), Cyclic Synchronous Velocity (CSV), etc.
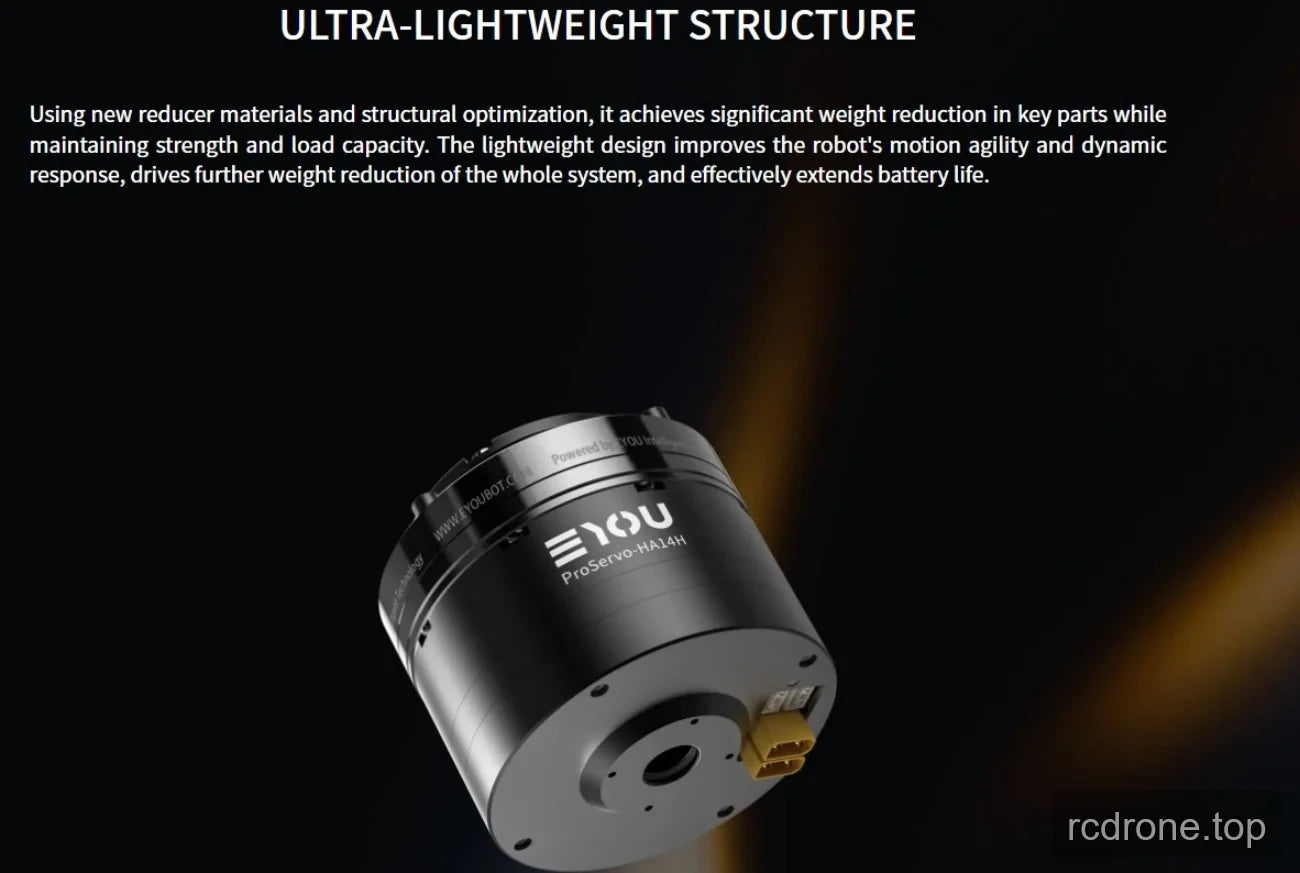
- Connector end includes two yellow connectors and two smaller white ports.
Specifications
| Parameter | Value |
|---|---|
| Module Model | PHA17 |
| Reducer Type | Harmonic |
| Motor Rated Power | 188 W |
| Motor Rated Torque | 0.45 N·m |
| Motor Peak Torque | 1.35 N·m |
| Reduction Ratio | 101 |
| Joint Rated Power - Life Constraint | 63 W |
| Rated Torque at 2000 rpm Input | 30 N·m |
| Average Load Torque at Output | 49 N·m |
| Peak Torque at Output | 66 N·m |
| Max Allowable External Torque at Output (Instantaneous) | 134 N·m |
| Backlash | ≤20 Arcsec |
| Rated Speed at Output - Life Constraint | 20 rpm |
| Peak Speed at Output | 33 rpm |
| Brake (B/N) | N |
| Dimensions (Outer Diameter × Axial) | Φ80 × 68 mm |
| Weight | 0.9 kg |
| Hollow Diameter | 10.8 mm |
| Housing Appearance (Process Color) | Matte Black Anodized |
| Reducer Appearance (Process Color) | Outer Ring Blackened |
| Radial (dynamic/static) Allowable Load at Output | 400 N |
| Axial (dynamic/static) Allowable Load at Output | 400 N |
| Output Bending Moment | 72 N·m |
| Reducer Torsional Stiffness | 13000 N·m/rad |
| Reducer Input Inertia | 49 kg·mm² |
| Equivalent Joint Output Inertia | 502909 kg·mm² |
| Rated Operating Voltage | 48 VDC |
| Operating Voltage Range | 24–48 VDC |
| Driver | Built-in |
| Encoder/Bit | Dual Absolute / Motor side 16Bit & Reducer side 16Bit |
| Driver Interface (see terminal model description) | Power (DC in DC out), CANFD (In,Out) |
| Communication Protocol (see communication description) | CANopen |
| Control Modes | Profile Position (PP), Profile Velocity (PV), Profile Torque (PT), Cyclic Synchronous Position (CSP), Cyclic Synchronous Velocity (CSV), etc. |
| Operating Ambient Temperature | -20–60 °C |
| Housing Temperature Rise | ≤60 °C |
| Noise | ≤60 dB |
| Life | >10000 h |
Applications
- Humanoid robots
- Robotic arms
- Exoskeletons
- Quadruped robots
- AGV vehicles
- ARU robots
Downloads
- EYOU CANable — User Manual (PDF)
- EYOU PHA17 — 3D Model (STP)
- EYOU PHA17H 101 C Drawing — Drawing (PDF)
- EYOU Robot Joint Catalog — Robot Joint Product Catalog (PDF)
- EYOU RP Series EN V1.0 20260608 — User Manual (PDF)
- EYOU UART Debug Module — User Manual (PDF)
Visual Details
Product Views

Features and Design



Additional Product Details


