CHIHAI CHP-42GP-775ABHL Planetary DC Gear Motor with 17PPR Hall Encoder
CHIHAI CHP-42GP-775ABHL Planetary DC Gear Motor with 17PPR Hall Encoder
CHIHAI MOTOR
受け取り可能状況を読み込めませんでした


Overview
The CHIHAI MOTOR CHP-42GP-775ABHL is a42 mm planetary DC gear motor with a17PPR AB Hall encoder,8 mm D-shaft and separate motor-power and encoder connections. Select12V or24V operation, the reduction ratio and a motor-only or mounting-bracket package.
Features
- Metal planetary gears with configuration-dependent one- to four-stage reduction.
- Copper motor winding and built-in cooling fan.
- Rear protective encoder cover with AB incremental feedback.
- Separate PH2.0 four-pin encoder and VH3.96 two-pin motor power connections.
Specifications
| Item | Specification |
|---|---|
| Model | CHP-42GP-775ABHL |
| Design | Permanent-magnet brushed DC motor with planetary reduction and AB Hall encoder |
| Motor voltage | Selected12V or24V DC |
| Gearbox | 42 +/-0.2 mm diameter;1-4planetary stages by ratio |
| Motor section | 66.5 +/-0.3 mm long;43.0 +/-0.3 mm diameter drawing reference |
| Rear encoder cover | 16 mm rear extension reference |
| Output shaft | 8 mm diameter+0/-0.03;22 +/-0.5 mm projection;12 mm flat length;7 mm flat dimension+0/-0.1 |
| Front mounting | Four M4 threads,5 mm depth, on35 mm pitch circle |
| Locating boss | 26 mm diameter+0/-0.05;2 mm extension reference |
| M4 maximum pretightening torque | 8 kgf·cm; mounting screw limit, not output torque |
| Gearbox length L | 33.5-63.5 mm, tolerance+/-0.5 mm according to ratio |
| Net mass reference | Approximately795 g; varies with ratio/configuration |
| Motor power connector | VH3.96-2PIN with matching connection lead |
| Encoder connector | PH2.0-4PIN with matching connection lead |
Encoder and Wiring
| Encoder parameter | Specification |
|---|---|
| Type | AB incremental magnetic Hall, square-wave outputs |
| Base pulse count | 17 PPR at motor shaft; output-shaft pulses scale with gear ratio |
| Supply | Separate regulated DC3.3V or5V |
| Signal conditioning | Onboard pull-up and shaping resistors for compatible microcontroller input |
| Response frequency | 100 kHz reference |
| Magnetic ring | 34 poles /17pole pairs |
| Harness | Wire color | Function |
|---|---|---|
| PH2.0 encoder harness | Red | GND - encoder supply negative |
| PH2.0 encoder harness | Black | C1 - channelA output |
| PH2.0 encoder harness | Yellow | C2 - channelB output |
| PH2.0 encoder harness | Green | VCC - regulated3.3V/5V positive |
| VH3.96 motor harness | Red | Motor positive at selected12V/24V |
| VH3.96 motor harness | Black | Motor negative; reverse motor power polarity to reverse rotation |
The red wire has a different role in the two harnesses: encoder red isGND, while motor red is positive motor power. Encoder green isVCC. Keep12V/24V motor power away from the3.3V/5V encoder supply and signal pins. Match connector orientation and labels before applying power.17PPR is the motor-shaft base resolution; multiply by the actual gear ratio for output-shaft pulse references and account separately for the decoder edge-counting method.
Ratio, Stages and Gearbox Length
| Reference ratio | Planetary stages | Gearbox L mm |
|---|---|---|
| 3.7:1 | 1 | 33.5 |
| 5:1 | 1 | 33.5 |
| 13:1 | 2 | 43.5 |
| 18:1 | 2 | 43.5 |
| 25:1 | 2 | 43.5 |
| 49:1 | 3 | 53.5 |
| 67:1 | 3 | 53.5 |
| 92:1 | 3 | 53.5 |
| 125:1 | 3 | 53.5 |
| 181:1 | 4 | 63.5 |
| 246:1 | 4 | 63.5 |
| 336:1 | 4 | 63.5 |
| 458:1 | 4 | 63.5 |
| 625:1 | 4 | 63.5 |
The18:1,125:1,181:1 and458:1 columns are family references, not selectable combinations here. Gearbox length excludes the output projection, motor section and rear encoder cover.
Motor Performance
Apply the table for the selected voltage and ratio. No-load, rated and stall conditions are separate. The kgf·cm and N·m values are independently rounded references. Avoid overload and sustained stall; torque is not a lifting-payload rating.
12V
Maximum power reference35 W; no-load current ≤500 mA; stall-current reference12 A.
| Ratio | No-load rpm | Rated kgf·cm | Rated N·m | Rated rpm | Rated current A max |
|---|---|---|---|---|---|
| 3.7:1 | 1100 | 5.5 | 0.53 | 550 | 6 |
| 5:1 | 820 | 7.5 | 0.73 | 410 | 6 |
| 13:1 | 315 | 20 | 2 | 150 | 6 |
| 18:1 | 228 | 20 | 2 | 140 | 4.5 |
| 25:1 | 165 | 20 | 2 | 110 | 4 |
| 49:1 | 83 | 30 | 3 | 60 | 3.5 |
| 67:1 | 60 | 30 | 3 | 50 | 2.8 |
| 92:1 | 45 | 40 | 4 | 37 | 2.5 |
| 125:1 | 32 | 40 | 4 | 27 | 2 |
| 181:1 | 22 | 50 | 5 | 19 | 2 |
| 246:1 | 16.5 | 70 | 7 | 15 | 2 |
| 336:1 | 12 | 70 | 7 | 11 | 2 |
| 458:1 | 9 | 70 | 7 | 8 | 2 |
| 625:1 | 6.5 | 70 | 7 | 5.8 | 1.5 |
24V
Maximum power reference150 W; no-load current ≤700 mA; stall-current reference24.5 A.
| Ratio | No-load rpm | Rated kgf·cm | Rated N·m | Rated rpm | Rated current A max |
|---|---|---|---|---|---|
| 3.7:1 | 2200 | 11 | 1.2 | 1100 | 13 |
| 5:1 | 1640 | 15 | 1.3 | 820 | 13 |
| 13:1 | 630 | 30 | 3 | 300 | 13 |
| 18:1 | 450 | 30 | 3 | 300 | 10 |
| 25:1 | 330 | 30 | 3 | 250 | 9 |
| 49:1 | 165 | 40 | 4 | 130 | 7 |
| 67:1 | 120 | 50 | 5 | 105 | 6 |
| 92:1 | 90 | 60 | 6 | 80 | 5 |
| 125:1 | 64 | 60 | 6 | 55 | 4 |
| 181:1 | 44 | 70 | 7 | 40 | 4 |
| 246:1 | 33 | 90 | 9 | 30 | 4 |
| 336:1 | 24 | 90 | 9 | 22 | 4 |
| 458:1 | 18 | 90 | 9 | 16 | 4 |
| 625:1 | 13 | 90 | 9 | 12 | 3 |
Power and Installation
Use a DC supply matched to the selected12V or24V motor and capable of the actual running and starting load. A10A-capable supply is a minimum selection reference, not sufficient for all configurations or stall: the24V table reaches13A rated current and24.5A stall current. For battery operation, use a suitable power-rated battery;25C is a discharge-rate reference whose available current also depends on battery capacity. Provide appropriate protection and wiring.
Fit the8 mm D-shaft and35 mm mounting pattern correctly. Four M4 threads have5 mm depth; do not exceed8 kgf·cm pretightening torque. This screw-tightening limit is separate from motor output torque. Use an appropriate external motor driver and decoder for the intended control system; the encoder alone does not provide a complete closed-loop controller.
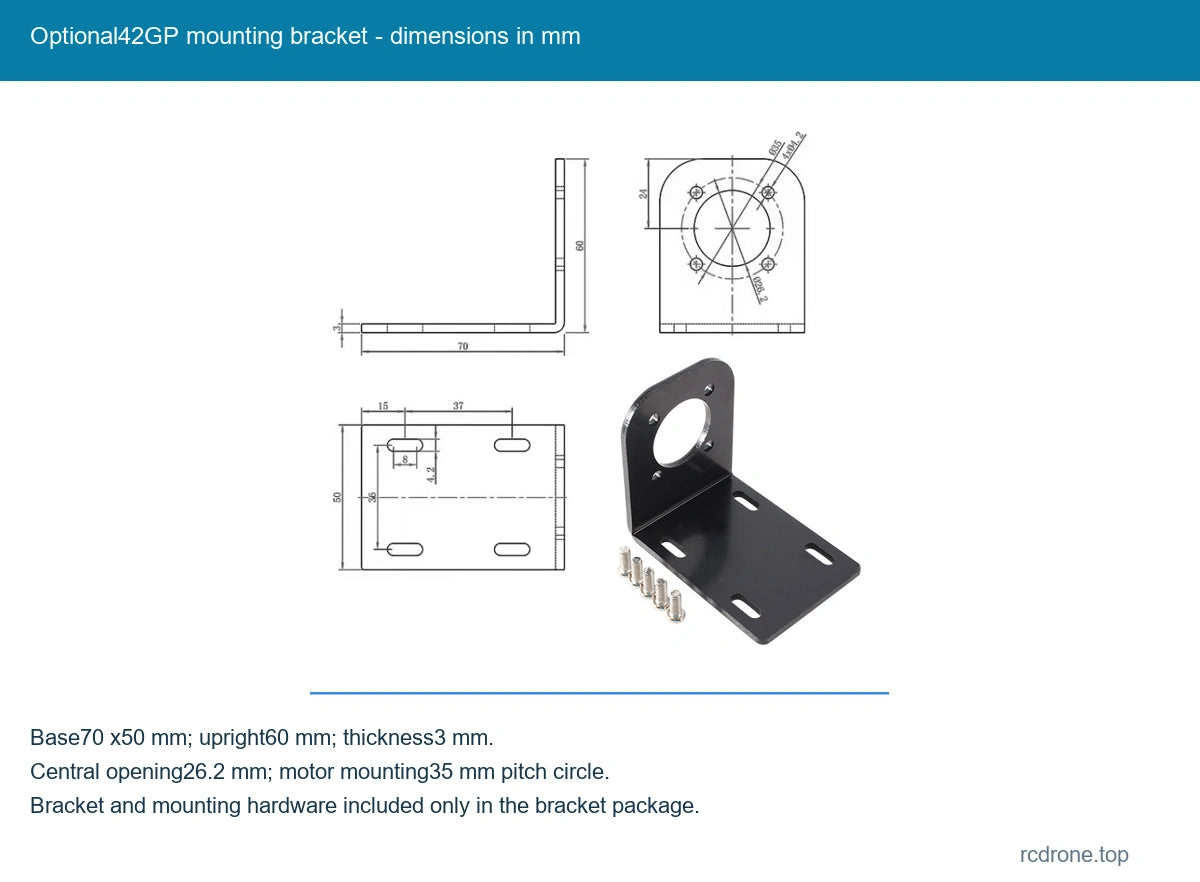
Optional Bracket Dimensions
The bracket reference has a70 x50 mm base,60 mm upright and3 mm material thickness. The central opening is26.2 mm, with mounting holes on35 mm pitch circle. Check the complete drawing before fabrication.
Applications
Suitable for matched robot drive mechanisms and powered positioning assemblies requiring high reduction and incremental rotation feedback. Select the operating point and support loads mechanically without forcing the output shaft.
What's Included
One selected CHP-42GP-775ABHL encoder motor, matching encoder lead and motor-power lead. The bracket package additionally includes the illustrated42GP bracket and mounting hardware. A power supply, motor driver, pulse decoder, controller, wheel or complete robot is not included.
FAQ
Can encoderVCC use the24V motor supply?
No. EncoderVCC requires regulated3.3V or5V, separate from12V/24V motor power.
Is17PPR the gearbox output resolution?
No. It is the motor-shaft base pulse count. Output references depend on the reduction ratio and decoder counting method.
Are the two red wires both positive?
No. Encoder-harness red isGND; motor-power-harness red is positive. Follow the harness-specific wiring table.
Visual Details