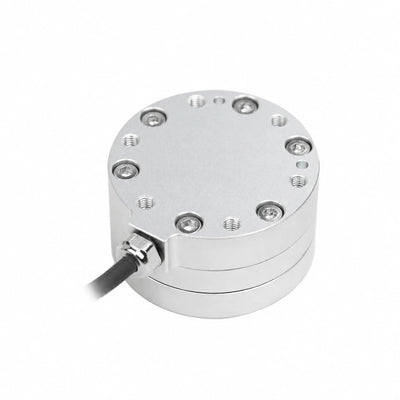
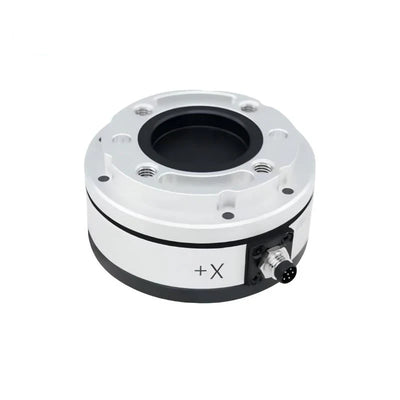
Kunwei KWR116 Six-Axis Force-Torque Sensor, 500–1400 N Options for Industrial Robotics
Kunwei KWR116 Six-Axis Force-Torque Sensor, 500–1400 N Options for Industrial Robotics
Kunwei Sensing
受け取り可能状況を読み込めませんでした


Overview
The Kunwei KWR116 series is a six-axis force-torque sensor for industrial robotic force and torque measurement. KWR116A, KWR116B and KWR116C provide respective force ranges of 500, 1000 and 1400 N, with torque ranges of 60, 100 and 120 N·m. All three versions share a 116 mm diameter, 26 mm height and built-in data acquisition with six-axis joint decoupling, allowing selection by measurement capacity within a common sensor size.
Features
- Six-degree-of-freedom measurement covering forces Fx, Fy and Fz and torques Mx, My and Mz.
- Built-in high-precision data acquisition module with a six-axis joint decoupling algorithm.
- Digital signal output and a series-level selection of communication interfaces.
- 1000 Hz sampling frequency, 0.03%FS resolution and 0.2%FS repeatability.
- Electropolished alloy-steel construction with IP64 protection.
Specifications
| Parameter | Unit | KWR116A | KWR116B | KWR116C |
|---|---|---|---|---|
| Range Fx, Fy | N | 500 | 1000 | 1400 |
| Range Fz | N | 500 | 1000 | 1400 |
| Range Mx, My | N·m | 60 | 100 | 120 |
| Range Mz | N·m | 60 | 100 | 120 |
| Diameter | mm | 116 | 116 | 116 |
| Height | mm | 26 | 26 | 26 |
| Material | — | Alloy steel | Alloy steel | Alloy steel |
| Surface treatment | — | Electropolishing | Electropolishing | Electropolishing |
| Resolution | %FS | 0.03 | 0.03 | 0.03 |
| Repeatability | %FS | 0.2 | 0.2 | 0.2 |
| Accuracy* | %FS | 0.5 | 0.5 | 0.5 |
| Weight | kg | 1.3 | 1.3 | 1.3 |
| Protection level | — | IP64 | IP64 | IP64 |
| Working temperature | °C | −10 to 80 | −10 to 80 | −10 to 80 |
| Sampling frequency | Hz | 1000 | 1000 | 1000 |
| Supply voltage | VDC | 12–48 | 12–48 | 12–48 |
| Signal type | — | Digital | ||
| Communication interfaces and protocols (series list) | — | RS422 / RS485 / MODBUS / CAN / CANFD / TCP / UDP / EtherCAT / USB, etc.; Industrial Ethernet | ||
FS = full scale.
Applications
- Robotic-arm force measurement: Measure forces along three axes and torques about three axes to assess loads during industrial robot tasks. Choose KWR116A, KWR116B or KWR116C according to the required force and torque ranges.
- Robot load and torque monitoring: Use the 1000 Hz sampling frequency to collect force-torque measurements over time during robot movements and contact tasks.
Documents
- KUNWEI KWR116 Drawing Series — Drawing (PDF)
- Kunwei KWR63 Series RS485 — User Manual (PDF)
- Kunwei KWR116 RS485 — User Manual (PDF)
- KUNWEI KWR75 RS422 — User Manual (PDF)
- KUNWEI 6 Axis Force Sensors Selection — Manual (PDF)
FAQ
How do the KWR116A, KWR116B and KWR116C differ?
KWR116A has a 500 N range on each force axis and a 60 N·m range on each torque axis. KWR116B increases these ranges to 1000 N and 100 N·m, while KWR116C provides 1400 N and 120 N·m. All three have the same listed 116 mm diameter and 26 mm height.
What power supply and sampling frequency does the sensor use?
All three versions use a 12–48 VDC supply and have a listed sampling frequency of 1000 Hz.
Visual Details
Specifications and Performance

Dimensions and Construction

Application Examples