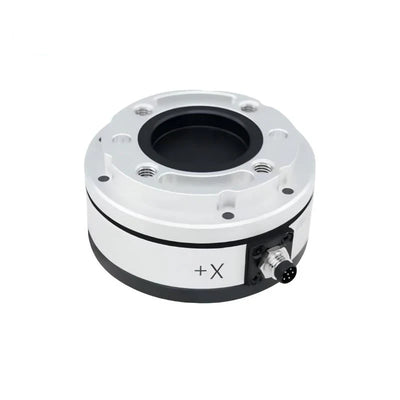
DECENT Y75D Six-Axis Force/Torque Sensor, RS485, 50–500 N
DECENT Y75D Six-Axis Force/Torque Sensor, RS485, 50–500 N
DECENT
Nie udało się wczytać dostępności odbioru


Overview
The DECENT Y75D six-axis force/torque sensor measures Fx, Fy and Fz forces together with Tx, Ty and Tz torques for robot assembly, surface finishing and force-feedback research. Its compact aluminum housing, decoupled sensing structure and RS485 communication suit integration between a robot flange and tooling. Choose a 50 N / 2 N·m, 200 N / 10 N·m or 500 N / 20 N·m sensor; acquisition electronics and the RS485 adapter cable are separate selections.
Features
- Six Cartesian force and torque channels for multi-directional load monitoring.
- Strain-gauge sensing with decoupled output and a high-strength aerospace-aluminum body.
- RS485 communication with Modbus RTU and a configurable active-send protocol.
- Selectable 40 or 640 samples/s measurement, with up to 640 outputs/s in active-send operation.
- 75 mm nominal flange diameter and a flexible 3 m sensor cable.
- IP65 sensor housing for appropriately installed equipment.
Specifications
| Sensor selection | Fx / Fy / Fz | Tx / Ty / Tz | Table model designation |
|---|---|---|---|
| 50 N / 2 N·m | 50 N each | 2 N·m each | E75-485-50NX6 |
| 200 N / 10 N·m | 200 N each | 10 N·m each | E75-485-200NX6 |
| 500 N / 20 N·m | 500 N each | 20 N·m each | E75-485-500NX6 |
| Sensing axes | Fx, Fy, Fz; Tx, Ty, Tz |
|---|---|
| Housing | High-strength aerospace aluminum alloy |
| Nominal body size | Ø75 × 30 mm, excluding bottom flange; use the dimension drawing for exact mounting and assembly clearances. |
| Ingress protection | IP65 |
| Overload capacity | 300% FS; avoid overloading or combined loads beyond the selected configuration. |
| Supply / consumption | 9–36 VDC; <1 W |
| Interface | RS485, 2400–460800 baud |
| Protocols | Modbus RTU and custom active-send protocol |
| Measurement rate | 40 or 640 samples/s; active-send output up to 640/s |
| Cable length | 3 m |
| Resolution | 20-bit; 1,000,000 divisions |
| Nonlinearity | Better than 0.2% FS |
| Accuracy | Better than 0.3% FS |
| Repeatability | Better than 0.2% FS |
| Coupling error | Better than 2% FS |
| Zero temperature drift | 0.2% FS / 10 °C |
| Zero drift | 0.1% FS / 30 min |
| Storage temperature | −25 to +70 °C |
| Operating environment | 0 to +40 °C; 20–80% RH |
FS means full scale. These specifications apply to sensor selections. Force and torque ratings describe sensing capacity, not shipping weight. The drawing identifies a 31.5 mm body section and 40.5 mm overall assembly; use its hole pattern, threads and tolerances when designing fixtures.
Configuration Guide
- Sensor selections: choose the force/torque range appropriate to your loads and tooling.
- Embedded acquisition system only: acquisition electronics without a sensor; match its inputs, power and output interface to the intended system before installation.
- RS485 signal adapter cable only: the selected cable accessory without a sensor or acquisition unit.
The embedded acquisition option is separate from the sensor's listed RS485 functionality. Other communication interfaces shown in family illustrations do not mean every interface is supplied with each sensor.
Applications
- Robot assembly and contact-force monitoring.
- Controlled sanding, polishing and surface finishing.
- Drag teaching and force-feedback research.
- Humanoid wrist or foot force sensing with suitable mechanical adapters.
- Materials and multi-axis load testing within the selected range.
Installation and Wiring
Fasten the base side securely and attach the tool to the designated tool flange. Align the coordinate frame with your controller, account for tooling mass and orientation, and perform zeroing and load compensation after installation. Robot and flange illustrations show integration examples; verify the bolt pattern, clearances and compatible adapters for your installation.
| Wire | Connection |
|---|---|
| Red | +24 V power in the illustrated wiring arrangement |
| Black | GND |
| Green | RS485-A |
| White | RS485-B |
| Shield | PE |
Keep more than 25 mm of straight cable at the outlet, a static bend radius greater than 42 mm and a dynamic bend radius greater than 84 mm. The routing illustration identifies an 8.4 mm cable outside diameter. Secure the cable, provide movement slack and avoid twisting or repeated sharp bends. Configuration software illustrations show data monitoring and communication setup.
What's Included
- Sensor option: 1 × six-axis force/torque sensor in the selected range with its attached 3 m cable.
- Embedded acquisition system only: 1 × acquisition system; sensor not included.
- RS485 signal adapter cable only: 1 × adapter cable; sensor and acquisition unit not included.
Robot arms, grippers, application equipment and custom adapter flanges are not included. Packaging and integration images are illustrative; only the selected configuration is supplied.
Visual Details