


Hangkai HKVR-TG9811 / TG9812 Brushless Tactile Electric Gripper, 98mm
Hangkai HKVR-TG9811 / TG9812 Brushless Tactile Electric Gripper, 98mm
Hangkai Microelectronic
Nie udało się wczytać dostępności odbioru


The Hangkai Microelectronic HKVR-TG9811 / TG9812 is a tactile electric gripper series for robotic handling. The source presents the TG9811 as a brushless-motor upgrade with a 98mm opening, integrated tactile feedback and a compact two-finger mechanism. Choose the tactile-finger configuration and communication interface through the sales option.
Choose a Gripper Configuration
| Model | Interface in source option | Tactile fingers |
|---|---|---|
| TG9811-485 | RS485 | Single-sided fingertip tactile sensing |
| TG9811-CAN | CAN | Single-sided fingertip tactile sensing |
| TG9812-485 | RS485 | Dual-sided fingertip tactile sensing |
| TG9812-CAN | CAN | Dual-sided fingertip tactile sensing |
The source reuses some family photographs with different drive housings across its options and demonstrations. Their original option-to-image associations are retained. Use the option label for interface and tactile-finger count, and verify the delivered model-specific housing, pinout and mechanical drawing for your integration. The TG9811 figures below are not silently extended to every TG9812 configuration.
Brushless Drive and Tactile Control
Supplier materials describe a brushless drive designed for reduced wear, quieter operation, smoother motion and reduced routine maintenance compared with the illustrated classic servo version. These are supplier comparisons, without a quantified life, sound-level or comparative endurance test in the saved material. The classic servo comparison is a reference illustration rather than an additional sales configuration.
Integrated three-axis fingertip tactile sensing supports contact feedback. In the supplier-described stable-grasp mode, an adaptive force-control algorithm adjusts the grip for different materials and shapes. A pass-through mode provides raw tactile signals for custom control and application-specific tuning. The claim of no manual programming refers to the built-in grasping behavior; robot communication, safety and integration still require appropriate setup.
TG9811 Source Figures
| Jaw opening / stroke shown | 98mm |
|---|---|
| Supplier-rated payload | 1.5kg; depends on object, friction, grip and motion |
| Single-finger gripping force | 0.02–36N, as stated in TG9811 promotional artwork |
| Overall width in drawing | 160mm |
| Overall height in drawing | 150mm |
| Body width in side view | 67mm |
| Additional drawing annotations | 17mm, 40mm and 37mm in the indicated views; Ø19 feature, Ø40 mounting pattern and 4-M2 callout |
Use the dimensioned drawing for the location and meaning of each annotation. Payload is not the gripper mass and is not a guaranteed safe operating load for every grasp. The saved TG9811 material does not provide a reliable assembled mass, supply-voltage specification, IP rating or full bus protocol; confirm these on the delivered documentation rather than substituting figures from the older TG9801 model.
PC Control, Simulation and Vision Integration
The supplier describes PC software, real-time tactile/force feedback and a MuJoCo model for simulation. Its status demonstration labels red as standby, yellow as object detected, green as stable grasp and blue as running. Claims of millisecond-level response are unverified source statements and depend on the complete control system.
Side mounting points and reserved camera mounting holes support integration planning. Supplier examples mention DOBOT, FAIRINO, SIASUN, JAKA, RealMan, AUBO and AgileX arms. These examples do not establish universal flange, electrical or software compatibility. Check the actual arm interface and obtain the correct model files and mounting hardware.
Accessory Options: Sold Separately
- RS485-to-USB or CAN-to-USB: one PC communication adapter only; no gripper.
- FAIRINO, AgileX or DOBOT cable: one arm-specific connection cable only. Robot arms, force sensors and grippers pictured in application images are not included.
- 1m cable extension: extension accessory only. The source option mentions a standard 50cm cable; confirm the delivered connector and extension arrangement.
- Intel RealSense D405 + bracket: one source-listed camera and mounting bracket configuration, without a gripper. The source quotes 42 × 42 × 23mm and 60g for the camera body; bracket mass is separate.
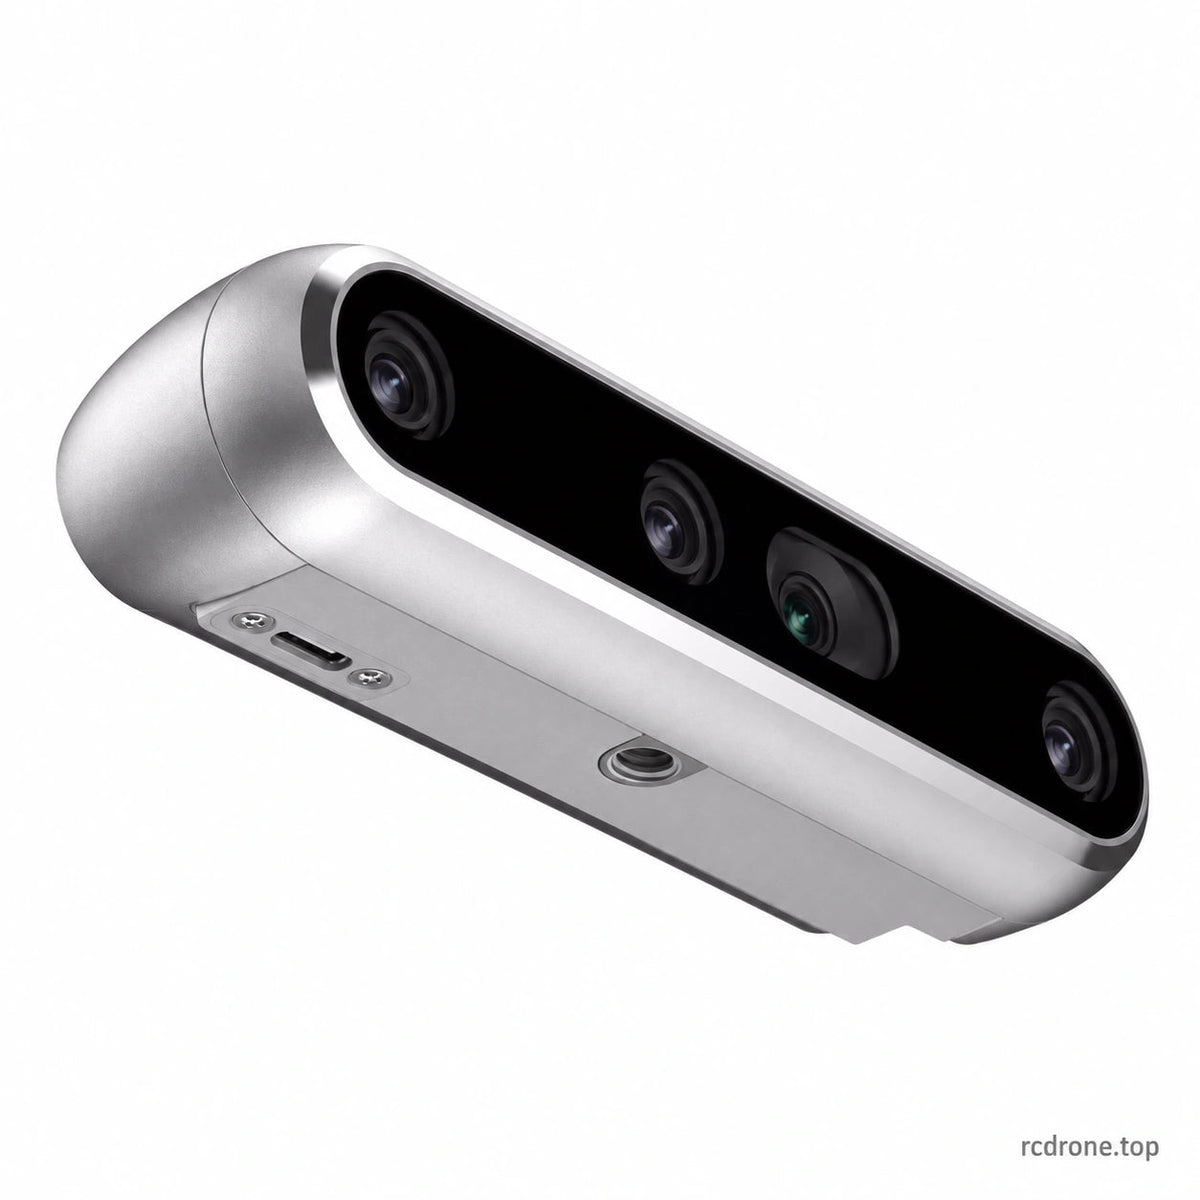
- Intel RealSense D435i + bracket: one source-listed camera and mounting bracket configuration, without a gripper.
Camera photographs may show the camera alone; the bracket is identified by the option label. Select a gripper option to buy a gripper. The robot demonstration scenes illustrate applications and do not turn a cable or camera option into a complete robot kit.
Visual Details


