


EYOU RP50H Planetary Robot Joint Actuator, 10 N·m Rated Torque, for Robotics
EYOU RP50H Planetary Robot Joint Actuator, 10 N·m Rated Torque, for Robotics
EYOU
Couldn't load pickup availability


Overview
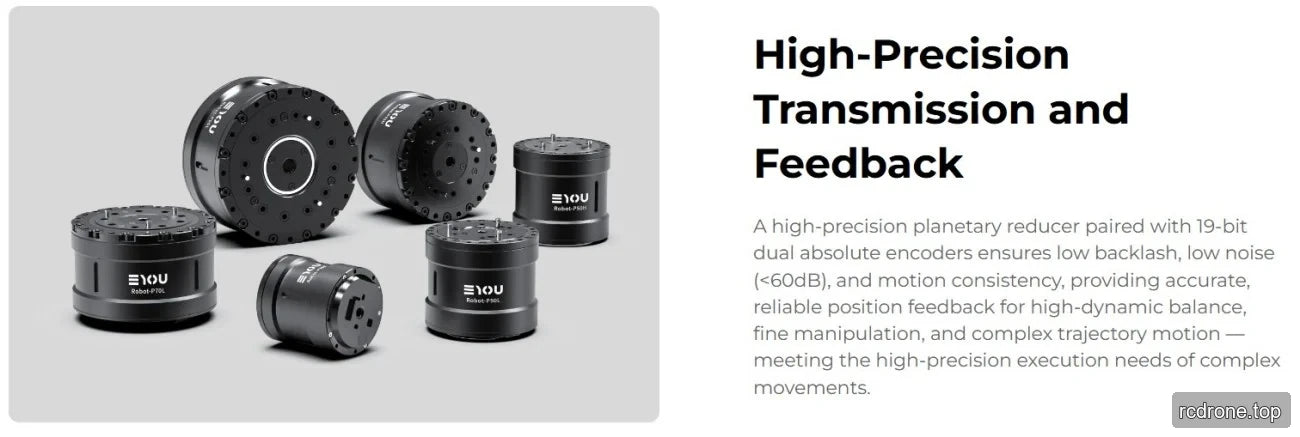
EYOU RP50H is a planetary robot joint module for humanoid robots, robotic arms, exoskeletons, quadruped robots, AGV vehicles, and ARU robots. It combines a 19.5278 reduction ratio with 10 N·m rated and 30 N·m peak torque, an integrated FOC drive, dual absolute encoders, and CANOpen communication. Select it for 48 VDC robotic joints requiring current, speed, position, or MIT control.
Features
- Planet reducer with a 19.5278 reduction ratio.
- Built-in FOC drive and dual absolute encoder arrangement: 17-bit input and 19-bit output.
- Crossed roller bearing, 5 mm hollow diameter, and regular matte-black shell appearance.
- Power pass-through (DC in/DC out) and CAN FD in/out drive interfaces.
- Control modes: current, speed, position, and MIT mode.
Specifications
| Parameter | Value |
|---|---|
| Module Model | RP50H |
| Reducer Mode | Planet |
| Motor rated power (W) | 184 |
| Reduction ratio | 19.5278 |
| Rated Torque (N·m) | 10 |
| Peak Torque (N·m) | 30 |
| Joint Rated Power (W) | 157 |
| Backlash (arcmin) | ≤12 |
| Rated speed of output end (rpm) | 150 |
| Output peak speed (rpm) | 180 |
| Dimensions (Outer Diameter × Axial) (mm) | Φ59 × 59.5 |
| Weight (g) (excluding wire) | 465 |
| Joint rated efficiency | 78% |
| Hollow Diameter (mm) | 5 |
| Shell Appearance (Process Color) | Regular Matte Black |
| Moment of inertia (kg·m²) | 28.66 |
| Bearing Type | Crossed Roller Bearing |
| Radial (dynamic/static) allowable load (N) at the output end | 2140/2740 |
| Axial (dynamic/static) allowable load (N) at the output end | 5100/18700 |
| Output Shaft Bending Moment (N·m) | 22.8 |
| Operating Voltage (VDC) | 48 ±10% |
| Maximum withstand voltage (VDC) | 90 |
| Bus Current (Arms) | 4.5 |
| Drive | Built-in FOC |
| Encoder/Bit (bit) | Dual Absolute / 17 (input), 19 (output) |
| Power cord length | ≥35 cm |
| Drive Interface | Power (DC in/DC out), CAN FD (in/out) |
| Communication Protocol | CANOpen / CANFD (custom development required) |
| Control Mode | Current, Speed, Position, MIT Mode |
| Working environment temperature (°C) | -10 to 45 |
| Enclosure operating temperature rise (°C) | ≤60 |
| Noise (dB) @ 1 m | ≤60 |
| IP Rating | IP54 |
| Life (h) | >3000 |
Applications
- Humanoid robots
- Robotic arms
- Exoskeletons
- Quadruped robots
- AGV vehicles
- ARU robots
Documentation
EYOU CANable — User Manual (PDF)
EYOU RP50H Drawing — Drawing (PDF)
EYOU RP Series EN V1.0 20260608 — User Manual (PDF)
EYOU RP Series — Specifications (PDF)
EYOU CANable — User Manual (PDF)
EYOU Robot Joint Catalog — Robot Joint Product Catalog (PDF)
EYOU RP Series EN V1.0 20260608 — User Manual (PDF)
EYOU UART Debug Module — User Manual (PDF)
Visual Details
Product Views

Application Examples

Features and Design


Interfaces and Connections

Additional Product Details


