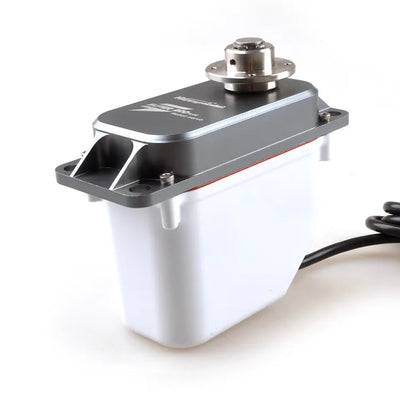
Kpower RC40R Dual-Output Robot Servo Motor with RS485, PWM & TTL for Robotic Arms
Kpower RC40R Dual-Output Robot Servo Motor with RS485, PWM & TTL for Robotic Arms
Kpower
নিয়মিত দাম
$247.00 USD
নিয়মিত দাম
বিক্রয় মূল্য
$247.00 USD
ইউনিট মূল্য
প্রতি
ট্যাক্স অন্তর্ভুক্ত.
শিপিং চেকআউটের সময় গণনা করা হবে।
পিকআপের উপলভ্যতা লোড করা যায়নি


Overview
The Kpower RC40R is a dual-output robot servo motor for robotic arms and other positioning mechanisms, including camera gimbals. It combines a coreless motor, metal gearing and magnetic position sensing with servo and continuous-rotation wheel modes. PWM, TTL and RS485 control support different integration approaches, while position, speed, current, load, voltage and temperature feedback help monitor operation. The specified stall torque is 4.5 N·m.
Features
- Dual output shafts for mechanical integration into robot mechanisms.
- Coreless motor with wear-resistant, titanium-coated 7075 aluminium gears.
- CNC aluminium alloy case with wire-concealing slots and versatile connection arrangements.
- Magnetic encoder with 0.35° resolution and a specified operating angle of 0–360°.
- Servo mode for positioning and wheel mode for endless rotation.
- PWM, TTL and RS485 control support; RS485 communication supports baud rates up to 115200.
- Feedback includes position, speed, current, load, input voltage and temperature.
- User-adjustable baud rate and device ID.
Specifications
| Parameter | RC40R specification |
|---|---|
| Dimensions | 45 × 32 × 35 mm |
| Weight | 68 g |
| Voltage range | DC 9.0–14.8 V |
| Rated voltage | 12 V |
| Stall torque | 4.5 N·m (46 kg·cm) |
| No-load speed | 47.2 rpm (0.21 s/60°) |
| Motor type | Coreless |
| Resolution | 0.35° |
| Operating angle | 0–360° |
| Operating modes | Servo / wheel mode (endless rotation) |
| Control interfaces | PWM, TTL and RS485 |
| RS485 baud rate | Up to 115200 baud; user-adjustable |
| Connection | 4-pin |
| Output shaft | 8 mm, 35T; dual-output design |
| Feedback | Position, speed, current, load, input voltage and temperature |
| Position sensor | Magnetic encoder |
| Device ID | 0–254; user-adjustable |
| Case | CNC aluminium alloy |
| Gears | 7075 aluminium coated with titanium; wear-resistant metal gearing |
| Connection and cable features | Versatile connection arrangements with wire-concealing slots |
Applications
- Robotic-arm joint positioning: Dual outputs support mechanical integration, while magnetic position sensing and operating feedback support controlled joint movement and monitoring.
- Camera-gimbal positioning: Servo mode and position feedback support controlled angular adjustment.
- Robot wheel mechanisms: Wheel mode provides endless rotation for mechanisms requiring continuous movement rather than a fixed angular position.
- Positioning mechanisms in medical equipment: Position, speed, current, voltage and temperature feedback support monitoring of motor-driven adjustments.
Documents and Downloads
- Kpower RC40R Drawing — Drawing (PDF)
- Kpower RC03T Drawing — 03 T Drawing (PDF)
- Kpower Servo 3 — Manual (PDF)
- OCServo OCS D9501 Manuel — Ocservo Ocs D 9501 Manuel (PDF)
- OCServo OCS 351CAN Drawing — Ocservo Ocs 351 Can Drawing (PDF)
Visual Details
Features and Design


Additional Product Details


Interfaces and Connections

Application Examples