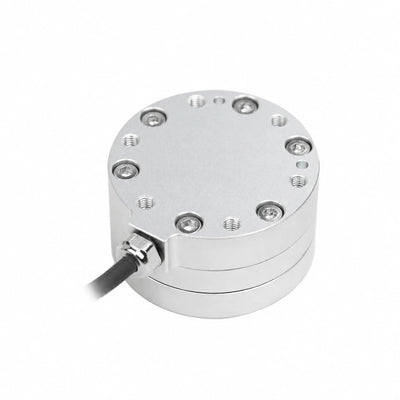
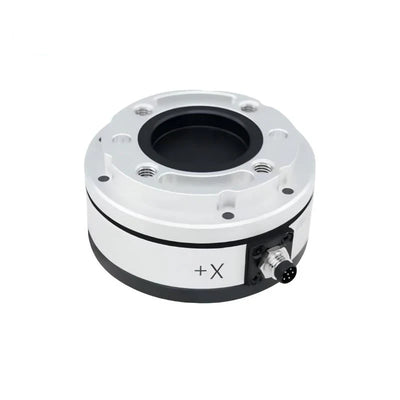
Kunwei Sensing KWR168 Six-Axis Force/Torque Sensor, 168 mm, for Industrial Robot Arms
Kunwei Sensing KWR168 Six-Axis Force/Torque Sensor, 168 mm, for Industrial Robot Arms
Kunwei Sensing
পিকআপের উপলভ্যতা লোড করা যায়নি

Overview
The Kunwei Sensing KWR168 series is a six-axis force/torque sensor for installation at the end of industrial robot arms. Its 168 mm diameter and 38 mm height help define the mounting envelope, while digital output supports measurement-system integration. Four versions—KWR168B, KWR168C, KWR168D and KWR168E—provide different force and torque ranges, allowing selection according to the loads being measured.
Features
- Measures force along Fx, Fy and Fz and torque about Mx, My and Mz.
- Four selectable versions with force ranges from 3000 N to 8000 N per axis; torque ranges vary by version and axis.
- Alloy-steel construction with an electropolished surface.
- Digital signal output and a 1000 Hz sampling frequency.
- IP65 protection and a working temperature range of 0–80 °C.
- 12–48 V DC supply voltage.
Specifications
Version-Specific Parameters
| Parameter | Unit | KWR168B | KWR168C | KWR168D | KWR168E |
|---|---|---|---|---|---|
| Fx, Fy force range | N | 3000 | 4000 | 6000 | 8000 |
| Fz force range | N | 3000 | 4000 | 6000 | 8000 |
| Mx, My torque range | N·m | 400 | 600 | 800 | 1200 |
| Mz torque range | N·m | 400 | 600 | 800 | 2000 |
| Resolution | % FS | 0.05 | 0.05 | 0.05 | 0.05 |
| Repeatability | % FS | 0.5 | 0.5 | 0.5 | 0.5 |
| Accuracy | % FS | 3 | 3 | 3 | 3 |
| Weight | kg | 2.8 | 2.8 | 2.8 | 4.5 |
Shared Series Parameters
| Parameter | Value |
|---|---|
| Measurement axes | Six: Fx, Fy, Fz, Mx, My and Mz |
| Diameter | 168 mm |
| Height | 38 mm |
| Material | Alloy steel |
| Surface treatment | Electropolishing |
| Overload rating | 200% FS |
| Precision | 0.5% FS |
| Protection level | IP65 |
| Working temperature | 0–80 °C |
| Sampling frequency | 1000 Hz |
| Supply voltage | 12–48 V DC |
| Signal output | Digital |
| Communication protocols/interfaces listed for the series | RS422 / RS485 / Modbus / TCP / UDP / EtherCAT / USB / etc. |
FS means full scale. The communication list describes series-level interfaces, not a separate interface selection for each version.
Applications
- Robot-arm end-effector force monitoring: Measure loads in three directions during tool-to-workpiece contact, using the version whose force range suits the task.
- Robot-arm tool torque monitoring: Measure moments about three axes to assess twisting and bending loads at the arm end. KWR168E provides 1200 N·m ranges for Mx and My and a separate 2000 N·m range for Mz.
Documents and Downloads
- KUNWEI KWR168 Drawing Series — Drawing (PDF)
- KUNWEI KWR116 Drawing — 116 Drawing (PDF)
- Kunwei KWR63 Series RS485 — User Manual (PDF)
- KUNWEI 6 Axis Force Sensors Selection — Manual (PDF)
- KUNWEI KWR75 RS422 — User Manual (PDF)
FAQ
How do the KWR168 versions differ?
KWR168B, C, D and E provide force ranges of 3000, 4000, 6000 and 8000 N respectively on each force axis. Their torque ranges are listed by axis in the version-specific table. B, C and D weigh 2.8 kg each; E weighs 4.5 kg.
What power supply and sampling frequency does the sensor use?
The series uses a 12–48 V DC supply and lists a sampling frequency of 1000 Hz.
What are the overall dimensions?
The shared series specifications list a diameter of 168 mm and a height of 38 mm.
Visual Details
Specifications and Performance

Dimensions and Construction

Application Examples