Hiwonder NexArm LeRobot 6-Axis Robot Arm — Leader, Follower & Imitation Learning Kits
Hiwonder NexArm LeRobot 6-Axis Robot Arm — Leader, Follower & Imitation Learning Kits
Hiwonder
পিকআপের উপলভ্যতা লোড করা যায়নি


Overview
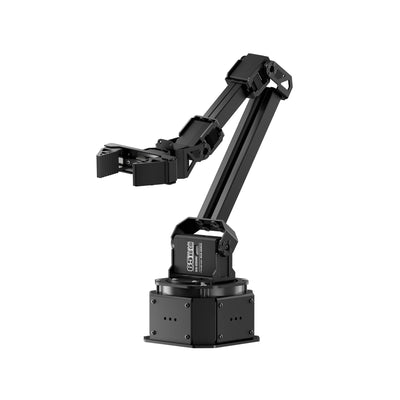
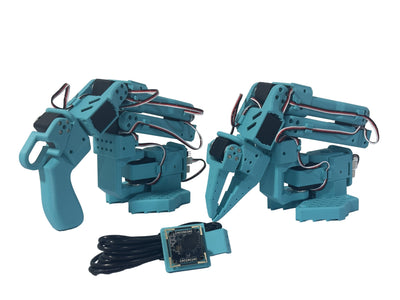
The Hiwonder NexArm LeRobot is a six-axis open-source robotic arm platform for teleoperation, imitation learning and embodied AI development. Metal construction, magnetic-encoder bus servos and inverse-kinematics control provide a practical platform for collecting demonstrations and testing robot policies. Choose a single Follower or Leader arm, or a paired Standard or Advanced kit. Advanced adds a second camera and metal mount for dual-view data collection.
Choose Your Configuration
Configuration Guide
| Follower Arm | One assembled powered follower arm; no leader or camera kit |
|---|---|
| Leader Arm | One assembled teaching arm; no follower or camera kit |
| Imitation Learning Standard Kit | One follower, one leader, first-person 0.3MP camera and bracket, plus kit accessories |
| Imitation Learning Advanced Kit | Standard paired-arm equipment plus 2MP third-person camera, bracket and all-metal camera mount |
Leader-follower teleoperation and imitation-learning demonstrations require both arms. A single-arm selection does not include the other arm. A computer or external compute platform is required for the relevant training and policy workloads and is not included.
Features
- Metal frame, all-metal servo gears, dual-output-shaft magnetic encoder bus joints and concealed wiring for desktop robotics development.
- Follower gripper uses parallel rails, silicone contact pads and stainless-steel transmission parts.
- Leader 1:147 and follower 1:345 reduction ratios support hand-guided demonstrations and stable follower motion respectively.
- Trapezoidal acceleration/deceleration, continuous interpolation and inverse kinematics reduce start-stop vibration and coordinate multi-axis movement.
- 12-bit non-contact magnetic angle feedback with servo readback of temperature, voltage and position.
- Industrial bearing base, real-time joint monitoring, adjustable speed/torque, PID tuning, stall protection and over-temperature protection.
- App, PC, USB serial, Bluetooth and Wi-Fi control; wireless multi-device unicast, multicast and broadcast projects.
- LeRobot integration supports demonstration recording, datasets, model training and policy deployment.
LeRobot, Teleoperation and Learning
Use the leader arm for hand-guided teaching while the follower reproduces motion and grasping trajectories. Synchronized leader-follower operation records multimodal demonstrations for downstream learning. The workflow covers data collection, upload, imitation-learning model training, policy deployment and autonomous task execution.
NexArm integrates with the Hugging Face LeRobot ecosystem, including community models, recorded datasets, simulation resources and open-source repositories. Supported development topics include ACT, Diffusion Policy and Pi0/VLA policies. Training and deployment depend on the chosen policy, software environment and external compute; the arm controller alone does not run every large model.
External Raspberry Pi, NVIDIA platforms or a PC with a dedicated GPU can be used in the corresponding development environment. First-person vision supports hand-eye data collection around the gripper. Advanced adds third-person wide-angle vision for global workspace observation and coordinated dual-view recording. Camera functions require the corresponding kit hardware and configured software.
Control and Software
The PC host software includes action-group editing, coordinate control, a real-time 3D arm display and system settings. Edit joints frame by frame with sliders or numeric input, or enter 3D end-effector coordinates and pose parameters through inverse kinematics. Tune servo PID, offsets, speed, acceleration, torque limits, overload triggers and baud rate while monitoring voltage, position, angle, speed and torque-related parameters.
App control provides individual-joint operation, grasping/sorting demonstrations and preset action groups. The Arduino-compatible interface works with Arduino IDE and open example code with explanatory comments. Host operating systems are Windows, Linux and macOS; individual tools and policies require the corresponding supported installation.
Wireless control supports one-to-one PS3-style controller pairing and multiple independent systems. The paired imitation-learning kits include the PS3 wireless controller; the single-arm packing lists do not. Wireless multi-device projects support unicast, multicast and broadcast modes, including multilingual remote-collaboration examples. Strong external-force response can unload the joints and restore position after the force is removed.
Specifications
Platform
| Brand / model | Hiwonder NexArm LeRobot, six-axis arm |
|---|---|
| Structure | Metal frame; dual-output-shaft magnetic encoder bus servos |
| Follower payload reference | 500 g |
| Follower working radius | 0.5 m |
| Repeatability reference | ±2 mm |
| Joint travel references | Base 270°; shoulder 240°; elbow 270°; wrist reference 200°, as labeled in the joint illustration |
| Encoder feedback | 12-bit; 360° angle feedback is an encoder capability, not unrestricted arm-joint travel |
| Follower end effector | Parallel-rail gripper with silicone pads |
| Power supply | 12 V, 5 A; DC 5.5 × 2.5 mm |
| Host operating systems | Windows / Linux / macOS |
| Control interfaces | USB serial / Bluetooth / Wi-Fi |
| Programming tool | Arduino IDE |
Follower and Leader Mechanical Data
| Parameter | Follower | Leader |
|---|---|---|
| Dimensions, nominal | 111 × 111 × 614 mm | 111 × 216 × 619 mm |
| Arm mass | 1.3 kg | 1.2 kg |
| Servo complement | 2 × HX-12H + 3 × HX-30HM + 1 × HX-65HM | 5 × HX-10HM + 1 × HX-12H |
| Reduction ratio | 1:345 | 1:147 |
| Controller | ESP-WROOM + AT32F421F8P7 | ESP-WROOM |
| Drawing height | 614 mm | 619 mm |
| Drawing base widths / depth references | 111 mm; base-side reference 69 mm | Front width 122 mm; side 211 mm; rear/reference 111 mm; base-side height 69 mm |
| Drawing vertical segment references | 110 / 225 / 145 / 130 mm | 110 / 225 / 145 / 65 / 74 mm |
| Drawing end-effector references | 51 mm gripper opening; 143 mm horizontal reference | 132 mm horizontal and 132 mm handle reference |
Nominal dimensions describe the listed arm envelopes. Drawing dimensions are labeled view-specific references for installation planning; the illustrated pose changes the occupied workspace. The gripper-opening reference is 51 mm.
Servo Parameters
| Servo | Rotation speed | Stall torque | Servo accuracy |
|---|---|---|---|
| HX-10HM | 0.10 s/60° at 11.1 V | 10 kg·cm at 11.1 V | 0.3° |
| HX-12H | 0.20 s/60° at 11.1 V | 12 kg·cm at 11.1 V | 0.3° |
| HX-30HM | 0.19 s/60° at 11.1 V | 30 kg·cm at 11.1 V | 0.3° |
| HX-65HM | 0.19 s/60° at 11.1 V | 65 kg·cm at 12.6 V | 0.3° |
All four servo models support readback, temperature/voltage/position feedback, stall protection and over-temperature protection. Stall torque describes an individual servo at the stated voltage; it is distinct from the arm’s 500 g payload reference. The HX-65HM 65 kg·cm rating uses 12.6 V, while its listed speed uses 11.1 V.
Controller Shared Features
| Main chip | ESP-WROOM, 32-bit dual-core Xtensa LX6, clock ≤240 MHz |
|---|---|
| ROM / SRAM | 448 KB / 520 KB |
| Wireless | Wi-Fi and Bluetooth |
| Communication | UART, I2C, Wi-Fi, Bluetooth |
| Peripheral resources | 12-bit ADC, UART, I2C, 4 × 64-bit general-purpose timers and a 64-bit high-precision timer |
| Development environment | Arduino IDE |
| Interfaces | USB Type-C, UART, I2C and bus-servo connections |
| Buzzer | PWM frequency output supported |
| Input | 12 V, 5 A |
Follower Controller
| Secondary controller | AT32F421F8P7, 32-bit ARM Cortex-M4, ≤120 MHz, 64 KB flash |
|---|---|
| ESP-WROOM flash | 4 MB |
| Servo ports | 4 total: 2 × 5264 and 2 × PH2.0 |
| I2C ports | 3 |
| Display | 0.96-inch OLED, 128 × 64 pixels |
| Custom buttons | 2 |
| Type-C power output | 5 V, 5 A |
| Additional labeled features | Power switch, DC input, UART, display/button port and AT32 controller; continuous interpolation and smooth acceleration/deceleration |
Leader Controller
| Servo ports | 2 total: 1 × 5264 and 1 × PH2.0 |
|---|---|
| Reserved connections | I2C and 2 GPIO ports |
| Additional interfaces | Joystick port and chassis remote-control module connection |
| Other labeled features | Power switch, LED indicator and buzzer |
Vision Modules
| Parameter | First-person camera | Third-person camera |
|---|---|---|
| Image sensor | GC0308 | GC2083 |
| Resolution | 0.3 MP | 2 MP |
| Output | 640 × 480 | 1920 × 1080 MJPG; 640 × 480 YUYV |
| Aperture | f/2.2 | f/2.2 |
| Focal length | 3.6 mm | 3.42 mm |
| Field of view | 120° | 160° |
| Distortion | −25% | Not specified |
| Maximum frame rate | Not specified | 30 fps |
| Dimensions | 30 × 27 × 24 mm | 30 × 27 × 20 mm |
| Kit inclusion | Standard and Advanced | Advanced only |
The camera modules support manual focus and driver-free plug-and-play capture in the configured host environment.
Packaging References
| Single-arm package dimensions | 345 × 158 × 220 mm |
|---|---|
| Standard Kit package | 487 × 290 × 195 mm; 6.7 kg reference |
| Advanced Kit package | 487 × 290 × 195 mm; 7.9 kg reference |
Applications
- Teleoperation dataset collection: pair leader and follower arms to record demonstrated grasping and placement trajectories.
- Imitation-learning experiments: use recorded demonstrations and the LeRobot software environment to train and evaluate manipulation policies.
- Vision-guided tabletop tasks: collect gripper-view observations with Standard, or combine gripper and workspace views with Advanced.
- Motion-control teaching: compare direct joint commands, inverse-kinematics coordinate control and acceleration/deceleration settings.
- Custom robotics development: extend Arduino code and controller interfaces for coordinated devices and sensor-based projects.
What's Included
Follower Arm or Leader Arm
Each single-arm selection includes the corresponding assembled arm, G clamps, an adapter plate, a 12 V 5 A DC 5.5 × 2.5 mm power adapter, a 1000 mm Type-C cable, 200 mm module/servo cables, screw pack, screwdriver and user manual. These selections do not include a camera, a second arm or the paired-kit controller.
Imitation Learning Standard Kit
Includes one assembled follower arm, one assembled leader arm, G clamps, adapter plates, a 0.3MP wide-angle camera with bracket, PS3 wireless controller, two 12 V 5 A power adapters, a four-port USB hub with 1000 mm cable, 1000 mm Type-C cables, 1000 mm USB data cable, 200 mm module/servo cables, screw pack, screwdriver and user manual.
Imitation Learning Advanced Kit
Includes the Standard paired-arm equipment, plus a 2MP wide-angle camera with bracket and an all-metal camera mount for a third-person workspace view. Computer, screen, training workstation, additional robots and scene props are not included.
FAQ
Do I need two arms for imitation learning?
Leader-follower teaching requires both a leader and a follower. Standard and Advanced include the pair; the Follower Arm and Leader Arm selections each contain only the named arm.
How do Standard and Advanced differ?
Both paired kits include a first-person 0.3MP camera and bracket. Advanced adds a 2MP third-person camera and all-metal camera mount for dual-view collection.
Does every selection include a PS3 controller or camera?
No. The paired Standard and Advanced kits include a PS3 wireless controller and camera equipment; the single-arm packing lists do not.
Can the ESP32 controller train large AI policies by itself?
Model training and deployment use a compatible external compute platform and the configured LeRobot/policy environment. The arm controllers handle motion and communication; no training computer is included.
Is 65 kg·cm the arm payload?
No. It is the HX-65HM servo stall-torque rating at 12.6 V. The follower arm has a separate 500 g payload reference.
Videos
Visual Details
Images include paired-arm demonstrations and Advanced dual-camera equipment. Camera and controller inclusion follows the selected configuration above.