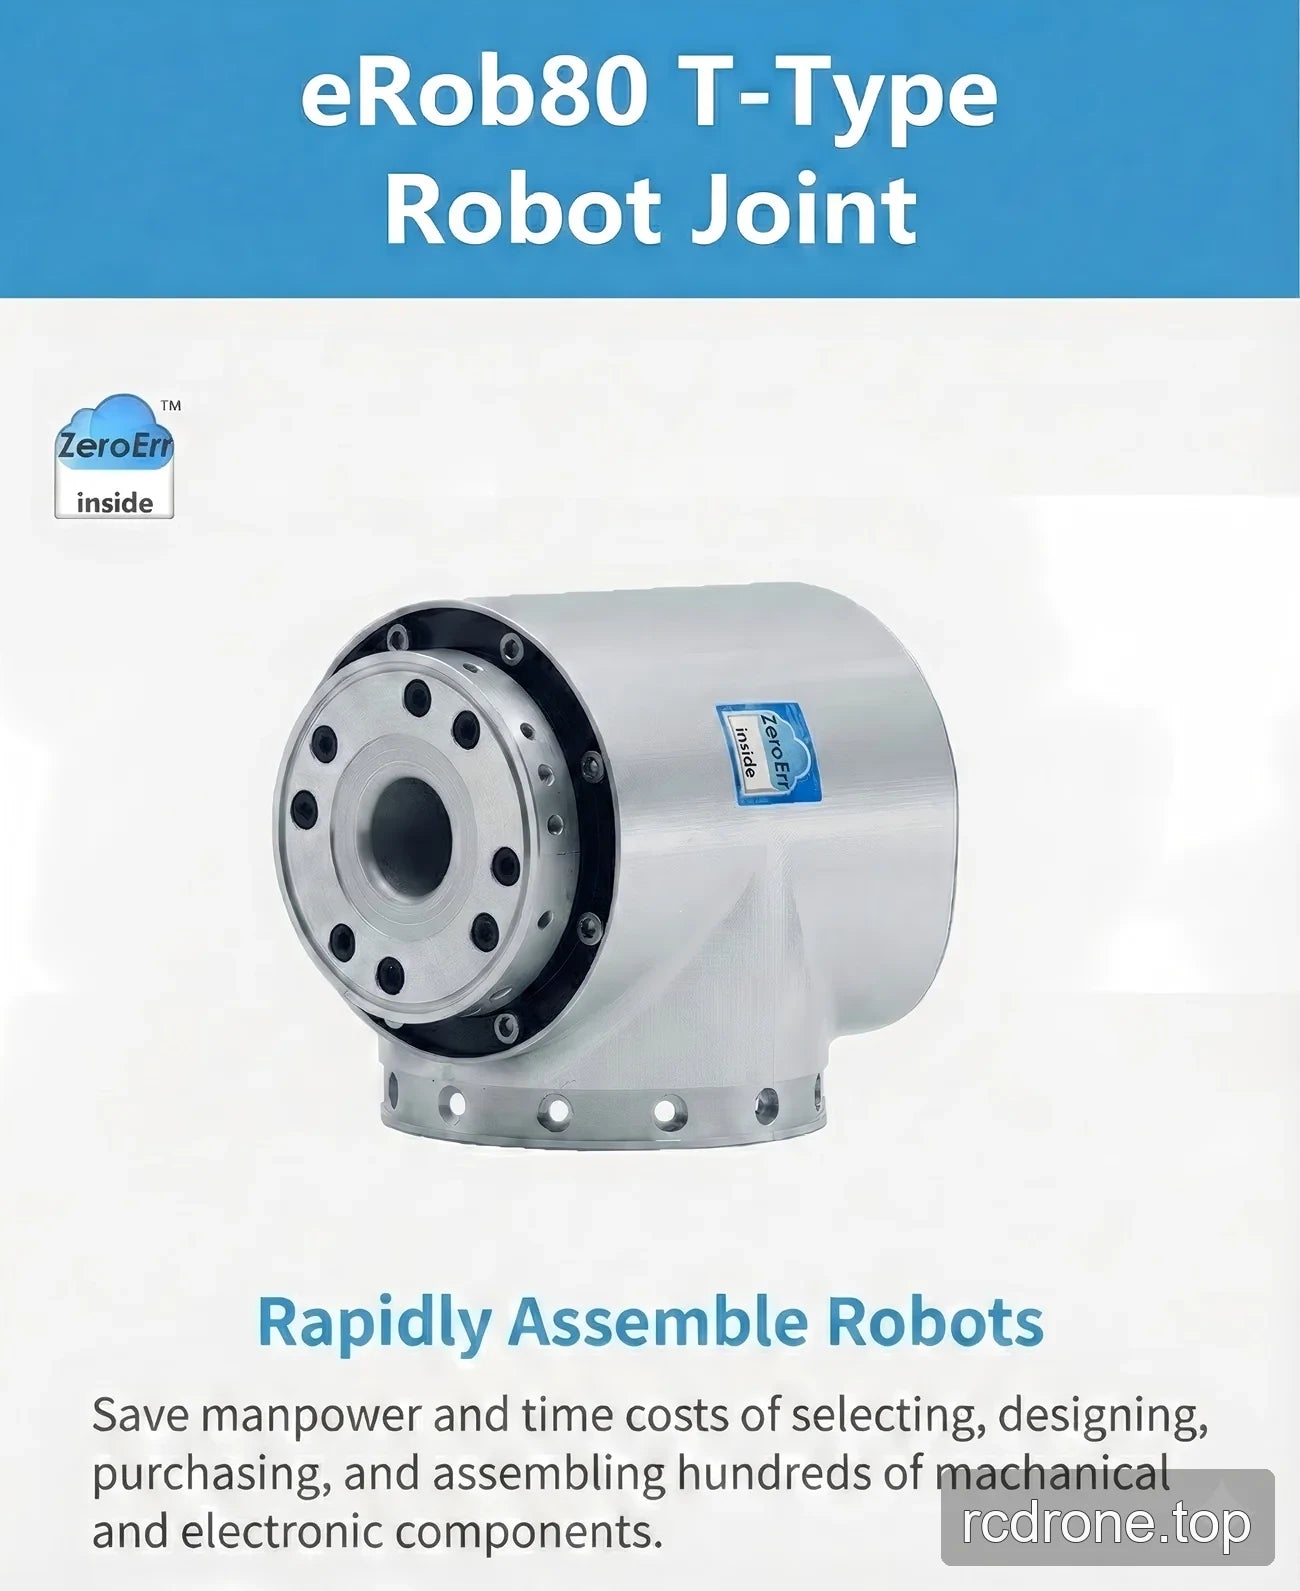
ZeroErr eRob 80 T Robot Joint Actuator, EtherCAT/CANopen, Torque Sensor Options
ZeroErr eRob 80 T Robot Joint Actuator, EtherCAT/CANopen, Torque Sensor Options
ZeroErr
পিকআপের উপলভ্যতা লোড করা যায়নি


Overview
The ZeroErr eRob 80 T is a robot joint actuator family with EtherCAT or CANopen version selections, optional torque sensing, reduction-ratio selections, and multi-loop memory selections.
Features
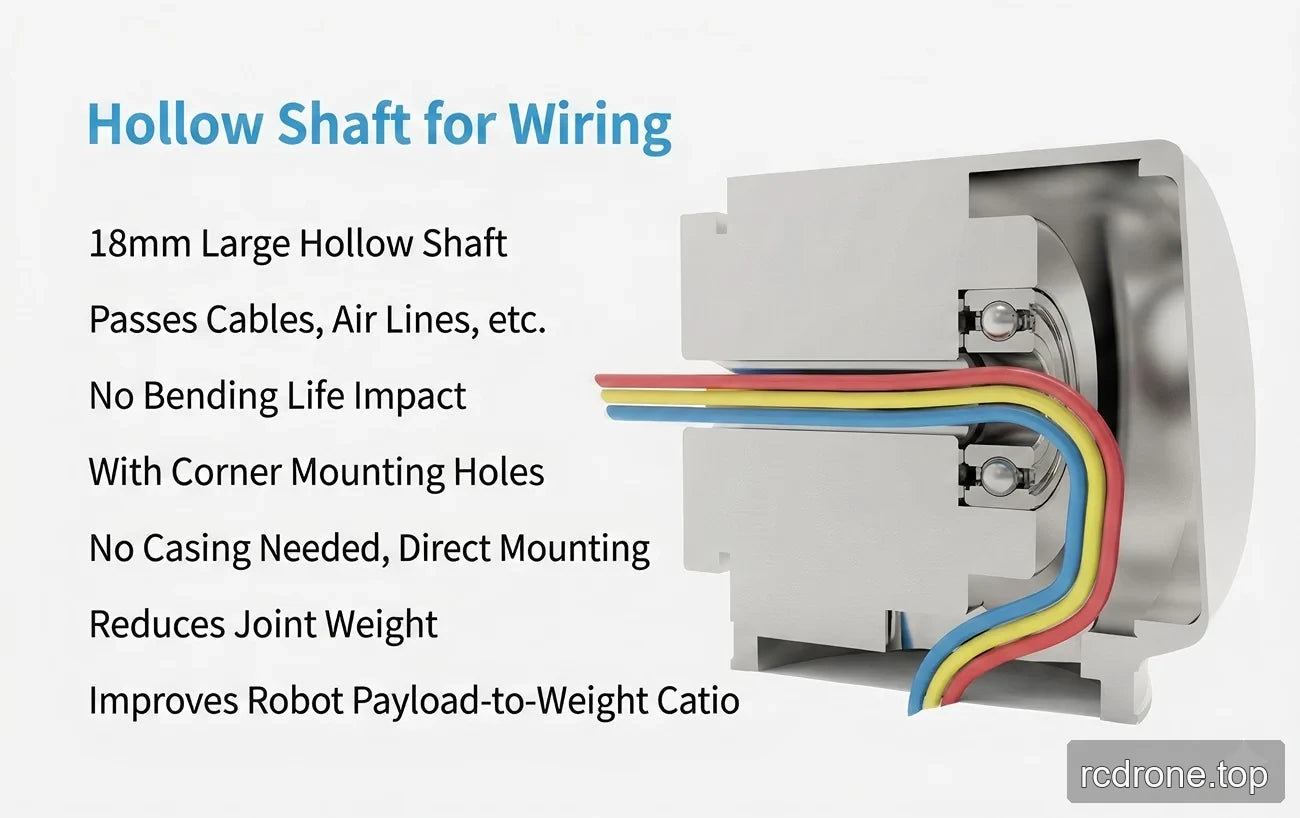
- 18 mm hollow shaft for routing cables and air lines; the routing is stated not to affect bending life.
- Corner mounting holes and direct-mounting design.
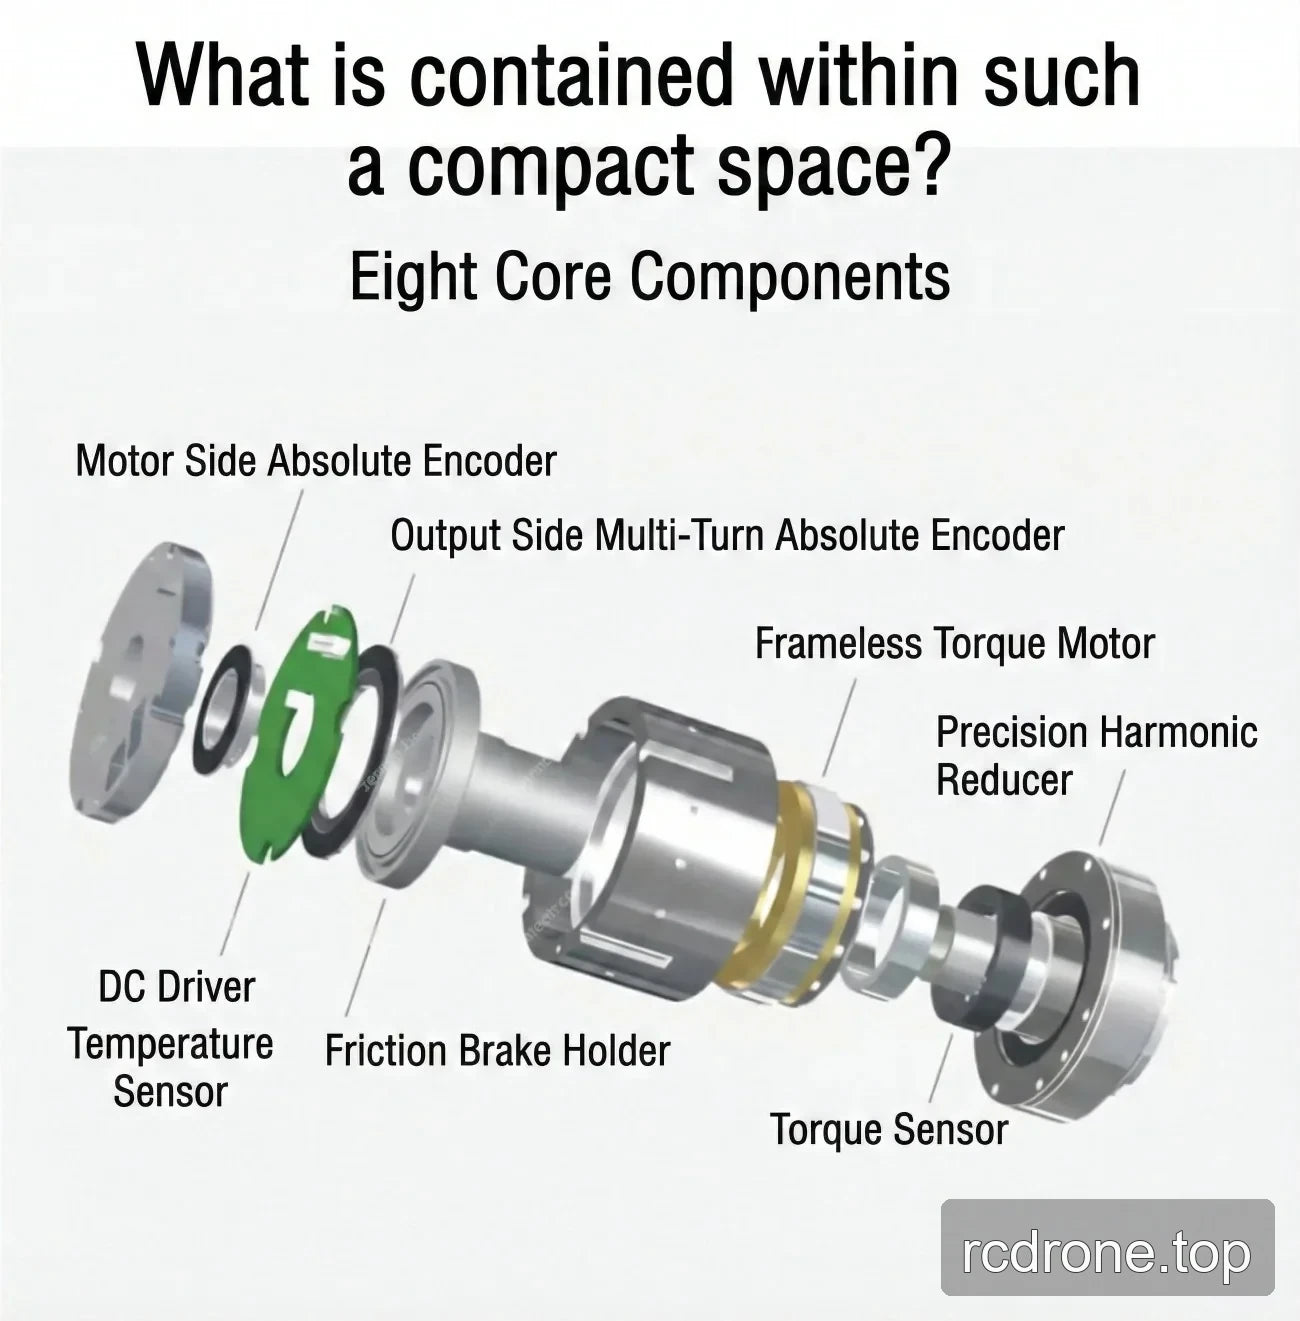
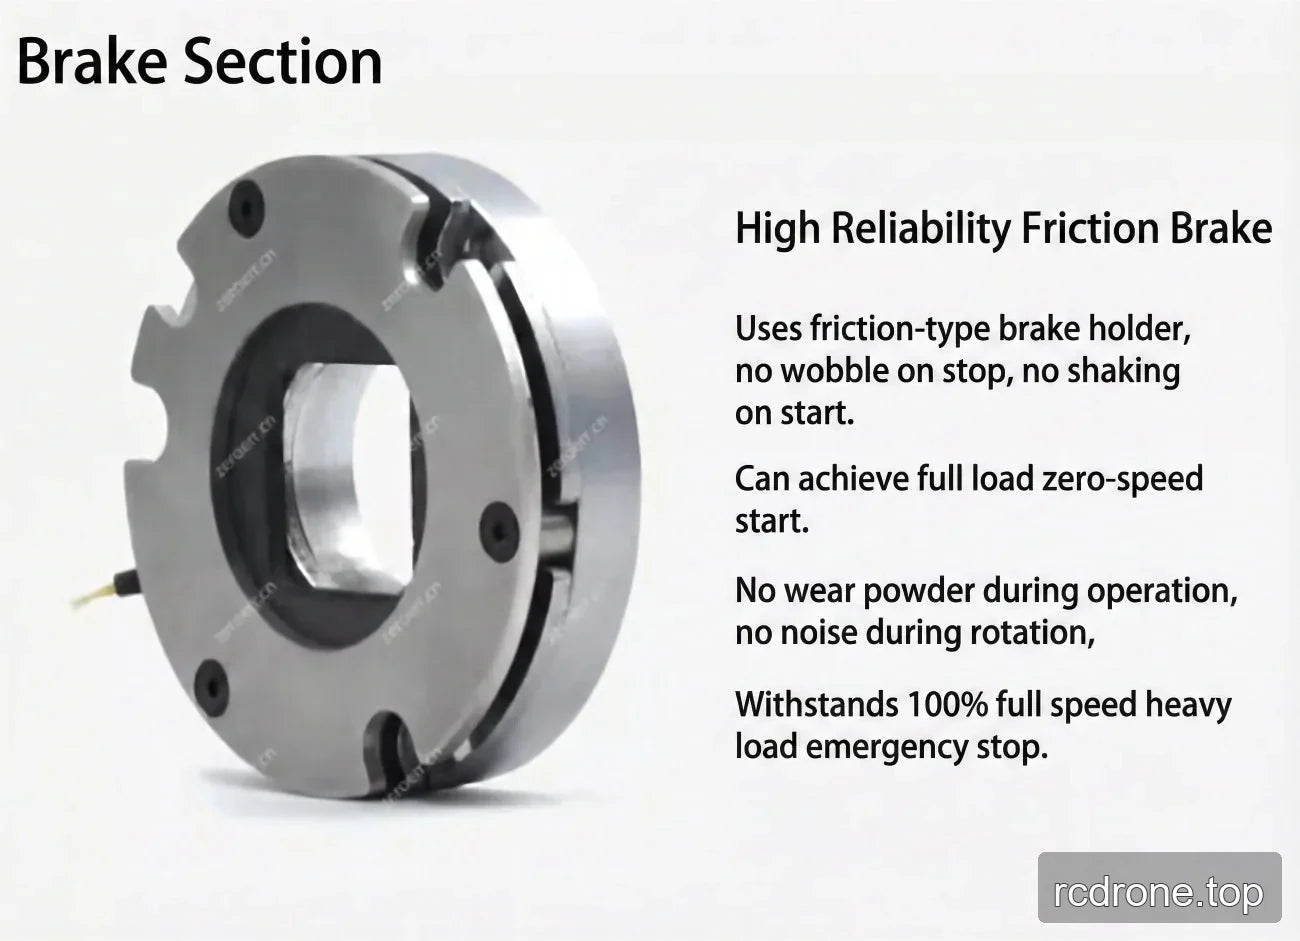
- Friction brake.
Configuration Options
| Selection | Available labels |
|---|---|
| Version | eRob 80 T (CANopen With Torque Sensor); eRob 80 T (CANopen Without Torque Sensor); eRob 80 T (EtherCAT With Torque Sensor); eRob 80 T (EtherCAT Without Torque Sensor) |
| Reduction Ratio | 50; 80; 100 |
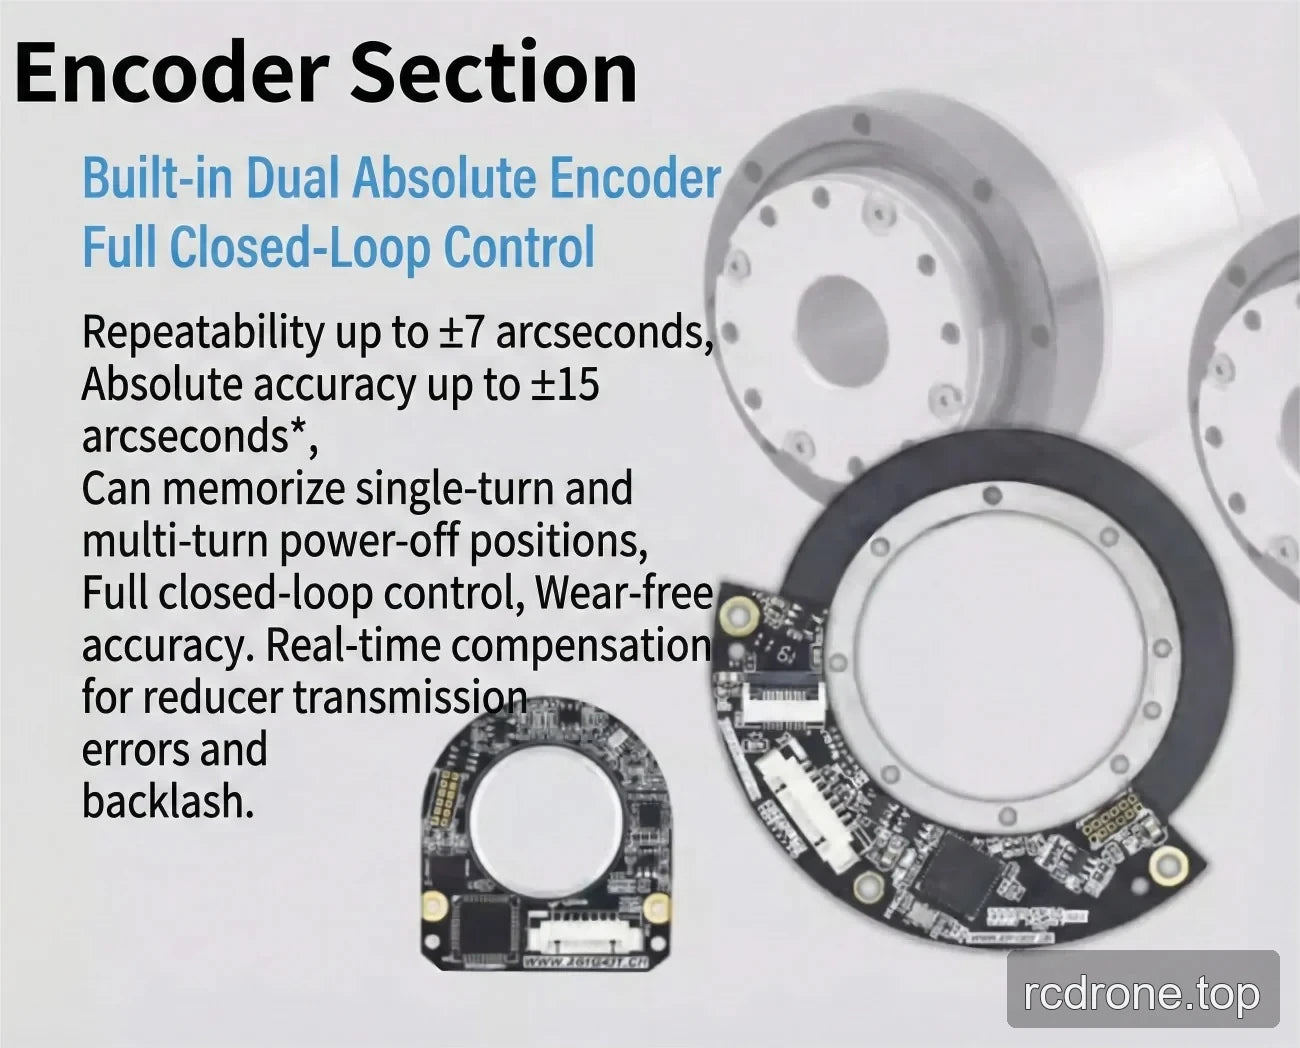
| Multi-loop Memory | Without Multi-loop Memory; With Multi-loop Memory |
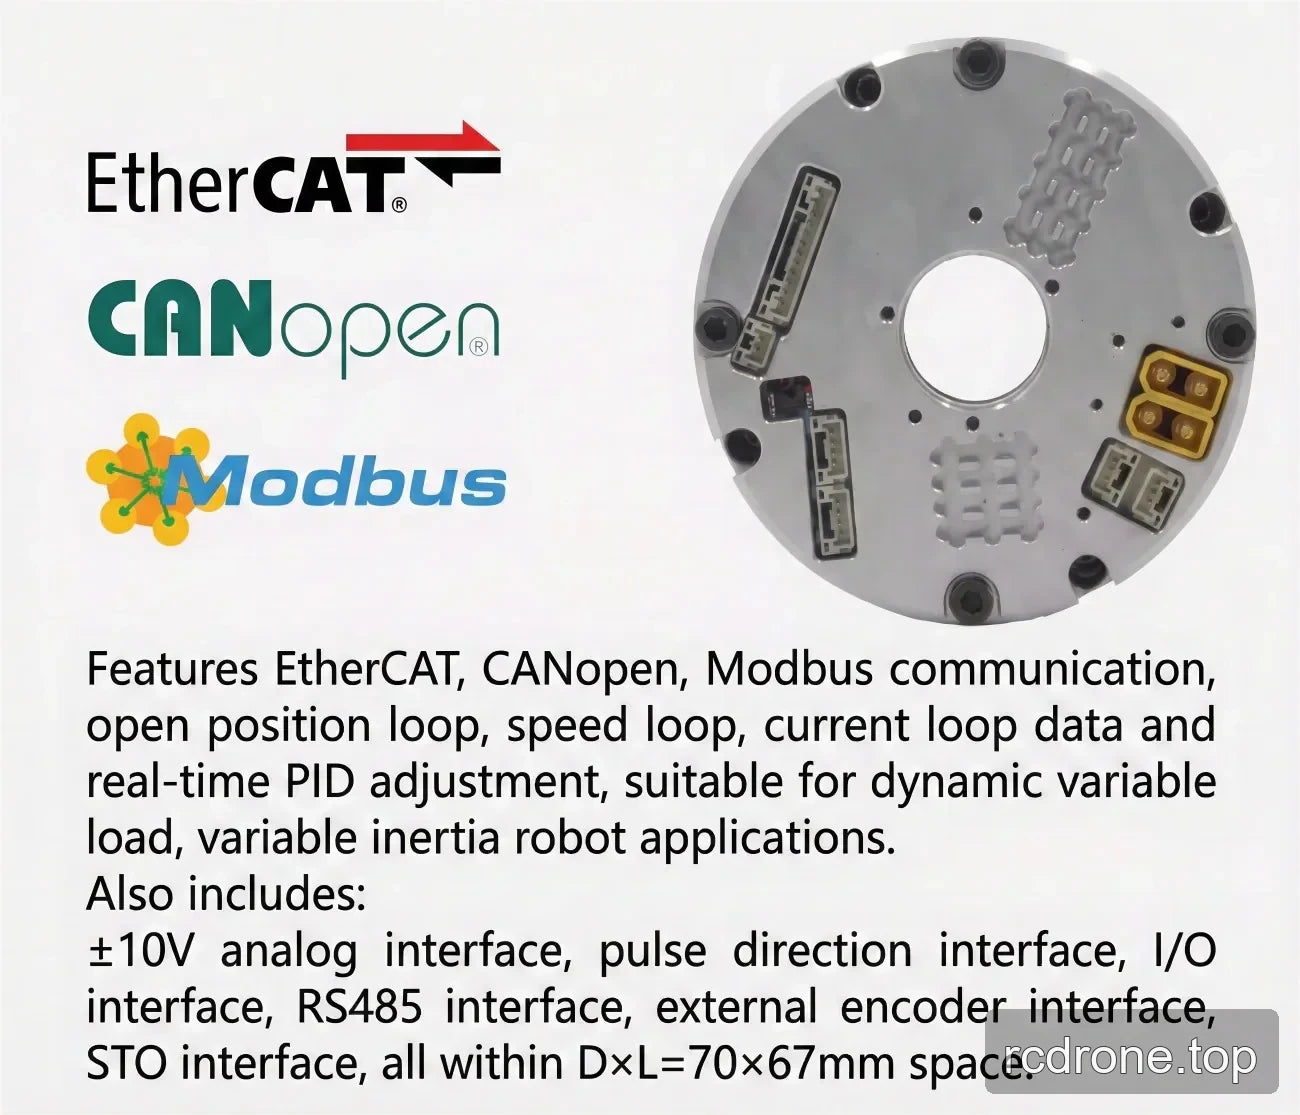
The EtherCAT versions use the EtherCAT communication option, and the CANopen versions use the CANopen communication option. The With Multi-loop Memory selection is stated to memorize single-turn and multi-turn power-off positions.
Specifications
| Parameter | Value |
|---|---|
| Product type | eRob 80 T robot joint actuator |
| Hollow-shaft diameter | 18 mm |
| Communication selections | EtherCAT or CANopen, depending on selected version |
| Brake type | Friction brake |
Applications
- Humanoid robots
- Robotic arms
- Exoskeletons
- Quadruped robots
- AGV vehicles
- ARU robots
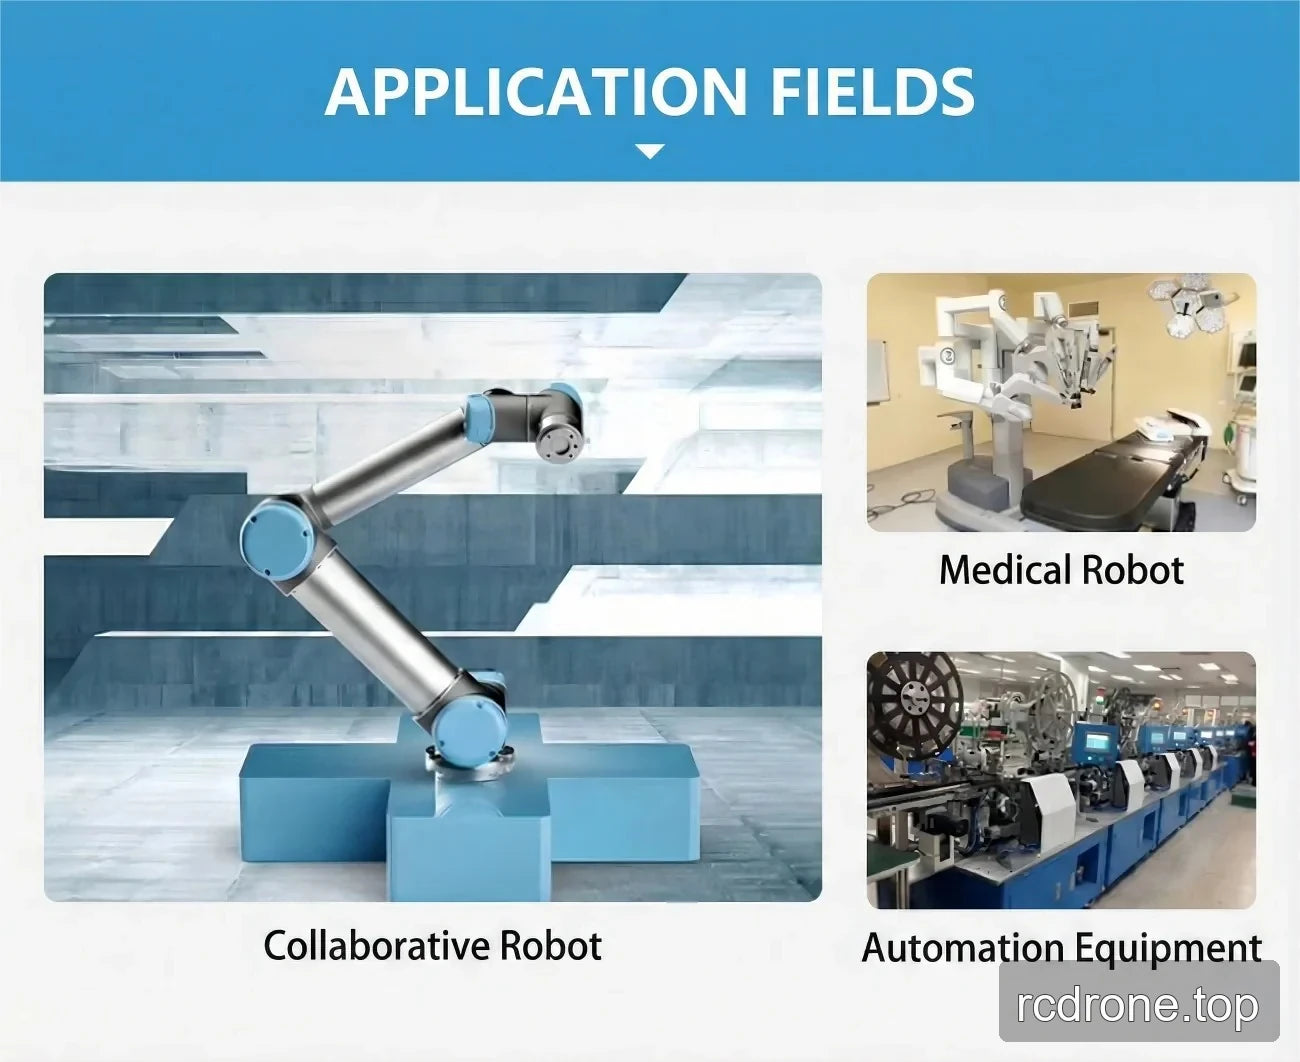
- Collaborative robots
- Medical robots
- Automation equipment
Documents
EROB170I I Series EtherCAT eRob80T — 3D Model (ZIP)
EROB170I I Series EtherCAT — 3D Model (ZIP)
EROB80 T Series EtherCAT — 3D Model — STEP File (ZIP)
EROB80 T Series CANopen — 3D Model — STEP File (ZIP)
EROB80 T Series EtherCAT instalation drawing — Installation Drawing (PDF)
EROB80 T Series CANopen instalation drawing — Installation Drawing (PDF)
Visual Details
Product Video
Product Views
Features and Design
Interfaces and Connections
Specifications and Performance
Application Examples