


CHIHAI CHS-GM25-25BY High-Reduction Stepper Gear Motor, 100:1–478:1
CHIHAI CHS-GM25-25BY High-Reduction Stepper Gear Motor, 100:1–478:1
CHIHAI MOTOR
No se pudo cargar la disponibilidad de recogida


Overview
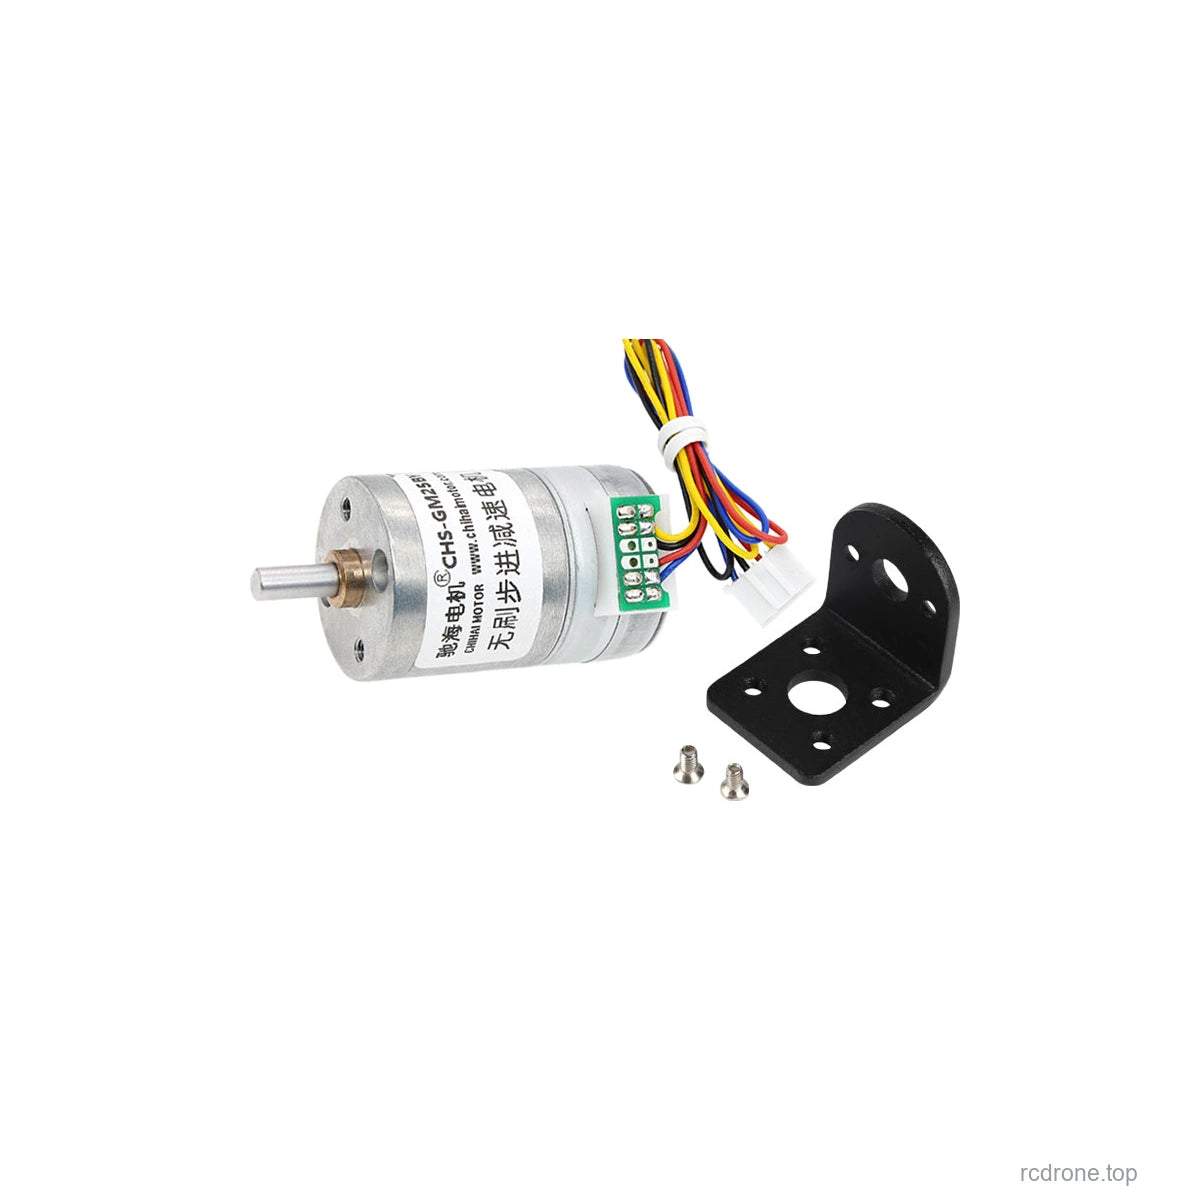
The CHIHAI MOTOR CHS-GM25-25BY is a compact geared stepper motor with a25mm gearbox and a two-phase, four-wire bipolar motor. This high-reduction range covers nominal100:1,125:1,165:1,217:1 and478:1 ratios for low-speed positioning mechanisms. Its4mm D-shaped output shaft helps secure a mating hub.
Choose Your Package
Select Motor Only, Motor + Bracket, Motor + Driver Board, Motor + Enclosed Driver, or Motor + Bracket + Driver Board. Each package contains one selected-ratio motor and only the named accessories. The enclosed-driver package includes its case; a bare Driver Board package does not. Power supply, application machinery and additional installation hardware are not included unless pictured as part of the selected mounting package.
Mechanical Specifications
| Parameter | Reference |
|---|---|
| Gearbox / motor diameter | 25mm |
| Output shaft | 4mm D shaft,3.5mm across flat;12mm projection,8mm flat length |
| Gearbox length L | 100:1 drawing reference98.78:1:23mm;165:1 drawing164.63:1:25mm;217:1 drawing217.31:1:25mm;478:1 drawing478.08:1:27mm. Confirm125:1 length before machining. |
| Motor section | 14.8mm length |
| Front locating boss | 7mm diameter,2.5mm projection |
| Mounting | 2×M3 tapped holes,2mm depth;17mm spacing |
| Rear boss | 6mm diameter;3.7mm projection |
| Lead and connector | 150±10mm; PHR-4,2.0mm pitch; UL1571 AWG28 reference |
| Net motor mass | Approximately75g; varies with reduction ratio |
12V Performance Reference
Output values below use700 input pulses per second. The unreduced motor step angle is15°; the smaller listed step angle applies after the gearbox. No-load output speed decreases under load.
| Nominal ratio | Performance chart ratio | Output step | No-load rpm at700pps | Holding kgf·cm | Pull-out kgf·cm |
|---|---|---|---|---|---|
| 100:1 | 98.8:1 | 0.15° | 17.7 | ≥6.5 | ≥5.5 |
| 125:1 | 125:1 | 0.12° | 14 | ≥8.0 | ≥7.0 |
| 165:1 | 165:1 | 0.09° | 10.6 | 9.0 max | 9.0 max |
| 217:1 | 217:1 | 0.069° | 8.1 | 9.0 max | 9.0 max |
| 478:1 | 478:1 | 0.031° | 3.7 | 9.0 max | 9.0 max |
“9.0 max” is a maximum permissible load, not a minimum torque rating. Do not exceed9.0kgf·cm on the165:1,217:1 or478:1 configurations. Holding torque describes a stationary energized motor; it is not continuous running torque. Use the actual load and motion profile when selecting a ratio.
Motor Electrical Reference
| Parameter | Value |
|---|---|
| Drive reference | 12V DC using L6219 driver reference; bipolar drive,2-phase excitation |
| Phase current | 300mA per phase |
| Phase resistance | 10Ω±7% per phase |
| Phase inductance | 7.5mH per phase |
| Motor step angle before gearbox | 15° per step |
| Motor pull-out torque before gearbox | >60gf·cm at100pps |
| Motor holding torque before gearbox | >75gf·cm at0pps |
| Maximum response / starting frequency | >1300pps / >800pps reference |
| Insulation | Class E coils;100MΩ at500V DC;100V AC for1second dielectric reference |
| Operating temperature | −10°C to55°C |
Connection and Driver Use
This is a four-wire bipolar stepper motor requiring a compatible two-phase driver. It does not contain a self-running brushless DC commutation driver. Use a driver matched to the motor's300mA-per-phase reference and the actual supply; do not apply DC directly across arbitrary connector pins.
| Connector pin | Wire color | Winding pair |
|---|---|---|
| 1 | Yellow | Yellow–Red winding |
| 2 | Red | Yellow–Red winding |
| 3 | Black | Black–Blue winding |
| 4 | Blue | Black–Blue winding |
Verify pin numbering and coil continuity before connecting. A two-phase excitation sequence is Yellow+Black, Yellow+Blue, Red+Blue, Red+Black; reverse the sequence to reverse rotation. Output-shaft direction depends on gearing and the viewing direction, so check it unloaded. Disconnect power before rewiring; do not force the output shaft, overload the gearbox or operate stalled.
Applications
The high reduction ratios suit low-speed positioning, indexing and compact mechanisms that need small output steps. Allow for gearbox backlash and verify positioning performance in the actual mechanism. No closed-loop encoder or feedback controller is included.
What's Included
One high-reduction stepper motor in the chosen ratio. The bracket, bare driver board or enclosed driver is included only when named in the selected Package. A power supply and example machinery are not included.
Visual Details


