HAITAI OpenArm Dual-Encoder Joint Motors – HT4510 & HT8116, 24V
HAITAI OpenArm Dual-Encoder Joint Motors – HT4510 & HT8116, 24V
HAITAI
No se pudo cargar la disponibilidad de recogida


Overview
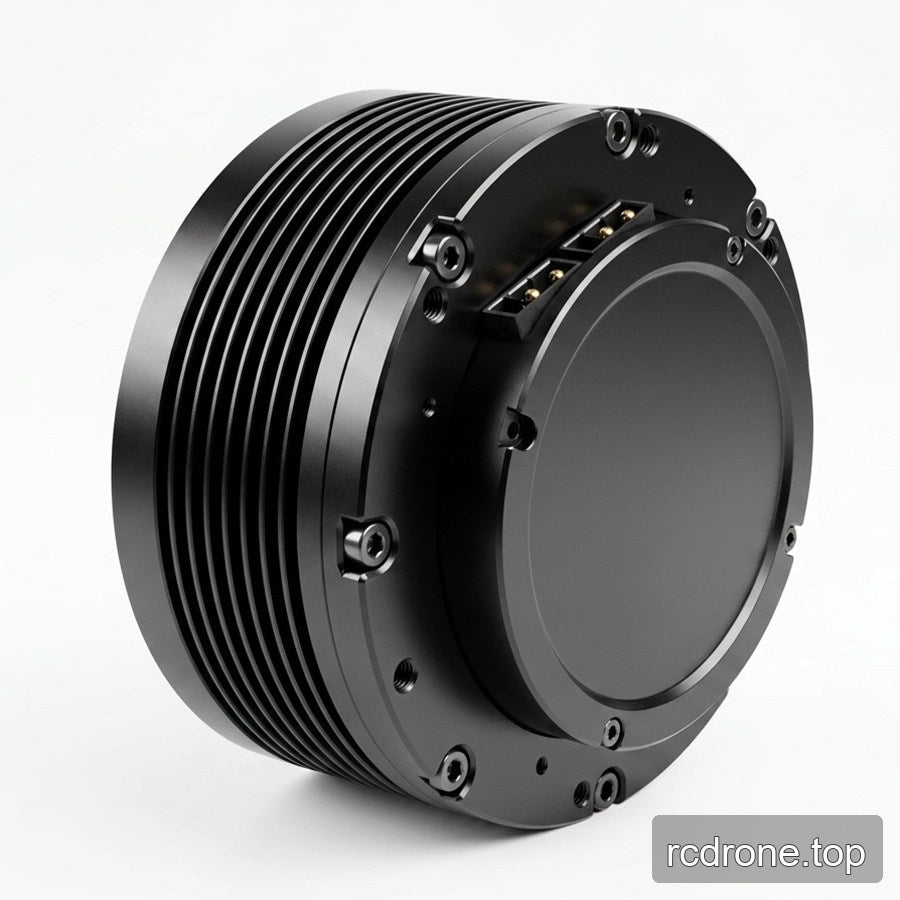
HAITAI OpenArm joint motors combine a brushless motor, planetary reduction and dual magnetic encoders in a compact rotary joint. Choose HT4510-J10-2E, HT4510-J36-2E or HT8116-J9-2E for the torque and installation requirements of your robotic arm.
All selectable configurations use 24V delta winding. Each model is available without a driver or with a GDZ driver. This listing is for the selected joint-motor configuration, not a complete dual-arm robot kit.
Features
- Three model-specific torque levels: 2.9 Nm, 9.9 Nm and 20 Nm.
- Dual 14-bit magnetic encoders with single-turn absolute output-shaft position feedback.
- Planetary reduction integrated with the brushless motor.
- GDZ-equipped configurations support MIT control mode; a dedicated test host utility is part of the motor solution.
- Mounting layout designed for OpenArm integration, with model-specific drawings for fit checks.
- Power and communication in/out layout simplifies joint wiring on equipped configurations.
Specifications
| Parameter | HT4510-J10-2E | HT4510-J36-2E | HT8116-J9-2E |
|---|---|---|---|
| Rated voltage | 24 VDC | 24 VDC | 24 VDC |
| Winding | Delta | Delta | Delta |
| Rated torque | 2.9 Nm | 9.9 Nm | 20 Nm |
| Rated current | 4.7 A | 4.8 A | 20 A |
| Rated speed | 280 rpm | 74 rpm | 100 rpm |
| Maximum speed | 307.8 rpm | 89.2 rpm | 172.9 rpm |
| Motor mass | 0.3 kg | 0.4 kg | 0.95 kg |
| Pole pairs | 14 | 14 | 21 |
| Torque constant | 0.24 Nm/A | 0.864 Nm/A | 0.45 Nm/A |
| Stall torque | 11.95 Nm | 39.73 Nm | 60.07 Nm |
| Stall current | 30.05 A | 23.62 A | 57.75 A |
| Phase-to-phase inductance | 185 μH | 185 μH | 70 μH |
| Phase-to-phase resistance | 0.6 Ω | 0.6 Ω | 0.121 Ω |
| Encoder | Dual, 14-bit magnetic | Dual, 14-bit magnetic | Dual, 14-bit magnetic |
| Output position feedback | Single-turn absolute | Single-turn absolute | Single-turn absolute |
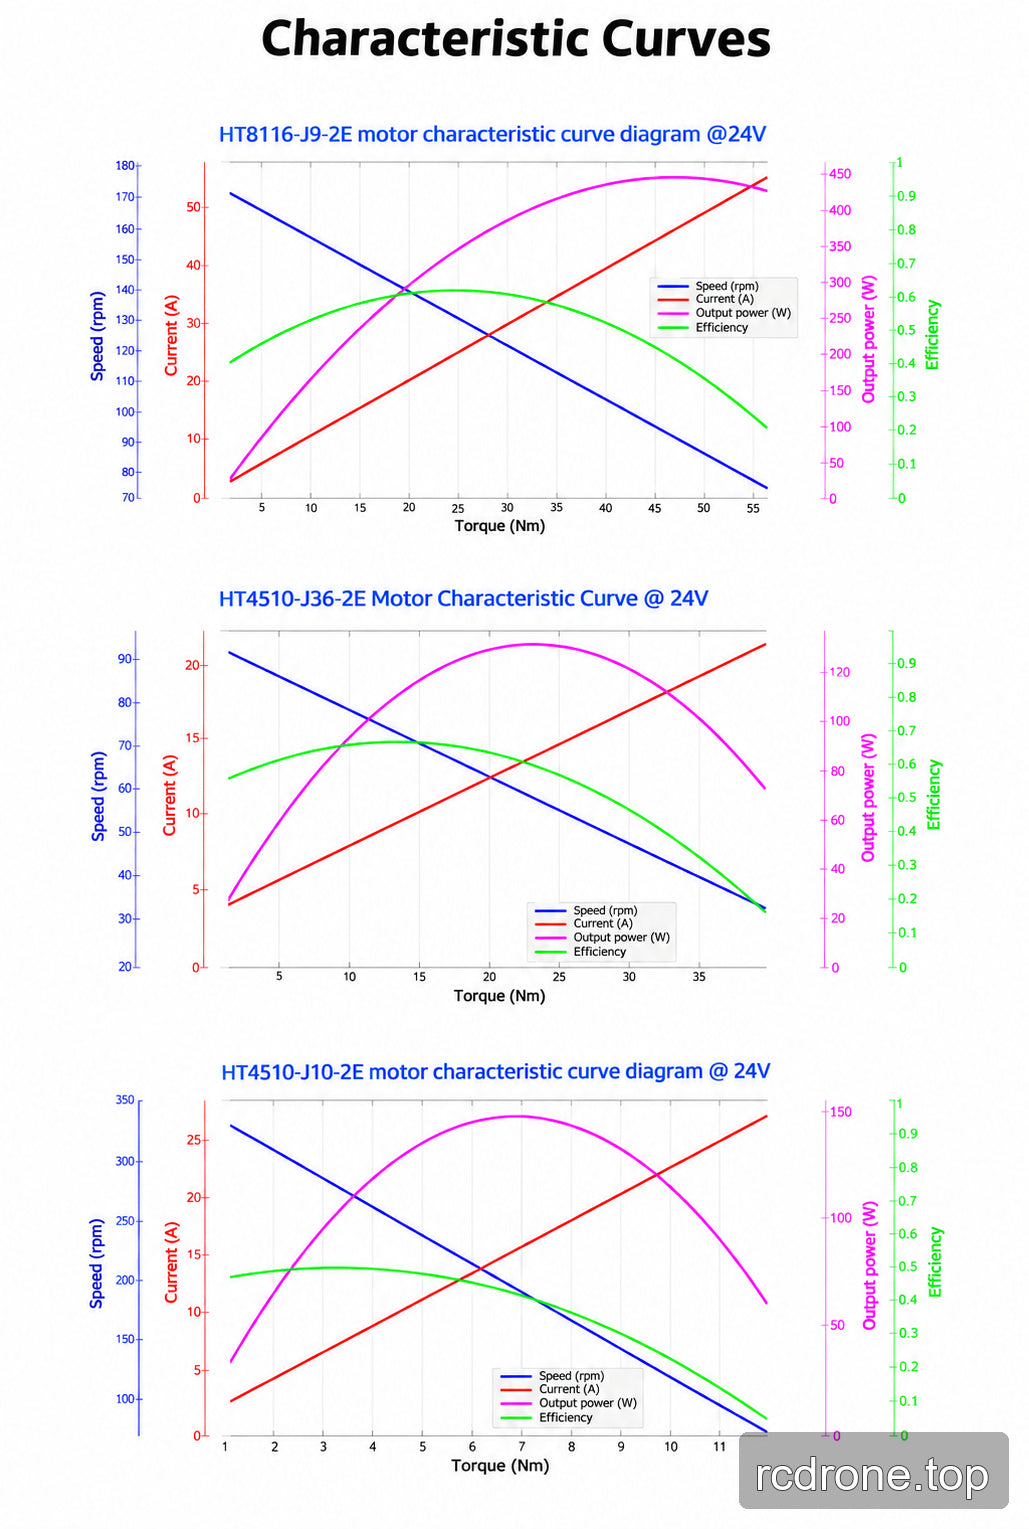
HT8116-J9-2E has a 9:1 reduction ratio, 40 Nm peak torque, 50 A peak current and CAN communication at 1 Mbps. Peak and stall values are not continuous operating ratings. The motor mass figures above are component weights, not packed shipping weights.
HT4510 operating points
| Model | Duration | Torque | Speed | Current |
|---|---|---|---|---|
| HT4510-J10-2E | 5 minutes | 2.90 Nm | 280 rpm | 4.7 A |
| HT4510-J10-2E | 20 minutes | 2.35 Nm | 290 rpm | 3.8 A |
| HT4510-J10-2E | Thermal equilibrium | 1.84 Nm | 301 rpm | 3.1 A |
| HT4510-J36-2E | 5 minutes | 9.9 Nm | 74 rpm | 4.8 A |
| HT4510-J36-2E | 20 minutes | 8.4 Nm | 79 rpm | 3.8 A |
| HT4510-J36-2E | Thermal equilibrium | 6.7 Nm | 82 rpm | 3.1 A |
Motor connector and installation
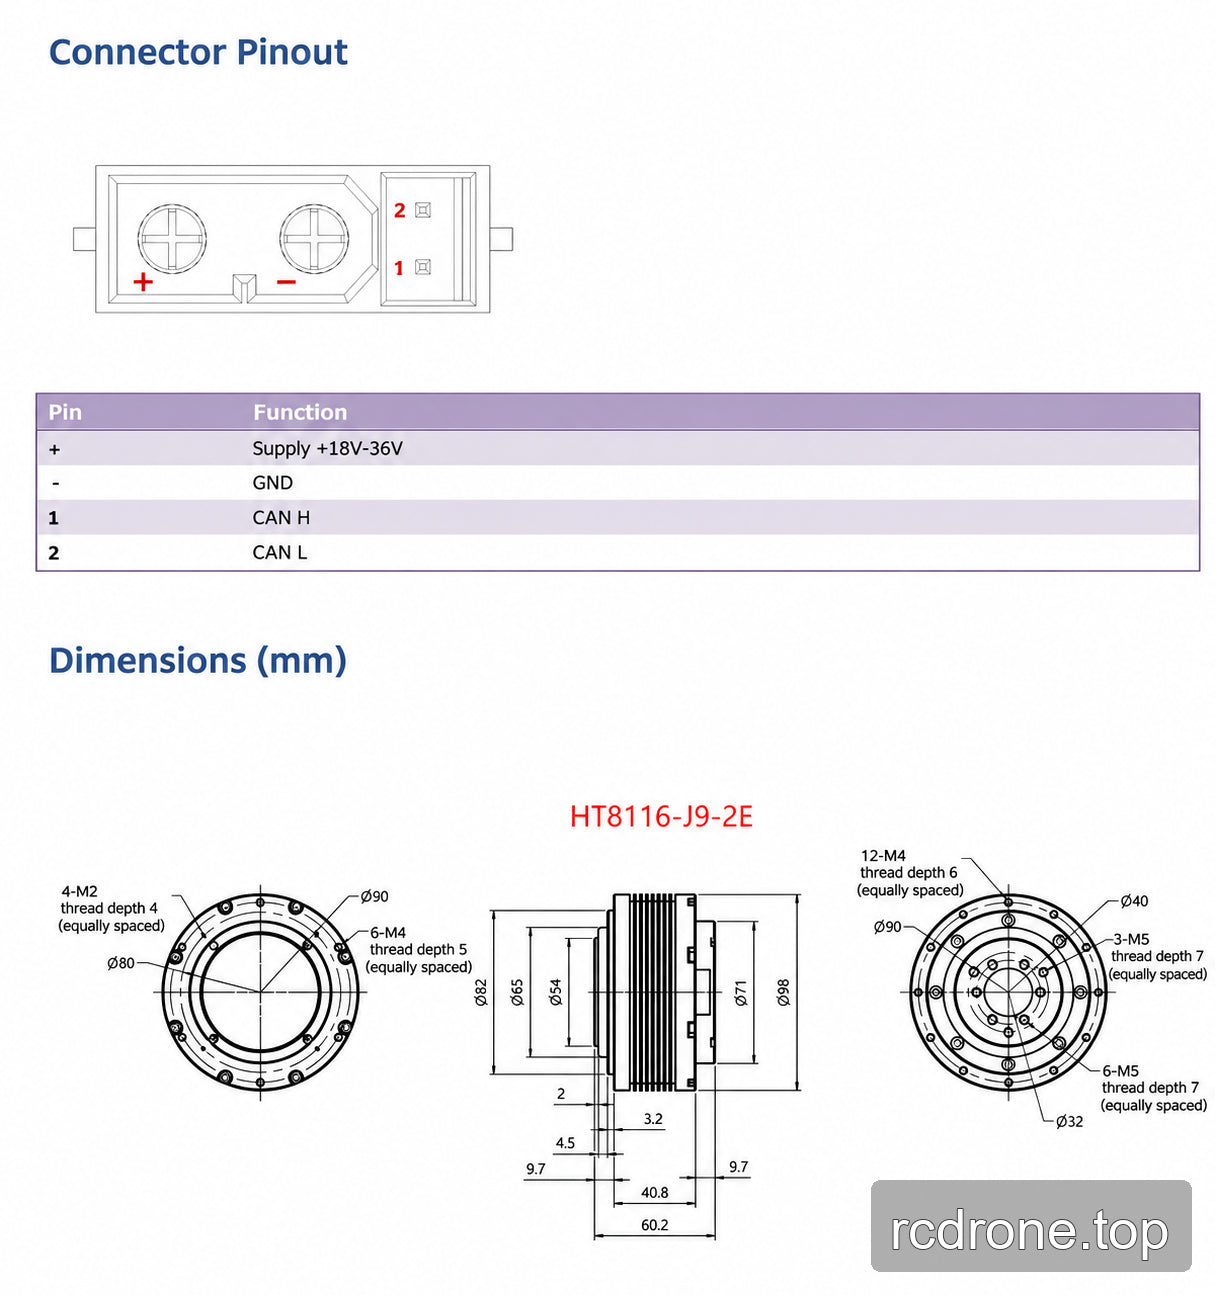
The illustrated motor connector uses + for supply positive (18–36 V), − for GND, pin 1 for CAN H and pin 2 for CAN L. These are 24 V winding configurations. Check the model-specific mounting drawing before installation. For HT4510-J10-2E and HT4510-J36-2E, screw insertion must not exceed 7 mm.
GDZ driver interface versions
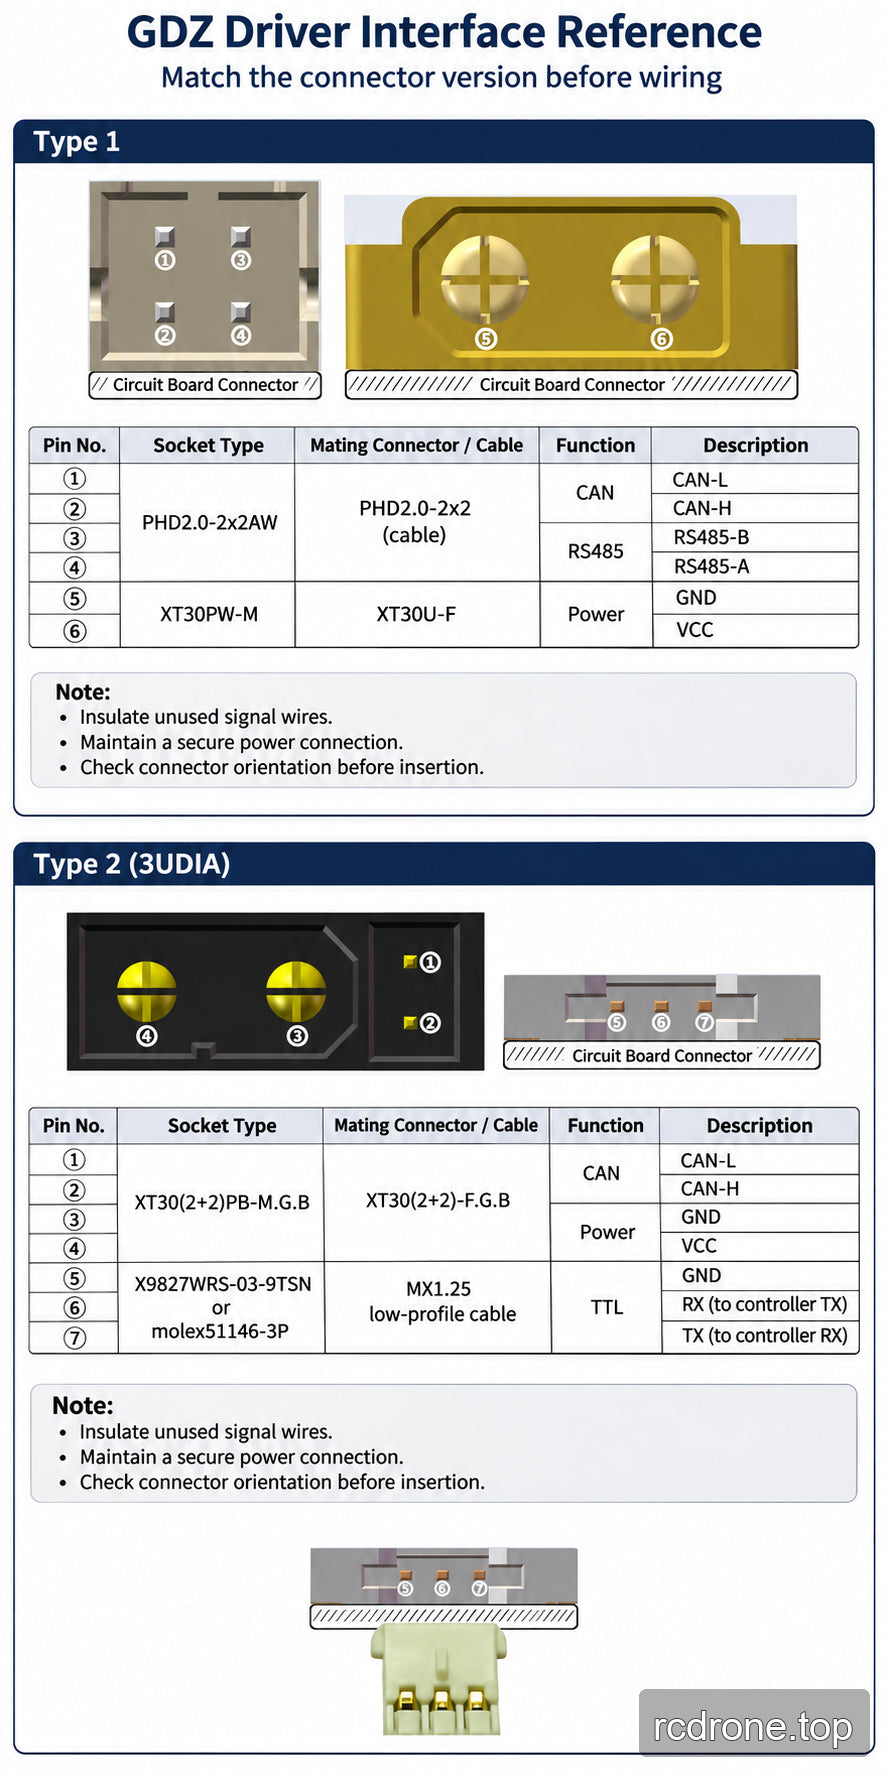
GDZ interface Type 1 uses separate CAN/RS485 and power connectors; Type 2 (3UDIA) uses a combined CAN/power connector and a TTL serial connector. Match the physical connector version to its diagram. A GDZ option does not imply that both interface versions are included.
For Type 1, the driver reference distinguishes a yellow XT30 socket (12–40 V driver input) from a black XT30 socket (15–60 V). For Type 2, a white TTL socket identifies the 12–40 V version and a black TTL socket the 15–60 V version. These driver-board ranges do not change the selected motor’s 24 V rating or its illustrated 18–36 V supply range.
Keep signal conductors insulated, including unused CAN or RS485 wires. Maintain secure power contacts to prevent unintended current paths through communication interfaces. Insert the MX1.25 low-profile plug with its latch facing away from the circuit board. XT30 contacts with a narrowed or deformed cross-slot can cause an intermittent connection; service damaged or loose contacts before operating.
What's Included
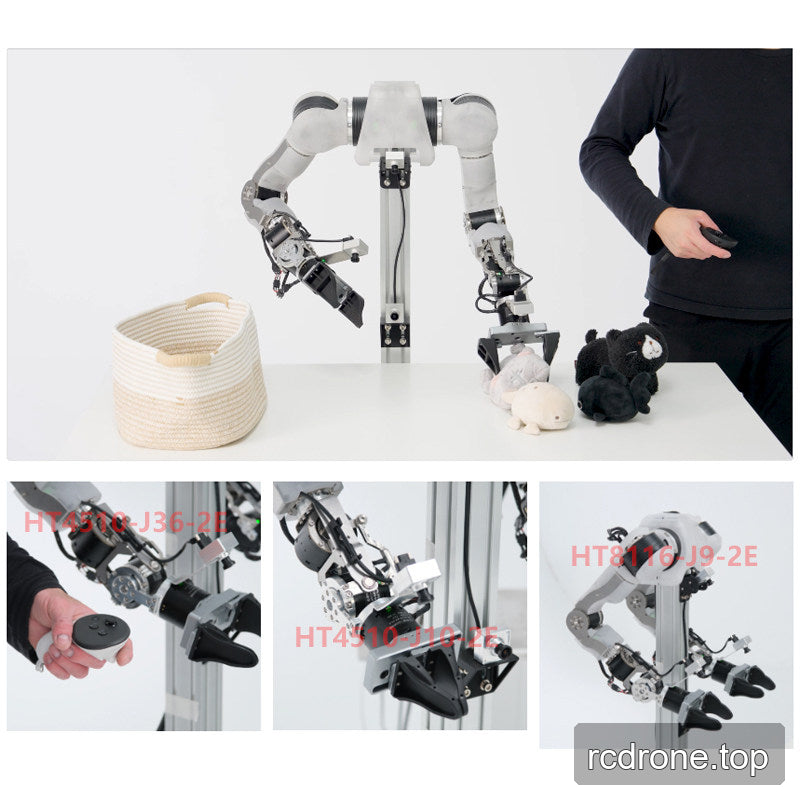
One joint motor in the selected model and winding configuration. The “With GDZ driver” option includes the GDZ driver; the “Without driver” option does not. Complete robot arms, grippers, external controllers and power supplies shown in application examples are not included.
Applications
Designed for OpenArm robotic-arm joints and custom robotics and motion projects. Suitable integration areas include articulated manipulators, legged robots and SCARA mechanisms when the selected model’s load, speed, mounting and control requirements match the design.
FAQ
Does every option include a GDZ driver?
No. Select “With GDZ driver” when you need that driver. “Without driver” requires a compatible drive solution.
Is this a full OpenArm motor set?
No. Choose the individual joint model and driver configuration needed for your build. The application images show complete systems for context.
Can I select a 48V winding?
The configurations offered here are 24V delta winding only.
Are the rated and stall torque values interchangeable?
No. Stall and peak values are not continuous ratings. The HT4510 operating-point table shows how torque, speed and current vary with operating duration.
Visual Details