CHIHAI CHP-12GP-N20 Hall Encoder Gear Motor and Two-Wheel Chassis Kit
CHIHAI CHP-12GP-N20 Hall Encoder Gear Motor and Two-Wheel Chassis Kit
CHIHAI MOTOR
تعذر تحميل مدى توفر الطلب


Overview
The CHIHAI CHP-12GP-N20 is a miniature planetary DC gear motor with an integrated two-channel Hall encoder. Choose one encoder motor for your own mechanism or a two-motor chassis kit with wheels, mounting brackets and a fibreglass base plate. The kit provides a mechanical drive platform for compact balancing-robot projects; control electronics must be added separately.
Features
- Compact plastic planetary reduction gearbox with a 120:1 ratio.
- 5V performance rating: 190rpm no-load and 145rpm at rated load.
- A/B incremental magnetic Hall feedback for speed and rotation sensing.
- 7PPR motor-side encoder, giving 840 pulses per gearbox output revolution before any controller-specific quadrature counting.
- ZH1.5-6PIN interface and connecting lead.
- Forward and reverse motor operation.
Specifications
| Motor model | CHP-12GP-N20; page model CHP-12GP-N20ABHL |
|---|---|
| Motor operating voltage | DC 3–5V; performance values below at 5V |
| Gear ratio | 120:1 |
| No-load speed / current | 190rpm / ≤120mA |
| Rated speed / torque / current | 145rpm / 0.65kg·cm / ≤0.26A |
| Stall torque / current | ≥1.5kg·cm / ≤1.5A; do not operate stalled |
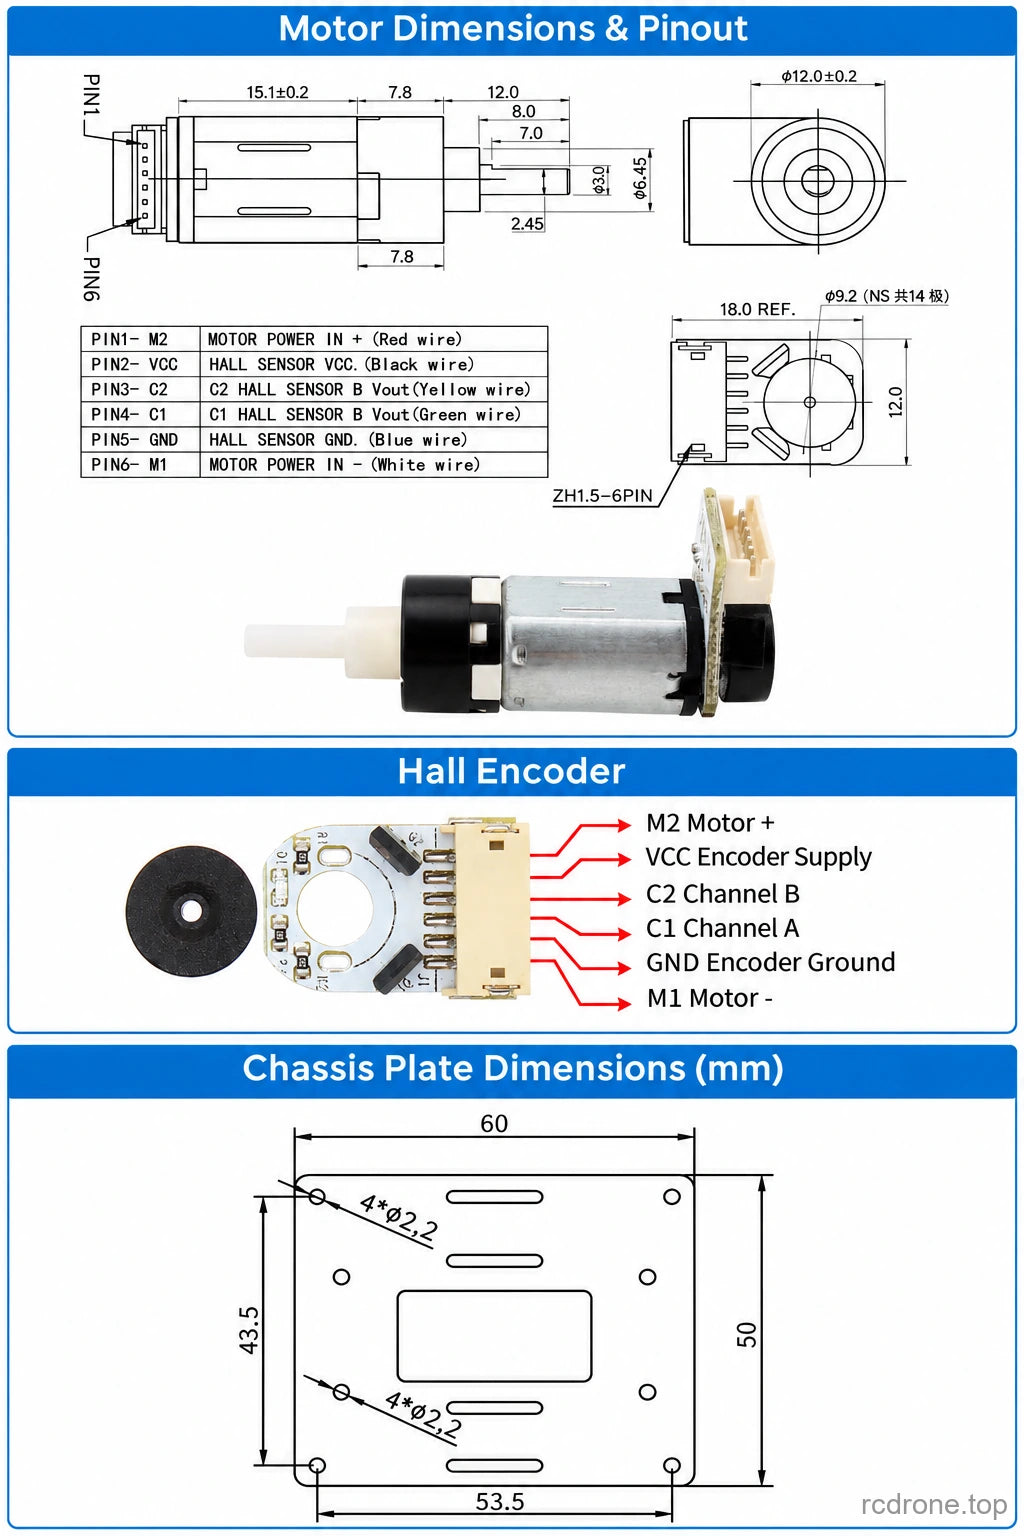
| Output shaft | D-shaped, nominal 8mm extension; see drawing for detailed geometry |
| Gearbox diameter | 12.0 ±0.2mm |
| Approximate motor mass | 12g |
| Encoder | Two-channel incremental magnetic Hall encoder; A/B square-wave output |
| Encoder supply | DC 3.3V or 5V |
| Encoder response frequency | 100kHz |
| Magnetic ring | 14 poles, 7 pole pairs |
| Output pulse relation | 7PPR × 120 = 840 pulses/output revolution; counting convention depends on controller |
| Encoder conditioning | On-board pull-up and signal-shaping resistors |
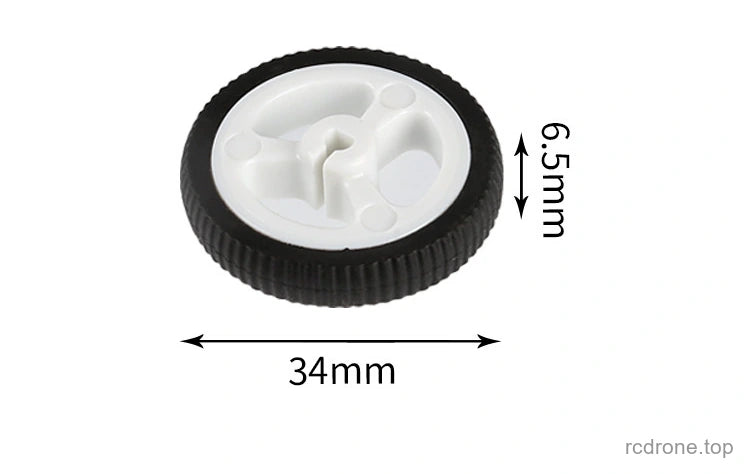
| Kit wheels | 34mm diameter × 6.5mm width |
| Chassis plate | 60 × 50mm; drawing shows 53.5 × 43.5mm hole spacing and 2.2mm holes |
| Assembled width | Approximately 105mm |
| Approximate complete mechanical kit mass | 36g |
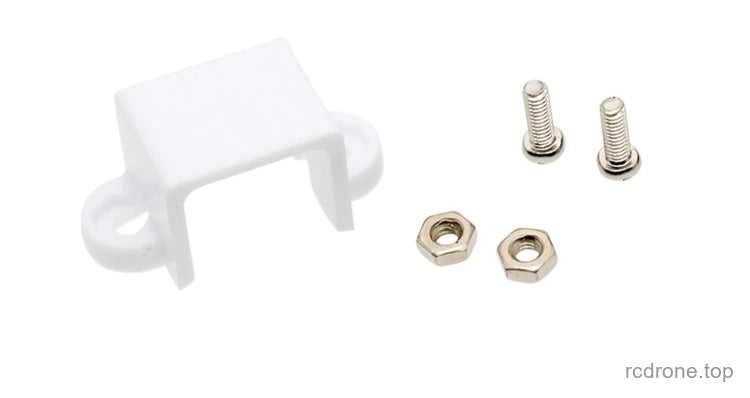
| Mounting bracket | 25mm overall length, 14.5mm outer width, 12mm inner width, 10mm inner height, 11.3mm overall height; fixing centres approximately 18.5mm |
Wiring and Installation
| Pin | Signal | Lead colour | Function |
|---|---|---|---|
| 1 | M2 | Red | Motor power + |
| 2 | VCC | Black | Hall encoder supply |
| 3 | C2 | Yellow | Encoder channel B |
| 4 | C1 | Green | Encoder channel A |
| 5 | GND | Blue | Hall encoder ground |
| 6 | M1 | White | Motor power − |
Motor power and encoder power use separate pins. Check connector orientation and pin numbering against the drawing before applying power; the black lead is encoder VCC, not ground. Match the encoder supply and signal levels to your controller. Use a suitable motor driver and avoid overload, prolonged stalls and excessive supply voltage.
Applications
Use the single motor for compact motion and feedback experiments, or the chassis kit as the mechanical base for a small two-wheel balancing robot. A controller, suitable sensing and motor drivers are required to implement balancing and closed-loop motion.
What's Included
- Encoder Motor - 1 pc: one encoder gear motor and connecting lead.
- Two-Motor Chassis Kit: two 5V 190rpm encoder motors, two mounting brackets, one fibreglass chassis plate, two 34mm wheels and matching installation fasteners.
Battery, motor driver, balancing controller and inertial sensor are not included. Assembled images illustrate the mechanical kit configuration.
FAQ
Will the chassis balance by itself?
No. The kit supplies the mechanical platform. Balancing requires your own controller, sensing, driver electronics and control software.
Is 190rpm the loaded speed?
No. It is the no-load output speed at 5V. The rated-load speed is 145rpm.
Does 840 mean quadrature counts?
It is the specified 7PPR motor-side pulse rate multiplied by the 120:1 reduction. The number reported by your controller depends on its edge-counting mode.
Visual Details