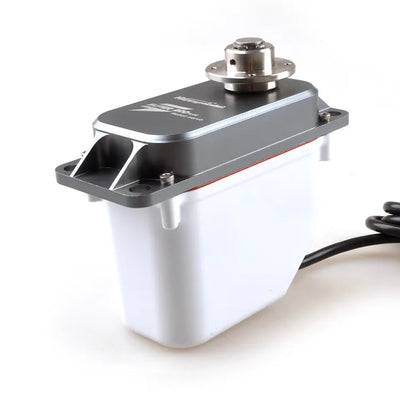
Kpower DM0090 PWM Servo Motor, 4.8–6.0 V, Metal Gears for Robotic Linkage Positioning
Kpower DM0090 PWM Servo Motor, 4.8–6.0 V, Metal Gears for Robotic Linkage Positioning
Kpower
السعر العادي
$35.00 USD
السعر العادي
سعر البيع
$35.00 USD
سعر الوحدة
لكل
الضرائب متضمنة.
شحن يتم احتساب المبلغ عند إتمام عملية الشراء.
تعذر تحميل مدى توفر الطلب


Overview
The Kpower DM0090 is a compact PWM servo motor for positioning small robotic linkages. It combines metal gears with a plastic case and operates from 4.8 to 6.0 V. Its specified travel is 120° ± 15°, with voltage-dependent speed and stall torque. The 22.4 × 12.5 × 22.8 mm body helps buyers assess installation space for their mechanism.
Features
- Metal gears and a plastic case.
- PWM control with a 900–2100 μs pulse-width range and 5 μs dead band.
- 120° ± 15° travel for limited-angle positioning.
- 4.8–6.0 V operation, with separate performance specifications at each endpoint.
Specifications
| Parameter | Value |
|---|---|
| Model | DM0090 |
| Gear material | Metal |
| Communication protocol | PWM |
| Case material | Plastic |
| Motor type | Core |
| Operating temperature | −10 °C to +50 °C |
| Dead band | 5 μs |
| Travel angle | 120° ± 15° |
| Pulse-width range | 900–2100 μs |
| Operating voltage range | 4.8–6.0 V |
| Dimensions | 22.4 × 12.5 × 22.8 mm |
| Weight | 14 g ± 1 g |
| Wire gauge and insulation | 30 AWG PVC |
| No-load speed | At 4.8 V: 0.09 ± 0.01 s/60° At 6.0 V: 0.08 ± 0.01 s/60° |
| Stall torque | At 4.8 V: 2.0 ± 0.20 kg·cm At 6.0 V: 2.5 ± 0.20 kg·cm |
| No-load current | At 4.8 V: 300 ± 30 mA At 6.0 V: 350 ± 30 mA |
| Stall current | At 4.8 V: 700 ± 40 mA At 6.0 V: 800 ± 40 mA |
Applications
Use the DM0090 to position a small robotic-arm linkage or move a compact robot mechanism through a limited angle. PWM control provides the positioning interface, while the compact body supports installations with restricted space. Account for the 120° ± 15° travel and the voltage-specific speed and stall-torque values when designing the mechanism.
Documents
- Kpower DM0090 Drawing — Drawing (PDF)
- Kpower Servo 3 — Manual (PDF)
- OCServo OCS D9501 Manuel — Ocservo Ocs D 9501 Manuel (PDF)
- OCServo OCS 351CAN Drawing — Ocservo Ocs 351 Can Drawing (PDF)
Visual Details
Features and Design


Interfaces and Connections


Application Examples


Additional Product Details