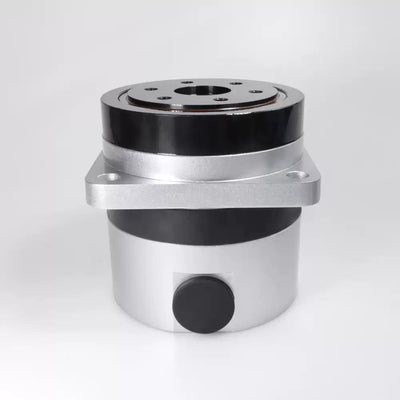
PG Series Harmonic Gear Reducer — Sizes 14, 20 and 32, 30:1–100:1
PG Series Harmonic Gear Reducer — Sizes 14, 20 and 32, 30:1–100:1
RCDrone
No se pudo cargar la disponibilidad de recogida


Overview
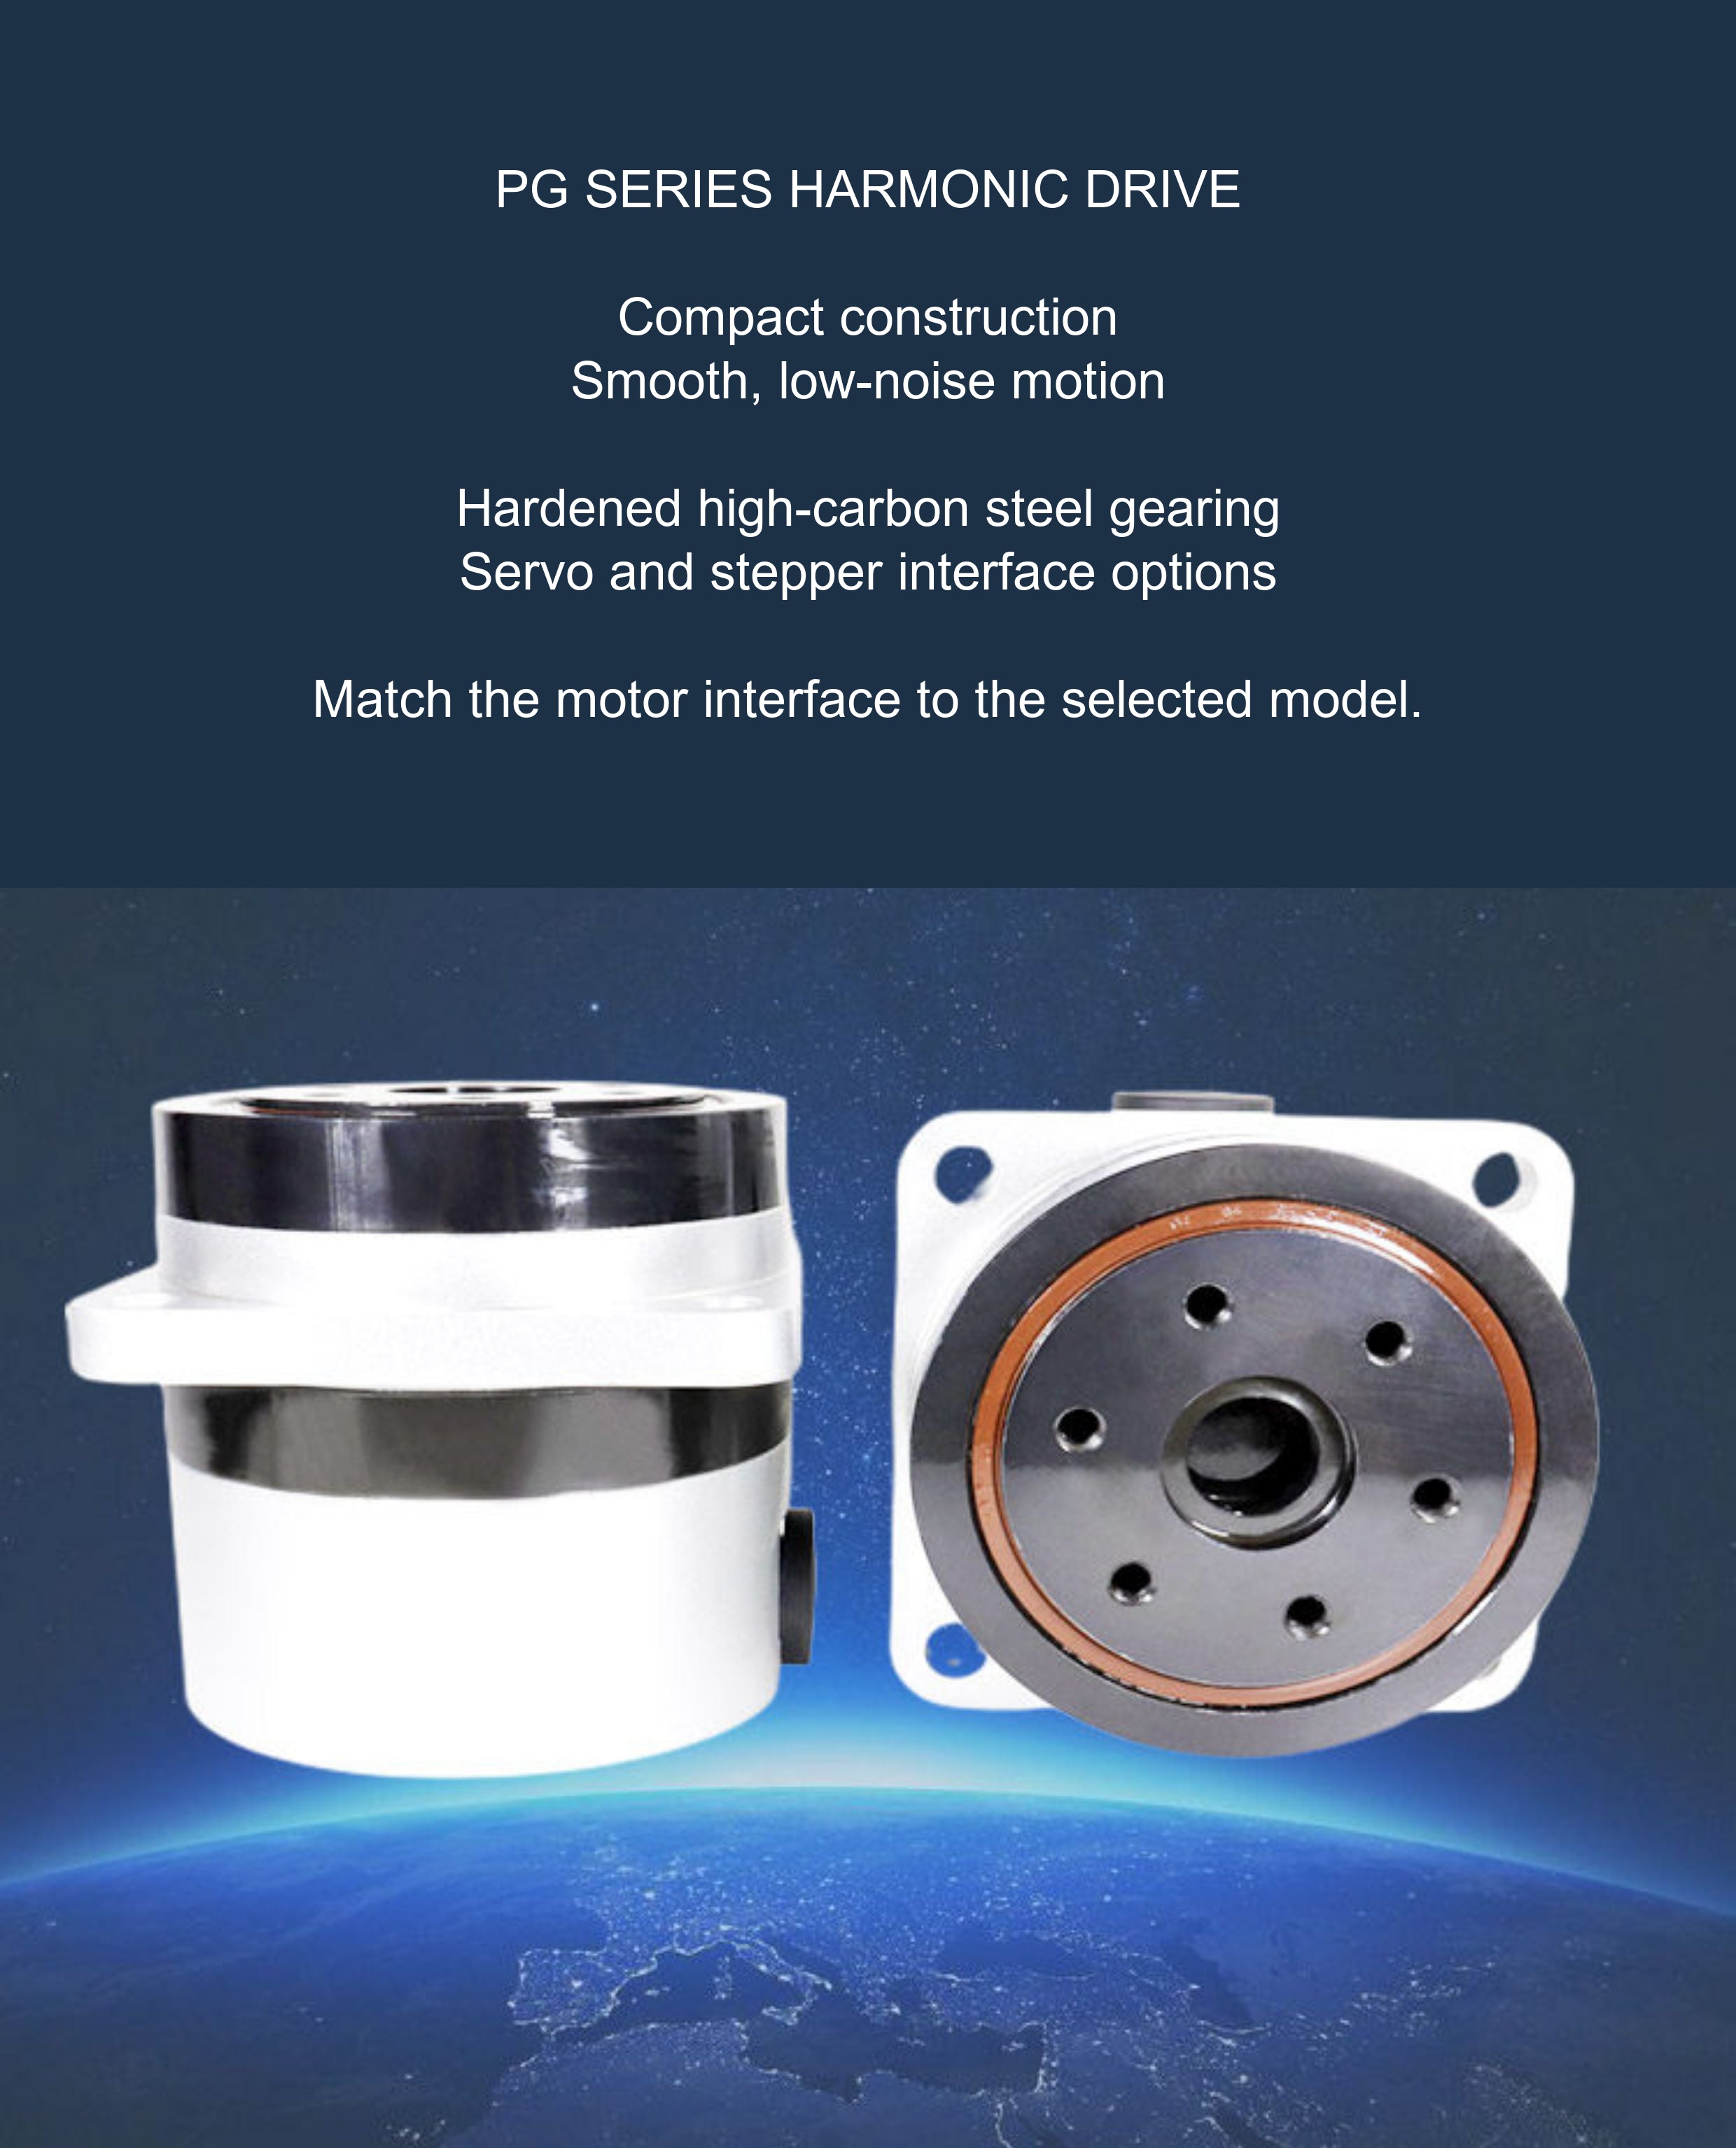
Build compact rotary mechanisms with a PG series harmonic gear reducer. Choose from size 14, 20 and 32 configurations, with reduction ratios of 30:1, 50:1, 80:1 or 100:1 depending on the model. Servo and stepper motor interface versions support different installation layouts.
Features
- Harmonic reduction for robotic joints, mechanical arms and precision automation.
- Compact construction with hardened high-carbon steel gearing, designed for smooth, low-noise motion.
- Model-specific motor interfaces: select the complete model and motor interface together.
Specifications
Configuration selection
The number after the model suffix identifies the reduction ratio: for example, PGA14-50 is a 50:1 version. The following groups describe the available selections; ratios are not interchangeable between every model and motor interface.
| Model group | Ratios offered | Motor interface |
|---|---|---|
| PGA14 | 50:1, 80:1, 100:1 | 40 mm servo |
| PGB14 | 50:1, 80:1, 100:1 | 42 mm stepper |
| PGA20 | 50:1, 80:1, 100:1 | 60 mm servo |
| PGB20 | 50:1, 80:1 | 57 mm stepper |
| PGB20-100 | 100:1 | 57 mm interface; verify motor type before selection |
| PG-32 | 50:1, 80:1, 100:1 | 60 mm servo |
| PGA32 | 30:1, 50:1, 80:1, 100:1 | 80 mm servo |
| PGB32 | 50:1, 80:1, 100:1 | 86 mm stepper |
| PGA14-30 / PGB14-30 | 30:1 | Verify the required motor interface before selection |
Reference dimensions
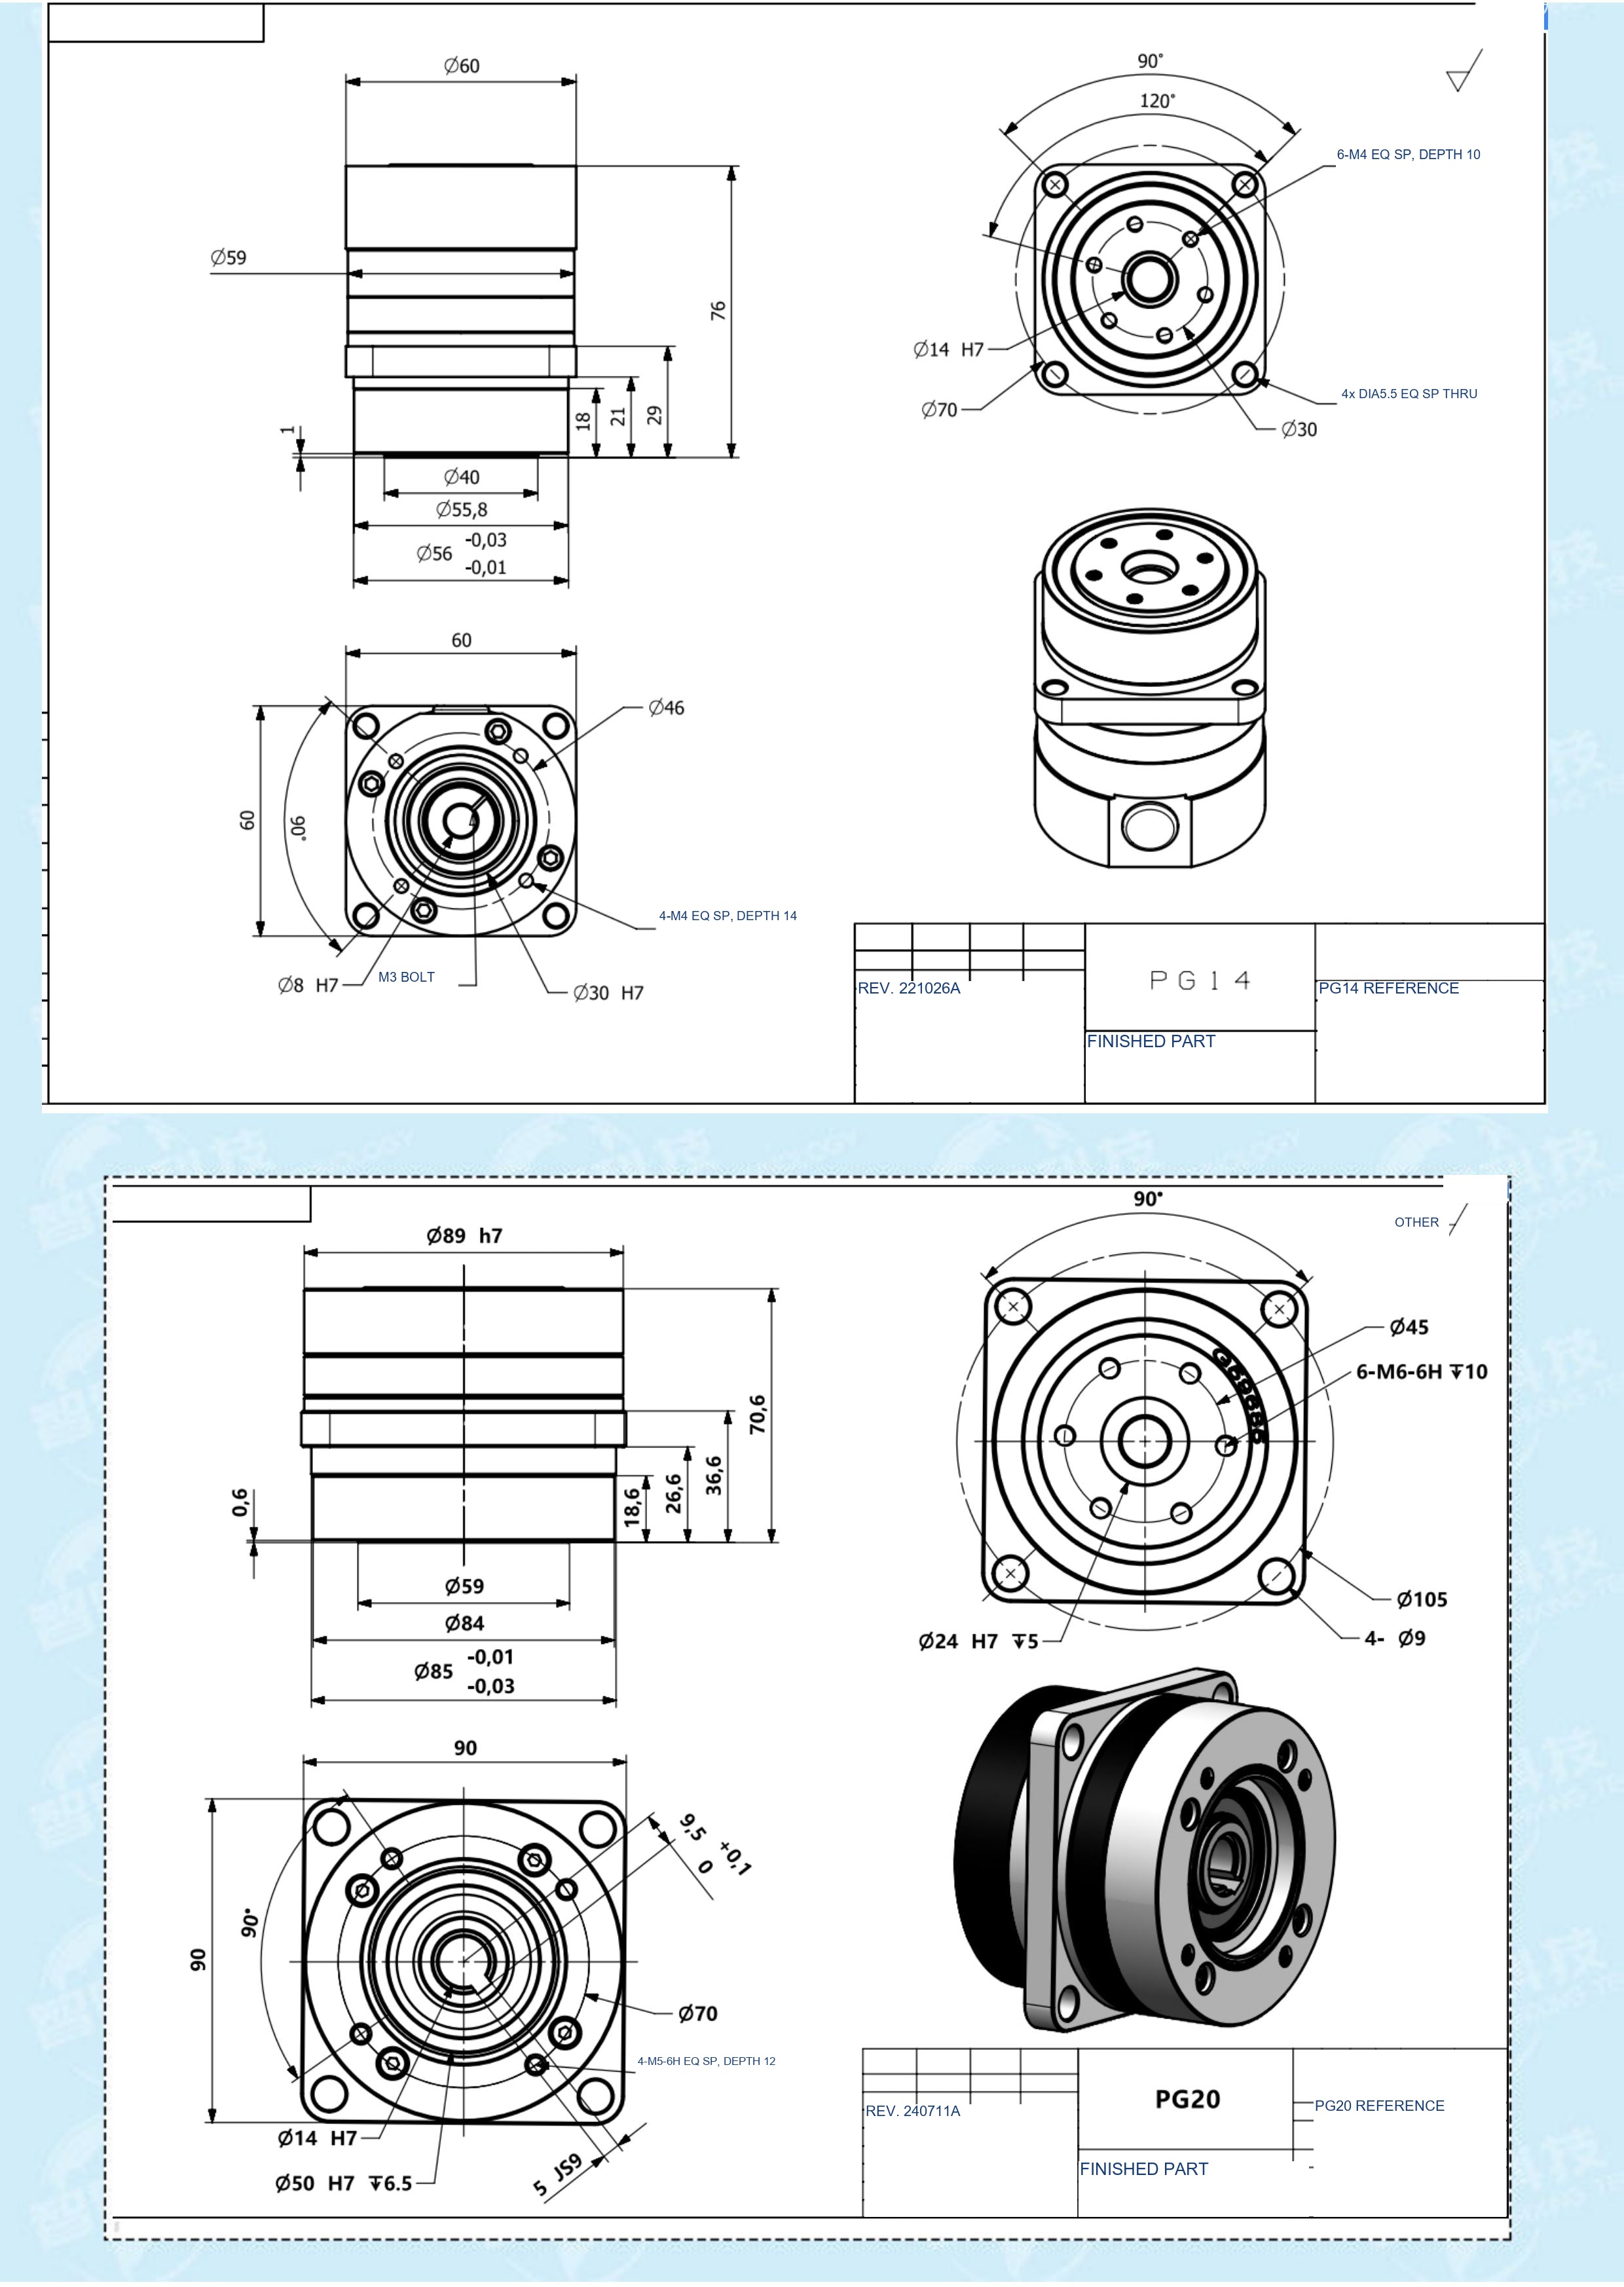
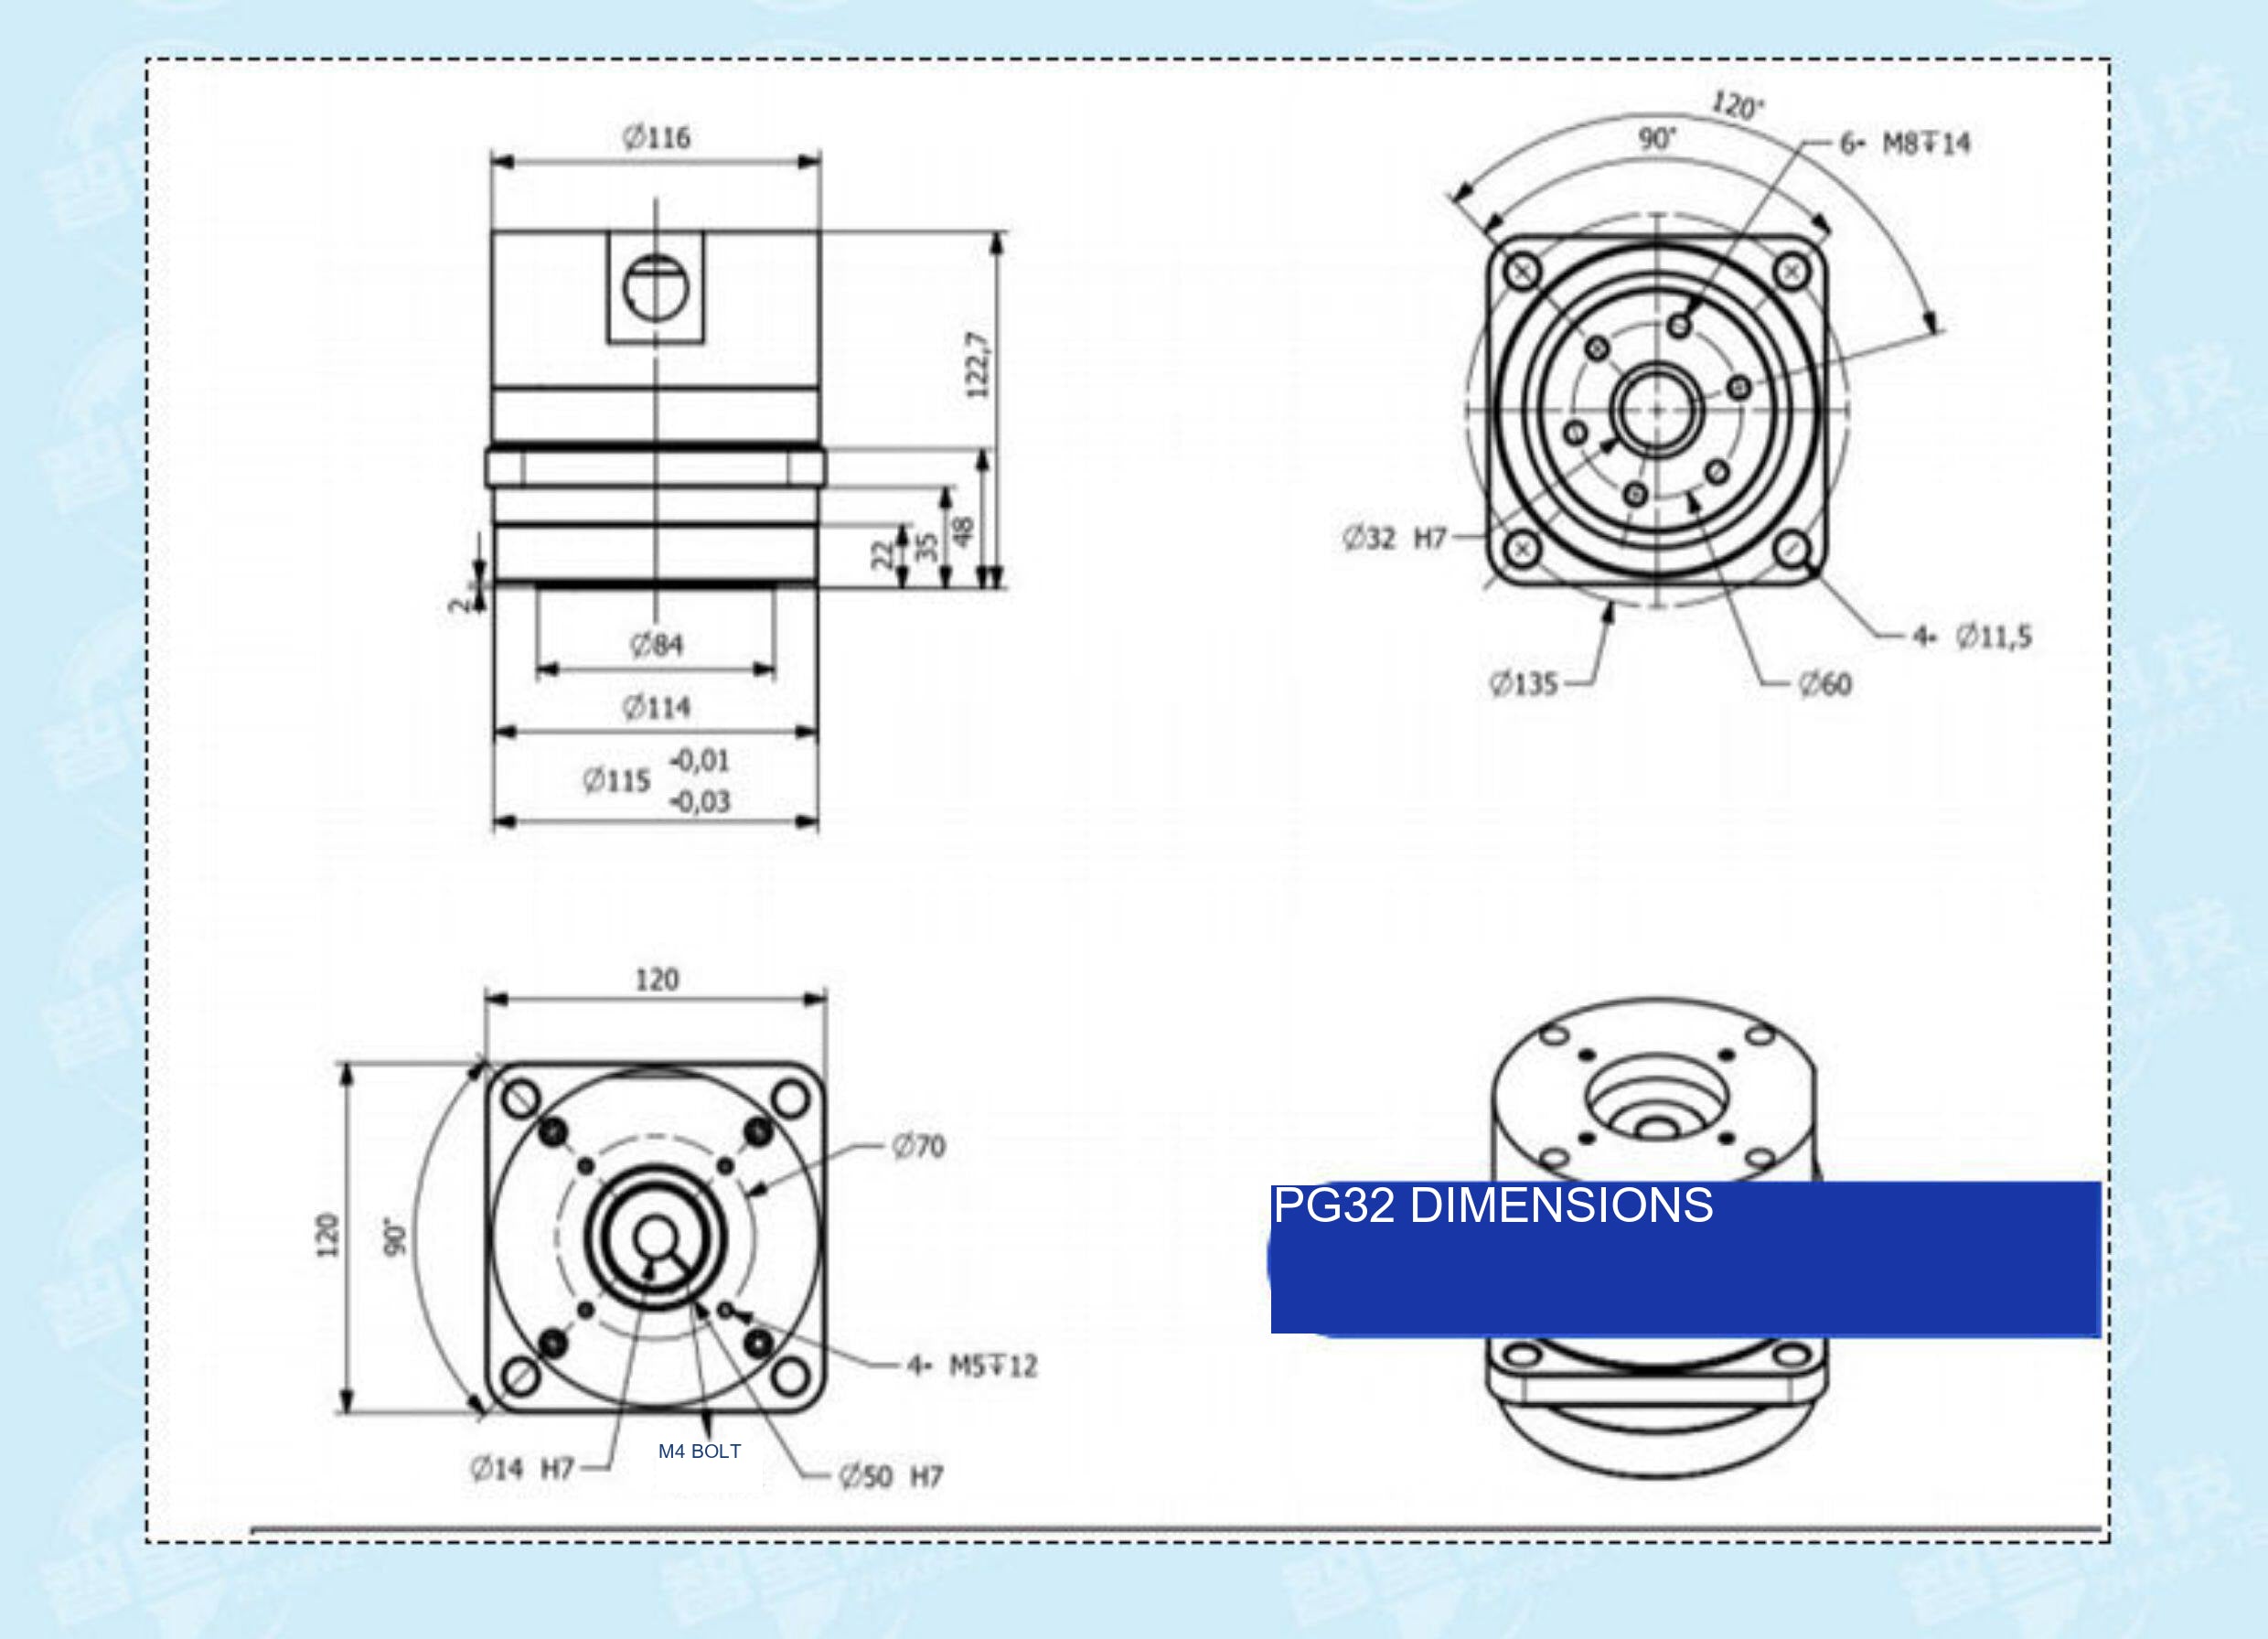
Use the drawings below as PG14, PG20 and PG32 series references. Check the selected motor interface, shaft fit, mounting pattern and installation envelope before machining mating parts. A motor-frame designation alone does not confirm every shaft or bolt-pattern dimension.
| Reference drawing | Square mounting face | Overall axial dimension | Shown input bore |
|---|---|---|---|
| PG14 | 60 × 60 mm | 76 mm | 8 mm H7 |
| PG20 | 90 × 90 mm | 70.6 mm | 14 mm H7 |
| PG32 | 120 × 120 mm | 122.7 mm | 14 mm H7 |
Drawing notes: EQ SP means equally spaced; THRU means through-hole. Dimensions and tolerances apply to the illustrated reference configuration, not automatically to every motor-interface option.
What's Included
PG-series gear reducer in the selected configuration. Motor-interface labels identify the intended mating format; they do not describe a motor bundle.
Applications
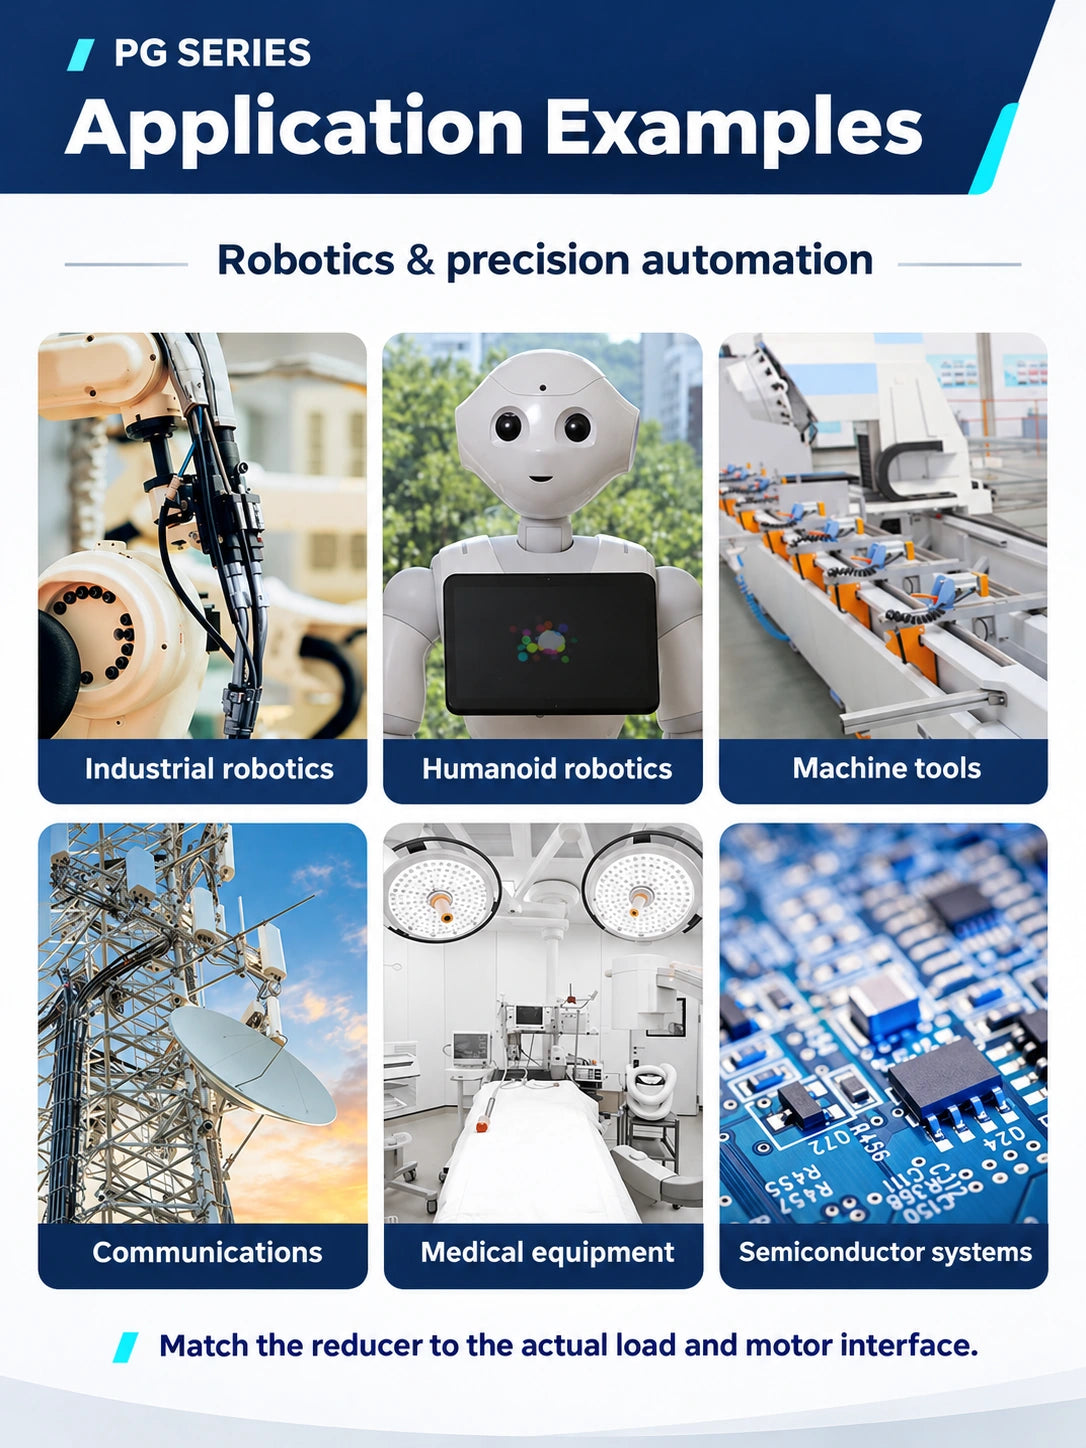
Typical design contexts include industrial and humanoid robotics, packaging machinery, machine tools, measurement equipment, communications mechanisms and semiconductor equipment. Match load, speed, mounting and environmental requirements to the chosen configuration.
FAQ
Is a motor included?
This listing is for the selected PG-series gear reducer. Motor-interface names describe the mating format, not an included motor bundle.
How do I choose the model and reduction ratio?
Select the complete model and motor-interface option. The suffix identifies the reduction ratio: PGA14-50, for example, is a 50:1 configuration. Available ratios depend on the model; not every ratio is offered with every interface.
Will a matching motor-frame size guarantee compatibility?
No. Check the input shaft fit, mounting pattern and installation envelope as well as the stated motor interface. A frame-size label alone does not confirm compatibility.
Do the dimension drawings apply to every option?
The PG14, PG20 and PG32 drawings are series references. Verify the drawing against the selected configuration before machining or ordering mating parts.
Why do several options show the same product image?
The source assigns a shared series image to these configurations. Use the selected model and interface text to identify the configuration; the shared photo does not distinguish every variant.
Visual Details